
Overview

In the NAU7802 Food Scale Learn Guide, you can build a food scale using CircuitPython, a NAU7802 STEMMA board and a strain gauge. In this guide, you'll take that project and connect it to Microsoft Azure to log the weight measurements over time. Additionally, you'll setup a text alert when it looks like you need to refill the food container.

Tracking inventory usage over time is a great way to utilize IoT tools. It can help you see patterns and better plan for the future. In the context of pet food, it can also help you monitor your pet's diet.
Prerequisite Guides
- The Getting Started with Microsoft Azure and CircuitPython Learn Guide goes through everything you need to get up and running with Microsoft Azure and CircuitPython. You'll need to follow along with the steps in that guide to make sure that your Azure account is setup properly to use for CircuitPython Azure IoT Central projects.
- This guide is considered part two to the NAU7802 Food Scale Learn Guide. You'll need to follow along with that guide to assemble the electronics and 3D printed parts for the food scale.
The following buttons take you to guides on the major components for reference:


Page last edited March 08, 2024
Text editor powered by tinymce.
Build the Food Scale
The NAU7802 Food Scale guide has everything you need documented to build your own. Please follow along with that guide first before adding in the Azure IoT Central functionality.

Follow the Fritzing diagram found on the Circuit Diagram page to wire up the food scale. The Wiring page goes into detail on soldering steps.

The 3D Printing page details the 3D printed enclosure for the project. The Assembly page goes through how to mount all of the components properly.
The Calibration page shows you how to properly calibrate your NAU7802 and strain gauge to get accurate weight measurements.
Page last edited March 08, 2024
Text editor powered by tinymce.
Create an IoT Central Application
There are two Azure IoT options: IoT Hub and IoT Central. In this guide, you'll be using IoT Central, which is the simpler of the two options to get started with.

After logging into Microsoft Azure, in the Azure Portal homepage search for "IoT Central" and navigate to IoT Central Applications


On the Basics page, you'll enter details about your application. The Application URL is how you will access your application's homepage.


After creating the application, the deployment of the app will begin. Once it finishes, you'll see a message that deployment is complete. Then, click on Go To Resource.

This brings you to your application's overview page. Click on the link on the right-hand side of the screen to view your app.

Page last edited March 08, 2024
Text editor powered by tinymce.
Connect Your Device

After creating your application, you'll connect a device instance for your development board that you'll be connecting to Azure with CircuitPython. This process will create the keys you need to include in your settings.toml file.


This opens the new device screen. Name your device. The device ID will be identical to the name. Then click Create.


This opens the Device connection groups window that has all of your secret connection keys. You will need the ID scope, Device ID and Primary key for your settings.toml file.
Now you're ready to connect to Microsoft Azure with CircuitPython!
Page last edited March 08, 2024
Text editor powered by tinymce.
CircuitPython
CircuitPython is a derivative of MicroPython designed to simplify experimentation and education on low-cost microcontrollers. It makes it easier than ever to get prototyping by requiring no upfront desktop software downloads. Simply copy and edit files on the CIRCUITPY drive to iterate.
CircuitPython Quickstart
Follow this step-by-step to quickly get CircuitPython running on your board.

Click the link above to download the latest CircuitPython UF2 file.
Save it wherever is convenient for you.

Plug your board into your computer, using a known-good data-sync cable, directly, or via an adapter if needed.
Click the reset button once (highlighted in red above), and then click it again when you see the RGB status LED(s) (highlighted in green above) turn purple (approximately half a second later). Sometimes it helps to think of it as a "slow double-click" of the reset button.
If you do not see the LED turning purple, you will need to reinstall the UF2 bootloader. See the Factory Reset page in this guide for details.
On some very old versions of the UF2 bootloader, the status LED turns red instead of purple.
For this board, tap reset and wait for the LED to turn purple, and as soon as it turns purple, tap reset again. The second tap needs to happen while the LED is still purple.
Once successful, you will see the RGB status LED(s) turn green (highlighted in green above), and a disk drive ending in "...BOOT" should appear on your host computer. If you see red, try another port, or if you're using an adapter or hub, try without the hub, or different adapter or hub.
If double-clicking doesn't work the first time, try again. Sometimes it can take a few tries to get the rhythm right!
A lot of people end up using charge-only USB cables and it is very frustrating! Make sure you have a USB cable you know is good for data sync.
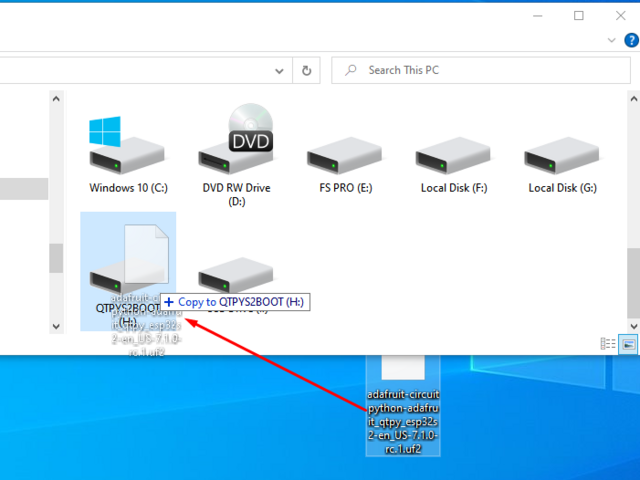
You will see a new disk drive appear called QTPYS2BOOT.
Drag the adafruit_circuitpython_etc.uf2 file to QTPYS2BOOT.
Copy or drag the UF2 file you downloaded to the BOOT drive.

Page last edited March 08, 2024
Text editor powered by tinymce.
Code the IoT Food Scale
Once you've finished setting up your QT Py ESP32-S2 with CircuitPython, you can access the code and necessary libraries by downloading the Project Bundle.
To do this, click on the Download Project Bundle button in the window below. It will download as a zipped folder.
# SPDX-FileCopyrightText: 2022 Liz Clark for Adafruit Industries
# SPDX-License-Identifier: MIT

from os import getenv
import time
import json
import board
from digitalio import DigitalInOut, Direction, Pull
from adafruit_ht16k33.segments import Seg14x4
from cedargrove_nau7802 import NAU7802
from calibration import calibration
import rtc
import socketpool
import wifi
import adafruit_ntp
from adafruit_azureiot import IoTCentralDevice

#  I2C setup with STEMMA port
i2c = board.STEMMA_I2C()
#  alphanumeric segment displpay setup
#  using two displays together
display = Seg14x4(i2c, address=(0x70, 0x71))
#  start-up text
display.print("*HELLO* ")
#  button LEDs
blue = DigitalInOut(board.A1)
blue.direction = Direction.OUTPUT
green = DigitalInOut(board.A3)
green.direction = Direction.OUTPUT
#  buttons setup
blue_btn = DigitalInOut(board.A0)
blue_btn.direction = Direction.INPUT
blue_btn.pull = Pull.UP
green_btn = DigitalInOut(board.A2)
green_btn.direction = Direction.INPUT
green_btn.pull = Pull.UP
# nau7802 setup
nau7802 = NAU7802(board.STEMMA_I2C(), address=0x2A, active_channels=2)
nau7802.gain = 128
enabled = nau7802.enable(True)

# Get WiFi details, ensure these are setup in settings.toml
ssid = getenv("CIRCUITPY_WIFI_SSID")
password = getenv("CIRCUITPY_WIFI_PASSWORD")

if None in [ssid, password]:
    raise RuntimeError(
        "WiFi settings are kept in settings.toml, "
        "please add them there. The settings file must contain "
        "'CIRCUITPY_WIFI_SSID', 'CIRCUITPY_WIFI_PASSWORD', "
        "at a minimum."
    )

print("Connecting to WiFi...")
wifi.radio.connect(ssid, password)

print("Connected to WiFi!")
#  check system time
if time.localtime().tm_year < 2022:
    print("Setting System Time in UTC")
    pool = socketpool.SocketPool(wifi.radio)
    ntp = adafruit_ntp.NTP(pool, tz_offset=-4)
    # NOTE: This changes the system time so make sure you aren't assuming that time
    # doesn't jump.
    rtc.RTC().datetime = ntp.datetime

else:
    print("Year seems good, skipping set time.")

# Create an IoT Central device client and connect
esp = None
pool = socketpool.SocketPool(wifi.radio)
device = IoTCentralDevice(
    pool, esp, getenv("id_scope"), getenv("device_id"), getenv("device_primary_key")
)
display.fill(0)
display.print("DIALING*")
print("Connecting to Azure IoT Central...")
device.connect()
display.print("CONNECTD")
print("Connected to Azure IoT Central!")
device.disconnect()
print("Disconnected")
#  zeroing function
def zero_channel():
    """Initiate internal calibration for current channel; return raw zero
    offset value. Use when scale is started, a new channel is green_btned, or to
    adjust for measurement drift. Remove weight and tare from load cell before
    executing."""
    blue.value = True
    print(
        "channel %1d calibrate.INTERNAL: %5s"
        % (nau7802.channel, nau7802.calibrate("INTERNAL"))
    )
    blue.value = False
    print(
        "channel %1d calibrate.OFFSET:   %5s"
        % (nau7802.channel, nau7802.calibrate("OFFSET"))
    )
    blue.value = True
    zero_offset = read_raw_value(100)  # Read 100 samples to establish zero offset
    print("...channel %1d zeroed" % nau7802.channel)
    blue.value = False
    return zero_offset
#  read raw value function
def read_raw_value(samples=100):
    """Read and average consecutive raw sample values. Return average raw value."""
    sample_sum = 0
    sample_count = samples
    while sample_count > 0:
        if nau7802.available:
            sample_sum = sample_sum + nau7802.read()
            sample_count -= 1
    return int(sample_sum / samples)
#  function for finding the average of an array
def find_average(num):
    count = 0
    for n in num:
        count = count + n
    average = count / len(num)
    return average
#  calibration function
def calculateCalibration(array):
    for _ in range(10):
        blue.value = True
        green.value = False
        nau7802.channel = 1
        print("channel %1.0f raw value: %7.0f" % (nau7802.channel, abs(read_raw_value())))
        array.append(abs(read_raw_value()))
        blue.value = False
        green.value = True
        time.sleep(1)
    green.value = False
    avg = find_average(array)
    return avg
#  blink LED function
def blink(led, amount, count):
    for _ in range(count):
        led.value = True
        time.sleep(amount)
        led.value = False
        time.sleep(amount)
#  send data to azure with ounces and grams
def send_to_azure(current_oz, current_grams):
    #  turn on green LED
    green.value = True
    display.print("DIALING*")
    #  connect to azure
    device.reconnect()
    #  turn on blue LED
    blue.value = True
    display.print("CONNECTD")
    time.sleep(1)
    display.print("SENDING!")
    #  send JSON of ounces and grams
    message = {"Ounces": current_oz, "Grams": current_grams}
    device.send_telemetry(json.dumps(message))
    display.fill(0)
    display.print("SENT!")
    #  disconnect and turn off LEDs
    device.disconnect()
    green.value = False
    blue.value = False
#  zeroing on startup
display.fill(0)
display.marquee("CLEAR SCALE CLEAR", 0.3, False)
time.sleep(2)
display.fill(0)
display.print("ZEROING")
time.sleep(3)
#  zeroing each channel
nau7802.channel = 1
zero_channel()  # Calibrate and zero channel
display.fill(0)
display.print("STARTING")

#  variables and states
clock = time.monotonic() #  time.monotonic() device
reset_clock = time.monotonic()
long_clock = time.monotonic()
mode = "run"
mode_names = ["SHOW OZ?", "   GRAMS?", "   ZERO?", "CALIBRTE", " OFFSET?", "TO AZURE"]
stage = 0
zero_stage = 0
weight_avg = 0
zero_avg = 0
show_oz = True
show_grams = False
zero_out = False
calibrate_mode = False
blue_btn_pressed = False
green_btn_pressed = False
run_mode = True
avg_read = []
avg_grams = []
avg_oz = []
values = []
val_offset = 0
avg_values = []
the_ounces = 0
the_grams = 0

#  initial reading from the scale
for w in range(5):
    nau7802.channel = 1
    value = read_raw_value()
    #  takes value reading and divides with by the offset value
    #  to get the weight in grams
    grams = value / calibration['offset_val']
    avg_read.append(grams)
    if len(avg_read) > 4:
        the_avg = find_average(avg_read)
        oz = the_avg / 28.35
        display.print("   %0.1f oz" % oz)
        avg_read.clear()
    time.sleep(1)

while True:
    #  button debouncing
    if blue_btn.value and blue_btn_pressed:
        blue_btn_pressed = False
    if green_btn.value and green_btn_pressed:
        green_btn_pressed = False
        green.value = False
    #  default run mode
    #  checks NAU7802 every 2 seconds
    if run_mode is True and (time.monotonic() - clock) > 2:
        nau7802.channel = 1
        value = read_raw_value()
        value = abs(value) - val_offset
        values.append(value)
        #  takes value reading and divides with by the offset value
        #  to get the weight in grams
        grams = value / calibration['offset_val']
        oz = grams / 28.35
        avg_grams.append(grams)
        avg_oz.append(oz)
        if show_oz is True:
            #  append reading
            avg_read.append(oz)
            label = "oz"
        if show_grams is True:
            avg_read.append(grams)
            label = "g"
        if len(avg_read) > 10:
            the_avg = find_average(avg_read)
            the_grams = find_average(avg_grams)
            the_ounces = find_average(avg_oz)
            display.print("   %0.1f %s" % (the_avg, label))
            avg_read.clear()
            avg_grams.clear()
            avg_oz.clear()
            val_offset += 10
        clock = time.monotonic()
    if (time.monotonic() - reset_clock) > 43200:
        run_mode = False
        show_oz = False
        show_grams = False
        zero_out = True
        reset_clock = time.monotonic()
    #  if you press the change mode button
    if (not green_btn.value and not green_btn_pressed) and run_mode:
        green.value = True
        #  disables run mode (stops weighing)
        run_mode = False
        show_oz = False
        show_grams = False
        #  mode is set to 0
        mode = 0
        #  display shows the mode option
        display.print(mode_names[mode])
        blue.value = True
        green_btn_pressed = True
    #  advances through the modes menu
    if (not green_btn.value and not green_btn_pressed) and mode != "run":
        green.value = True
        #  counts up to 4 and loops back to 0
        mode = (mode+1) % 6
        #  updates display
        display.print(mode_names[mode])
        green_btn_pressed = True
    #  if you select show_oz
    if (not blue_btn.value and not blue_btn_pressed) and mode == 0:
        #  show_oz is set as the state
        show_oz = True
        label = "oz"
        blue.value = False
        #  goes back to weighing mode
        mode = "run"
        blue_btn_pressed = True
        display.print("   %0.1f %s" % (the_avg, label))
        run_mode = True
    #  if you select show_grams
    if (not blue_btn.value and not blue_btn_pressed) and mode == 1:
        #  show_grams is set as the state
        show_grams = True
        label = "g"
        blue.value = False
        #  goes back to weighing mode
        mode = "run"
        blue_btn_pressed = True
        display.print("   %0.1f %s" % (the_avg, label))
        run_mode = True
    #  if you select zero_out
    if (not blue_btn.value and not blue_btn_pressed) and mode == 2:
        #  zero_out is set as the state
        #  can zero out the scale without full recalibration
        zero_out = True
        blue.value = False
        mode = "run"
        blue_btn_pressed = True
    #  if you select calibrate_mode
    if (not blue_btn.value and not blue_btn_pressed) and mode == 3:
        #  calibrate_mode is set as the state
        #  starts up the calibration process
        calibrate_mode = True
        blue.value = False
        mode = "run"
        blue_btn_pressed = True
    #  if you select the offset
    if (not blue_btn.value and not blue_btn_pressed) and mode == 4:
        #  displays the curren offset value stored in the code
        blue.value = False
        display.fill(0)
        display.print("%0.4f" % calibration['offset_val'])
        time.sleep(5)
        mode = "run"
        #  goes back to weighing mode
        show_oz = True
        label = "oz"
        display.print("   %0.1f %s" % (the_avg, label))
        run_mode = True
        blue_btn_pressed = True
    if (not blue_btn.value and not blue_btn_pressed) and mode == 5:
        blue.value = False
        display.fill(0)
        #  sends data to azure
        send_to_azure(the_ounces, the_grams)
        time.sleep(1)
        mode = "run"
        #  goes back to weighing mode
        show_oz = True
        label = "oz"
        display.print("   %0.1f %s" % (the_avg, label))
        run_mode = True
        blue_btn_pressed = True
    #  if the zero_out state is true
    if zero_out and zero_stage == 0:
        blue_btn_pressed = True
        #  clear the scale for zeroing
        display.fill(0)
        display.print("REMOVE ")
        zero_stage = 1
        blue.value = True
        green.value = True
    if (not blue_btn.value and not blue_btn_pressed) and zero_stage == 1:
        green.value = False
        #  updates display
        display.fill(0)
        display.print("ZEROING")
        blue.value = False
        #  runs zero_channel() function on both channels
        nau7802.channel = 1
        zero_channel()
        display.fill(0)
        display.print("ZEROED ")
        zero_out = False
        zero_stage = 0
        #  goes into weighing mode
        val_offset = 0
        run_mode = True
        show_oz = True
        label = "oz"
        display.print("   %0.1f %s" % (the_avg, label))
    #  the calibration process
    #  each step is counted in stage
    #  blue button is pressed to advance to the next stage
    if calibrate_mode is True and stage == 0:
        blue_btn_pressed = True
        #  clear the scale for zeroing
        display.fill(0)
        display.print("REMOVE ")
        stage = 1
        blue.value = True
    #  stage 2
    if (not blue_btn.value and not blue_btn_pressed) and stage == 1:
        blue_btn_pressed = True
        #  runs the zero out function
        display.fill(0)
        display.print("ZEROING")
        blue.value = False
        nau7802.channel = 1
        zero_channel()
        display.fill(0)
        display.print("ZEROED ")
        stage = 2
        blue.value = True
    #  stage 3
    if (not blue_btn.value and not blue_btn_pressed) and stage == 2:
        blue_btn_pressed = True
        blue.value = False
        display.print("STARTING")
        blink(blue, 0.5, 3)
        zero_readings = []
        display.print("AVG ZERO")
        #  runs the calculateCallibration function
        #  takes 10 raw readings, stores them into an array and gets an average
        zero_avg = calculateCalibration(zero_readings)
        stage = 3
        display.fill(0)
        display.print("DONE")
        blue.value = True
    #  stage 4
    if (not blue_btn.value and not blue_btn_pressed) and stage == 3:
        #  place the known weight item
        #  item's weight matches calibration['weight'] in grams
        blue_btn_pressed = True
        blue.value = False
        display.fill(0)
        display.print("PUT ITEM")
        stage = 4
        blue.value = True
    #  stage 5
    if (not blue_btn.value and not blue_btn_pressed) and stage == 4:
        blue_btn_pressed = True
        blue.value = False
        display.fill(0)
        display.print("WEIGHING")
        weight_readings = []
        #  weighs the item 10 times, stores the readings in an array & averages them
        weight_avg = calculateCalibration(weight_readings)
        #  calculates the new offset value
        calibration['offset_val'] = (weight_avg-zero_avg) / calibration['weight']
        display.marquee("%0.2f - CALIBRATED " % calibration['offset_val'], 0.3, False)
        stage = 5
        display.fill(0)
        display.print("DONE")
        blue.value = True
    #  final stage
    if (not blue_btn.value and not blue_btn_pressed) and stage == 5:
        blue_btn_pressed = True
        zero_readings.clear()
        weight_readings.clear()
        calibrate_mode = False
        blue.value = False
        #  goes back into weighing mode
        show_oz = True
        label = "oz"
        display.print("   %0.1f %s" % (the_avg, label))
        val_offset = 0
        run_mode = True
        #  resets stage
        stage = 0
Upload the Code and Libraries to the QT Py ESP32-S2
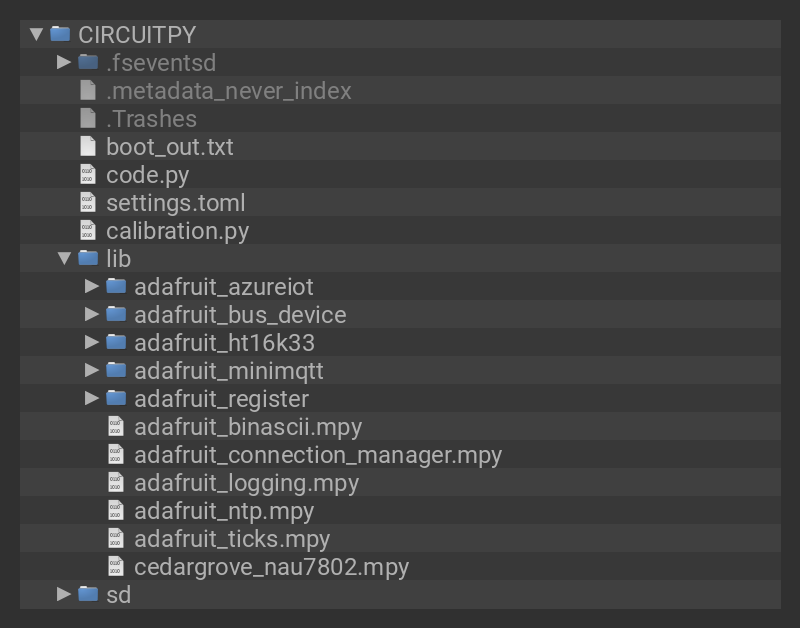
After downloading the Project Bundle, plug your QT Py ESP32-S2 into the computer's USB port with a known good USB data+power cable. You should see a new flash drive appear in the computer's File Explorer or Finder (depending on your operating system) called CIRCUITPY. Unzip the folder and copy the following items to the QT Py ESP32-S2's CIRCUITPY drive.
- lib folder
- calibration.py
- code.py
Your QT Py ESP32-S2 CIRCUITPY drive should look like this after copying the lib folder, calibration.py file and the code.py file.
Install the cedargrove_nau7802 CircuitPython Library
Follow along with the steps outlined in this guide to download the cedargrove_nau7802 CircuitPython library and upload it to your QT Py ESP32-S2 CIRCUITPY drive lib folder. The library is a part of the CircuitPython Community Bundle.
calibration.py File
The calibration.py file holds two important values for the main code.py file: offset_val and weight. weight is the known weight in grams that you use to calibrate the NAU7802. The offset_val is the calibration number used to divide against the raw value from the NAU7802 to find the actual weight on top of the scale.
Each strain gauge is slightly different, so you'll want to edit the calibration.py file with your known weight item and the offset_val you generate after running the calibration mode in the code.py file.
settings.toml
You will need to create and add a settings.toml file to your CIRCUITPY drive. Your settings.toml file will need to include the following information:
# This file is where you keep secret settings, passwords, and tokens!
# If you put them in the code you risk committing that info or sharing it

CIRCUITPY_WIFI_SSID="your-wifi-ssid"
CIRCUITPY_WIFI_PASSWORD="your-wifi-password"
id_scope="YOUR-AZURE-ID-SCOPE-HERE"
device_id="YOUR-AZURE-DEVICE-ID-HERE"
device_primary_key="YOUR-AZURE-DEVICE-PRIMARY-KEY-HERE"
You'll gather your ID scope, device ID and device primary key from your device connection groups page in your Azure application. Make sure to refer to the Connect Your Device page in this guide to see the process for accessing the keys.
How the CircuitPython Code Works
The CircuitPython code is identical to the original NAU7802 Food Scale CircuitPython code as far as scale functionality. This version of the code adds functionality for connecting to, and sending data to, Azure.
The code begins by connecting to WiFi and grabbing the date and time using the adafruit_ntp library.
# Get WiFi details, ensure these are setup in settings.toml
ssid = getenv("CIRCUITPY_WIFI_SSID")
password = getenv("CIRCUITPY_WIFI_PASSWORD")

if None in [ssid, password]:
    raise RuntimeError(
        "WiFi settings are kept in settings.toml, "
        "please add them there. The settings file must contain "
        "'CIRCUITPY_WIFI_SSID', 'CIRCUITPY_WIFI_PASSWORD', "
        "at a minimum."
    )

print("Connecting to WiFi...")
wifi.radio.connect(ssid, password)

print("Connected to WiFi!")
#  check system time
if time.localtime().tm_year < 2022:
    print("Setting System Time in UTC")
    pool = socketpool.SocketPool(wifi.radio)
    ntp = adafruit_ntp.NTP(pool, tz_offset=-4)
    # NOTE: This changes the system time so make sure you aren't assuming that time
    # doesn't jump.
    rtc.RTC().datetime = ntp.datetime

else:
    print("Year seems good, skipping set time.")
Then, a connection is established with Microsoft Azure. The alphanumeric display updates its text to show what is going on with the connection process.
# Create an IoT Central device client and connect
esp = None
pool = socketpool.SocketPool(wifi.radio)
device = IoTCentralDevice(
    pool, esp, getenv("id_scope"), getenv("device_id"), getenv("device_primary_key")
)
display.fill(0)
display.print("DIALING*")
print("Connecting to Azure IoT Central...")
device.connect()
display.print("CONNECTD")
print("Connected to Azure IoT Central!")
The send_to_azure() function sends the current weight in ounces and grams to Azure with device.send_telemetry(json.dumps(message)). It also uses the buttons' LEDs and alphanumeric display to indicate the processes in the code.
#  send data to azure with ounces and grams
def send_to_azure(current_oz, current_grams):
    #  turn on green LED
    green.value = True
    display.print("DIALING*")
    #  connect to azure
    device.reconnect()
    #  turn on blue LED
    blue.value = True
    display.print("CONNECTD")
    time.sleep(1)
    display.print("SENDING!")
    #  send JSON of ounces and grams
    message = {"Ounces": current_oz, "Grams": current_grams}
    device.send_telemetry(json.dumps(message))
    display.fill(0)
    display.print("SENT!")
    #  disconnect and turn off LEDs
    device.disconnect()
    green.value = False
    blue.value = False
Logging Ounces and Grams
The alphanumeric display shows either ounces or grams depending on the mode selected. In the background though, both the ounces and grams are logged in the_grams and the_ounces.
grams = value / calibration['offset_val']
        oz = grams / 28.35
        avg_grams.append(grams)
        avg_oz.append(oz)
        if show_oz is True:
            #  append reading
            avg_read.append(oz)
            label = "oz"
        if show_grams is True:
            avg_read.append(grams)
            label = "g"
        if len(avg_read) > 10:
            the_avg = find_average(avg_read)
            the_grams = find_average(avg_grams)
            the_ounces = find_average(avg_oz)
            display.print("   %0.1f %s" % (the_avg, label))
            avg_read.clear()
            avg_grams.clear()
            avg_oz.clear()
Send Weight to Azure
The food scale is coded to have a selection of mode functionality. One of the functions in the list is sending the data to Azure. If mode is 5 and the blue button is pressed, then send_to_azure(the_ounces, the_grams) is called and sends the current weigh in ounces and grams is sent to your Azure IoT Central application. Then, the scale goes back to weighing mode.
if (not blue_btn.value and not blue_btn_pressed) and mode == 5:
        blue.value = False
        display.fill(0)
        #  sends data to azure
        send_to_azure(the_ounces, the_grams)
        time.sleep(1)
        mode = "run"
        #  goes back to weighing mode
        show_oz = True
        label = "oz"
        display.print("   %0.1f %s" % (the_avg, label))
        run_mode = True
        blue_btn_pressed = True
Page last edited March 08, 2024
Text editor powered by tinymce.
Edit the Data Template
The device's template organizes and categorizes the incoming data so that it can be logged properly.


If you've already logged data from the QT Py ESP32-S2, then the template will be auto-filled with the data that you sent to Microsoft Azure which was previously categorized as unmodeled data.

You can also add the data types that you want to collect by clicking Add capability. The display name is how the data will be categorized on Azure. The name has to match the string in the JSON message that is sent from the CircuitPython code. Capability type needs to match the type of data that is going to be received. If you are receiving sensor data, then you will select Telemetry.
Make sure to click Save when you're done editing your template.
Page last edited March 08, 2024
Text editor powered by tinymce.
Create a Dashboard

You can create visual dashboards to display your data for easy viewing.


In edit mode, a tile menu opens on the left. You can drag and drop different tiles into the main dashboard space. There's a variety of graph and display types to choose from.

The tile will be empty when you first bring it to the dashboard. You can click on the pencil icon to edit the tile to display your data.


To bring the data into the tile, you'll select your device from the dropdown. Then, add Capability to bring in different data streams.

You can add as many tiles as you want to fully customize your dashboard. The food scale dashboard utilizes line graph and last known value (LKV) tiles to show the weight over time, the current weight and the change in weight since the last reading.

Page last edited March 08, 2024
Text editor powered by tinymce.
Create a Text Alert

You can create Rules to alert you about certain data thresholds. For this project, you'll setup a text alert using an action group in the Azure Portal.


Under Notifications, you'll choose the notification type and name the notification. Choose Email/SMS message/Push/Voice for text message.

A menu for directing the notification will pop-up on the right of the screen. Check off SMS for a text message and enter the phone number that you want to receive the text messages.
Afterwards, you can click "Review and create" to complete the setup.


First, you'll need to name the alert and toggle the Enable option to turn it on. Then you can select the device to receive alerts for.

You'll setup conditions for the rule. You can have the rule be triggered if all or some of the conditions are true. The Time aggregation option can limit the number of alerts you receive. For example, if you select 60 minutes then you will only be alerted once per hour if a condition is true.
Under Telemetry, you'll select the data feed to monitor, as well as an operator; such as less than, equal to, etc. Under Value, you'll enter the value to watch for.


Page last edited March 08, 2024
Text editor powered by tinymce.
Usage
After calibrating your NAU7802, place your food container on top and begin tracking your pet's food consumption over time.

View the data over time to estimate when you need to refill the container. You can also see on average how much is being eaten per meal with the last known value chart.

Page last edited March 08, 2024
Text editor powered by tinymce.


