

Code the POV Wheel
You can access the code and necessary libraries by downloading the Project Bundle.
Click the Download Project Bundle button in the code window below. This will download a zipped folder containing the CircuitPython code, libraries, and sample images for the project.
# SPDX-FileCopyrightText: 2026 Erin St Blaine for Adafruit Industries
#
# SPDX-License-Identifier: MIT

"""Three-spoke CircuitPython bike wheel persistence-of-vision display."""

import gc
import os
import time
from array import array

import adafruit_imageload
import adafruit_pioasm
import adafruit_tmag5273
import board
import rp2pio


# ---------------------------------------------------------------------------
# DISPLAY SETTINGS
# ---------------------------------------------------------------------------

NUM_LEDS = 36
IMAGE_FOLDER = "/img"
IMAGE_SECONDS = 8.0

# Approximate angular resolution of the wheel display.
#
# Examples:
#   36 px wide  -> 4 repeats per revolution
#   72 px wide  -> 2 repeats per revolution
#   144 px wide -> 1 repeat per revolution
SCANLINES_PER_REVOLUTION = 144

# Keep playback fast enough for clean POV at lower wheel speeds.
MIN_SCANLINES_PER_SECOND = 400.0

# 1.0 corrects the measured phase error over roughly one revolution.
STABILIZATION_STRENGTH = 1.0

# Rotate the entire pattern relative to the Hall sensor magnet.
PATTERN_ROTATION_DEGREES = 30.0

# DotStar global brightness: 0-31.
DOTSTAR_BRIGHTNESS = 10

PIO_FREQUENCY = 8_000_000


# ---------------------------------------------------------------------------
# HALL SENSOR SETTINGS
# ---------------------------------------------------------------------------

MAG_TRIGGER = 800.0
MAG_RELEASE = 450.0

MAG_TRIGGER_SQ = MAG_TRIGGER * MAG_TRIGGER
MAG_RELEASE_SQ = MAG_RELEASE * MAG_RELEASE

MIN_REVOLUTION_MS = 120

HALL_CLEAR_MS = 50
HALL_CLEAR_NS = HALL_CLEAR_MS * 1_000_000

START_CONFIRM_SECONDS = 1.5
START_CONFIRM_NS = int(START_CONFIRM_SECONDS * 1_000_000_000)

SENSOR_POLL_MS = 4
SENSOR_POLL_NS = SENSOR_POLL_MS * 1_000_000

STOP_TIMEOUT_SECONDS = 2.0
STOP_REVOLUTION_MULTIPLIER = 2.5

STARTING_RPM = 110.0
STARTING_REV_NS = int(60_000_000_000 / STARTING_RPM)

REV_SMOOTHING = 1.0

PRINT_RPM = False


# ---------------------------------------------------------------------------
# PIO
#
# A1, A2 and A3 drive the three physical spokes.
# Each data line feeds the matching strip on both sides of the wheel.
# All six DotStar strips share SCK.
# ---------------------------------------------------------------------------

PIO_PROGRAM = """
.program dotstar_three_spokes
.side_set 1
.wrap_target
    out pins, 3 side 0
    nop         side 1
.wrap
"""

assembled = adafruit_pioasm.assemble(PIO_PROGRAM)

state_machine = rp2pio.StateMachine(
    assembled,
    frequency=PIO_FREQUENCY,
    first_out_pin=board.A1,
    out_pin_count=3,
    first_sideset_pin=board.SCK,
    sideset_pin_count=1,
    auto_pull=True,
    pull_threshold=24,
    out_shift_right=True,
    initial_out_pin_state=0,
    initial_out_pin_direction=0b111,
    initial_sideset_pin_state=0,
    initial_sideset_pin_direction=1,
)


# ---------------------------------------------------------------------------
# TMAG5273 HALL SENSOR
# ---------------------------------------------------------------------------

i2c = board.STEMMA_I2C()
tmag = adafruit_tmag5273.TMAG5273(i2c)

tmag.magnetic_channels = adafruit_tmag5273.MAG_CH_XYZ
tmag.conversion_average = adafruit_tmag5273.CONV_AVG_1X
tmag.operating_mode = adafruit_tmag5273.MODE_CONTINUOUS


# ---------------------------------------------------------------------------
# DOTSTAR DATA PACKING
# ---------------------------------------------------------------------------


def make_pin_table(pin_number):
    """Build packed PIO values for one DotStar data pin."""
    table = array("I", [0] * 256)

    for value in range(256):
        packed = 0

        for position in range(8):
            source_bit = 7 - position

            if value & (1 << source_bit):
                packed |= 1 << ((position * 3) + pin_number)

        table[value] = packed

    return table


PIN_A_BYTES = make_pin_table(0)
PIN_B_BYTES = make_pin_table(1)
PIN_C_BYTES = make_pin_table(2)


def pack_three_bytes(value_a, value_b, value_c):
    """Pack one byte for each of the three DotStar outputs."""
    return (
        PIN_A_BYTES[value_a]
        | PIN_B_BYTES[value_b]
        | PIN_C_BYTES[value_c]
    )


BRIGHTNESS_BYTE = 0xE0 | DOTSTAR_BRIGHTNESS

PACKED_BRIGHTNESS = pack_three_bytes(
    BRIGHTNESS_BYTE,
    BRIGHTNESS_BYTE,
    BRIGHTNESS_BYTE,
)

PACKED_END = pack_three_bytes(0xFF, 0xFF, 0xFF)

FRAME_WORDS = 4 + (NUM_LEDS * 4) + 4


# ---------------------------------------------------------------------------
# IMAGE HELPERS
# ---------------------------------------------------------------------------


def find_images():
    """Return all GIF and BMP files found in the image folder."""
    try:
        filenames = os.listdir(IMAGE_FOLDER)
    except OSError:
        return []

    images = []

    for filename in filenames:
        if filename.startswith("."):
            continue

        lower_name = filename.lower()

        if lower_name.endswith((".gif", ".bmp")):
            images.append(filename)

    images.sort()

    return images


def pixel_color(bitmap, shader, x_position, y_position):
    """Return one source pixel as 0xRRGGBB."""
    pixel_value = bitmap[x_position, y_position]

    try:
        return int(shader[pixel_value]) & 0xFFFFFF
    except TypeError:
        pass

    try:
        return int(shader.convert(pixel_value)) & 0xFFFFFF
    except (AttributeError, TypeError):
        pass

    return int(pixel_value) & 0xFFFFFF


def split_color(color):
    """Return red, green and blue values from a packed RGB color."""
    return (
        (color >> 16) & 0xFF,
        (color >> 8) & 0xFF,
        color & 0xFF,
    )


def pack_pixel_colors(color_a, color_b, color_c):
    """Pack three RGB colors into DotStar blue, green and red words."""
    rgb_a = split_color(color_a)
    rgb_b = split_color(color_b)
    rgb_c = split_color(color_c)

    return (
        pack_three_bytes(
            rgb_a[2],
            rgb_b[2],
            rgb_c[2],
        ),
        pack_three_bytes(
            rgb_a[1],
            rgb_b[1],
            rgb_c[1],
        ),
        pack_three_bytes(
            rgb_a[0],
            rgb_b[0],
            rgb_c[0],
        ),
    )


def calculate_repeats(width):
    """Return the number of image repeats for one wheel revolution."""
    repeats = int((SCANLINES_PER_REVOLUTION / width) + 0.5)

    return max(1, repeats)


def calculate_spoke_offsets(width, repeats):
    """Return source-image offsets for the three 120-degree spokes."""
    spoke_offset = int(round((repeats * width) / 3))

    return (
        0,
        spoke_offset % width,
        (spoke_offset * 2) % width,
    )


# ---------------------------------------------------------------------------
# IMAGE PREPACKING
# ---------------------------------------------------------------------------


def make_scanline_frame(bitmap, shader, x_position, spoke_offsets):
    """Build one complete DotStar frame for all three spokes."""
    frame = array("I", [0] * FRAME_WORDS)

    x_positions = (
        x_position,
        (x_position + spoke_offsets[1]) % bitmap.width,
        (x_position + spoke_offsets[2]) % bitmap.width,
    )

    index = 4

    for led_number in range(NUM_LEDS):
        source_y = (NUM_LEDS - 1) - led_number

        color_a = pixel_color(
            bitmap,
            shader,
            x_positions[0],
            source_y,
        )

        color_b = pixel_color(
            bitmap,
            shader,
            x_positions[1],
            source_y,
        )

        color_c = pixel_color(
            bitmap,
            shader,
            x_positions[2],
            source_y,
        )

        blue_word, green_word, red_word = pack_pixel_colors(
            color_a,
            color_b,
            color_c,
        )

        frame[index] = PACKED_BRIGHTNESS
        frame[index + 1] = blue_word
        frame[index + 2] = green_word
        frame[index + 3] = red_word

        index += 4

    frame[index] = PACKED_END
    frame[index + 1] = PACKED_END
    frame[index + 2] = PACKED_END
    frame[index + 3] = PACKED_END

    return frame


def load_image(filename):
    """Load one image and prepack it for fast POV playback."""
    path = IMAGE_FOLDER + "/" + filename

    gc.collect()

    bitmap, shader = adafruit_imageload.load(path)

    width = bitmap.width
    height = bitmap.height

    if height != NUM_LEDS:
        del bitmap
        del shader

        gc.collect()

        raise ValueError(
            f"Image must be exactly {NUM_LEDS} pixels high."
        )

    repeats = calculate_repeats(width)
    spoke_offsets = calculate_spoke_offsets(width, repeats)

    frames = []

    try:
        for x_position in range(width):
            frames.append(
                make_scanline_frame(
                    bitmap,
                    shader,
                    x_position,
                    spoke_offsets,
                )
            )

    except MemoryError as error:
        del frames
        del bitmap
        del shader

        gc.collect()

        raise MemoryError(
            f"Not enough RAM to prepack {filename}."
        ) from error

    del bitmap
    del shader

    gc.collect()

    return frames, width, repeats


# ---------------------------------------------------------------------------
# BLANK FRAME
# ---------------------------------------------------------------------------


def make_blank_frame():
    """Create one all-black DotStar frame."""
    frame = array("I", [0] * FRAME_WORDS)

    index = 4

    for _ in range(NUM_LEDS):
        frame[index] = PACKED_BRIGHTNESS
        frame[index + 1] = 0
        frame[index + 2] = 0
        frame[index + 3] = 0

        index += 4

    frame[index] = PACKED_END
    frame[index + 1] = PACKED_END
    frame[index + 2] = PACKED_END
    frame[index + 3] = PACKED_END

    return frame


BLANK_FRAME = make_blank_frame()


def blank_all():
    """Turn off all LED strips."""
    state_machine.write(BLANK_FRAME)


# ---------------------------------------------------------------------------
# IMAGE PLAYLIST
# ---------------------------------------------------------------------------

image_files = find_images()

if not image_files:
    raise RuntimeError("No GIF or BMP images found in /img.")

image_number = -1
scanline_frames = None
image_width = 0
image_repeats = 1


def load_next_usable_image():
    """Load the next image that can be successfully prepacked."""
    # pylint: disable=global-statement
    global image_number
    global scanline_frames
    global image_width
    global image_repeats

    if scanline_frames is not None:
        old_frames = scanline_frames
        scanline_frames = None

        del old_frames

        gc.collect()

    attempts = 0

    while attempts < len(image_files):
        image_number = (image_number + 1) % len(image_files)

        filename = image_files[image_number]

        try:
            (
                scanline_frames,
                image_width,
                image_repeats,
            ) = load_image(filename)

            print(
                "Now playing:",
                filename,
                "| width:",
                image_width,
                "| repeats:",
                image_repeats,
            )

            return

        except (
            MemoryError,
            ValueError,
            OSError,
            RuntimeError,
        ) as error:
            print()
            print("IMAGE SKIPPED")
            print("File:", filename)
            print("Error:", type(error).__name__)
            print("Reason:", error)
            print()

            attempts += 1

    raise RuntimeError("None of the images could be loaded.")


load_next_usable_image()


def send_scanline(line_number):
    """Send one prepacked scanline to the three physical spokes."""
    state_machine.write(scanline_frames[line_number])


# ---------------------------------------------------------------------------
# WHEEL TIMING
# ---------------------------------------------------------------------------

moving = False
magnet_active = False

last_sensor_ns = 0
last_magnet_ns = 0
last_revolution_ns = 0
magnet_clear_since_ns = 0
previous_valid_pass_ns = 0

valid_passes = 0

revolution_ns = STARTING_REV_NS

image_line = 0

scanline_period_ns = int(
    revolution_ns / (image_width * image_repeats)
)

now = time.monotonic_ns()

next_scanline_ns = now
image_change_ns = now


def update_scanline_timing():
    """Update POV scanline speed using the measured wheel revolution."""
    # pylint: disable=global-statement
    global scanline_period_ns

    total_lines = image_width * image_repeats

    target_line = int(
        round(
            (PATTERN_ROTATION_DEGREES / 360.0)
            * total_lines
        )
    ) % image_width

    phase_error = image_line - target_line

    if phase_error > image_width / 2:
        phase_error -= image_width

    elif phase_error < -(image_width / 2):
        phase_error += image_width

    correction = phase_error * STABILIZATION_STRENGTH

    corrected_lines = max(
        total_lines - correction,
        1,
    )

    hall_period_ns = int(
        revolution_ns / corrected_lines
    )

    minimum_rate_period_ns = int(
        1_000_000_000 / MIN_SCANLINES_PER_SECOND
    )

    scanline_period_ns = min(
        hall_period_ns,
        minimum_rate_period_ns,
    )


def update_magnet_state(now_ns, magnitude_sq):
    """Update magnet re-arm state."""
    # pylint: disable=global-statement
    global magnet_active
    global magnet_clear_since_ns

    if magnitude_sq <= MAG_RELEASE_SQ:
        if magnet_clear_since_ns == 0:
            magnet_clear_since_ns = now_ns

        if (
            magnet_active
            and now_ns - magnet_clear_since_ns
            >= HALL_CLEAR_NS
        ):
            magnet_active = False

    else:
        magnet_clear_since_ns = 0


def handle_magnet_pass(now_ns):
    """Process one valid Hall sensor magnet pass."""
    # pylint: disable=global-statement
    global last_magnet_ns
    global last_revolution_ns
    global previous_valid_pass_ns
    global valid_passes
    global revolution_ns
    global moving
    global next_scanline_ns
    global image_change_ns

    if (
        last_magnet_ns
        and now_ns - last_magnet_ns
        < MIN_REVOLUTION_MS * 1_000_000
    ):
        return

    last_magnet_ns = now_ns

    if last_revolution_ns:
        measured_ns = now_ns - last_revolution_ns

        revolution_ns = int(
            revolution_ns * (1.0 - REV_SMOOTHING)
            + measured_ns * REV_SMOOTHING
        )

        update_scanline_timing()

        if PRINT_RPM:
            rpm = 60_000_000_000.0 / revolution_ns
            print(f"RPM {rpm:.1f}")

    last_revolution_ns = now_ns

    if moving:
        return

    if (
        valid_passes == 0
        or now_ns - previous_valid_pass_ns
        > START_CONFIRM_NS
    ):
        valid_passes = 1

    else:
        valid_passes += 1

    previous_valid_pass_ns = now_ns

    if valid_passes >= 2:
        moving = True
        image_change_ns = now_ns
        next_scanline_ns = now_ns

        print("Wheel moving")


def check_hall(now_ns):
    """Poll the Hall sensor and update wheel speed."""
    # pylint: disable=global-statement
    global last_sensor_ns
    global magnet_active

    if now_ns - last_sensor_ns < SENSOR_POLL_NS:
        return

    last_sensor_ns = now_ns

    x_axis, y_axis, z_axis = tmag.magnetic

    magnitude_sq = (
        (x_axis * x_axis)
        + (y_axis * y_axis)
        + (z_axis * z_axis)
    )

    update_magnet_state(
        now_ns,
        magnitude_sq,
    )

    if (
        not magnet_active
        and magnitude_sq >= MAG_TRIGGER_SQ
    ):
        magnet_active = True

        handle_magnet_pass(now_ns)


# ---------------------------------------------------------------------------
# MAIN LOOP
# ---------------------------------------------------------------------------

blank_all()

print()
print("POV bike wheel ready.")
print("Images:", len(image_files))
print("Scanlines/revolution:", SCANLINES_PER_REVOLUTION)

while True:
    now = time.monotonic_ns()

    check_hall(now)

    # Stop after several missed Hall passes.
    if moving and last_magnet_ns:
        stop_timeout_ns = max(
            int(STOP_TIMEOUT_SECONDS * 1_000_000_000),
            int(
                revolution_ns
                * STOP_REVOLUTION_MULTIPLIER
            ),
        )

        if now - last_magnet_ns >= stop_timeout_ns:
            moving = False
            valid_passes = 0
            previous_valid_pass_ns = 0
            image_line = 0

            blank_all()

            print("Wheel stopped")

    if not moving:
        continue

    # Advance to the next image.
    if (
        len(image_files) > 1
        and now - image_change_ns
        >= int(IMAGE_SECONDS * 1_000_000_000)
    ):
        load_next_usable_image()

        image_line = 0

        update_scanline_timing()

        now = time.monotonic_ns()
        image_change_ns = now
        next_scanline_ns = now

        continue

    # Draw the next angular slice.
    if now >= next_scanline_ns:
        send_scanline(image_line)

        image_line += 1

        if image_line >= image_width:
            image_line = 0

        next_scanline_ns += scanline_period_ns

        # Skip stale frames instead of blasting through them after a delay.
        if now - next_scanline_ns > scanline_period_ns * 4:
            next_scanline_ns = now + scanline_period_ns
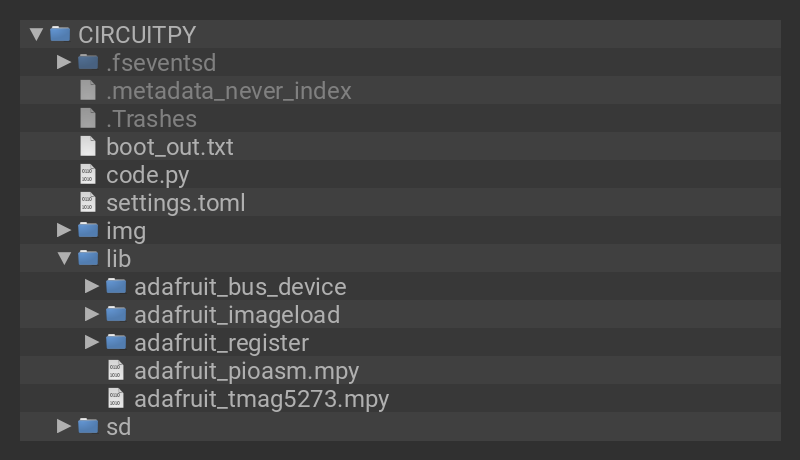
After downloading the bundle, plug the Feather RP2040 into your computer with a known good USB data+power cable. A drive named CIRCUITPY should appear in Finder or File Explorer.
Copy the following items to the CIRCUITPY drive:
- /lib folder
- code.py
- create a folder called /img and put all images inside
The /img folder contains the artwork displayed by the wheel. Add your own images to this folder to customize the artwork that shows.
The code watches the Hall effect sensor to determine how quickly the wheel is turning, then adjusts the LED timing to keep the persistence-of-vision images looking consistent as your speed changes. The three spokes work together to draw different sections of the same image around the wheel.
Configuration
The main settings are gathered near the top of code.py so you can customize the display without digging through the rest of the program.
NUM_LEDS = 36
IMAGE_FOLDER = "/img"
IMAGE_SECONDS = 8.0

SCANLINES_PER_REVOLUTION = 144
MIN_SCANLINES_PER_SECOND = 400.0

STABILIZATION_STRENGTH = 1.0
PATTERN_ROTATION_DEGREES = 30.0

DOTSTAR_BRIGHTNESS = 10
NUM_LEDS should match the number of DotStar LEDs on each spoke. This build uses 36 LEDs per strip.
IMAGE_SECONDS controls how long each image is displayed before the next image in the /img folder is loaded.
DOTSTAR_BRIGHTNESS controls the overall LED brightness. DotStars use a global brightness value from 0 to 31. Lower values save power and can actually make POV images easier to photograph at night.
Image Size and Repeats
All images must be exactly 36 pixels high to match the 36 LEDs running from the hub toward the rim.
The image width can vary.
SCANLINES_PER_REVOLUTION = 144
This setting determines approximately how much image data is drawn during one wheel revolution. Shorter images automatically repeat around the wheel.
36 pixels wide  = about 4 repeats
72 pixels wide  = about 2 repeats
144 pixels wide = about 1 repeat
Narrow geometric patterns tend to work especially well for POV. Wider images can display more complex artwork, but very long images may be harder to read clearly while riding.
Add your own .bmp or .gif files to the /img folder. The code will cycle through the files alphabetically.
If an image cannot be loaded — for example, if it is the wrong height or is too large to fit in memory — the code will skip it and continue to the next image.
Wheel Speed
The Hall effect sensor measures each wheel revolution and uses that timing to adjust the image playback speed.
MIN_SCANLINES_PER_SECOND = 400.0
This sets the minimum playback speed. At very slow wheel speeds, allowing the LEDs to update too slowly can make the image look incomplete or broken up. The default value of 400 keeps the animation moving fast enough to maintain a convincing POV effect.
For this build, I found the default value worked well and generally wouldn't recommend changing it unless you're experimenting with a different wheel size or LED layout.
Image Position
The Hall sensor also gives the code a reference point for the wheel position.
STABILIZATION_STRENGTH = 1.0
PATTERN_ROTATION_DEGREES = 30.0
STABILIZATION_STRENGTH controls how strongly the image timing corrects itself relative to the Hall sensor. A value of 1.0 works well for this build.
PATTERN_ROTATION_DEGREES rotates the displayed artwork around the wheel relative to the magnet. Change this value if your images consistently appear in an awkward part of the wheel.
Try values such as:
PATTERN_ROTATION_DEGREES = 0.0
PATTERN_ROTATION_DEGREES = 30.0
PATTERN_ROTATION_DEGREES = 90.0
This does not rotate the bitmap itself. It shifts where the repeating POV pattern appears around the wheel.
Hall Sensor Settings
The Hall effect sensor settings are also near the top of the file:
MAG_TRIGGER = 800.0
MAG_RELEASE = 450.0
These values determine when the code recognizes that the wheel magnet has passed the sensor.
The defaults were tuned for the magnet and sensor placement used in this build. You probably won't need to change them unless you're using a different magnet or mounting the sensor farther away.
The LEDs remain off while the wheel is stationary. After the code detects two valid magnet passes, the POV display starts automatically. When the wheel stops, the LEDs turn off again.
I think that’s about the right level for this guide: enough for someone to confidently change the artwork, timing, brightness, and image position, without forcing them through the PIO packing or Hall-state logic.
Page last edited September 16, 2026
Text editor powered by tinymce.


