

Overview

Here at Adafruit we're always looking for ways to make making easier - whether that's making breakout boards for hard-to-solder sensors or writing libraries to simplify motor control. Our new favorite way to program is CircuitPython.
Why CircuitPython?
CircuitPython is a variant of MicroPython, a very small version of Python that can fit on a microcontroller. Python is the fastest-growing programming language. It's taught in schools, used in coding bootcamps, popular with scientists and of course programmers at companies use it a lot!
CircuitPython adds the Circuit part to the Python part. It lets you program in Python and talk to Circuitry like sensors, motors, and LEDs!
CircuitPython on Microcontrollers
CircuitPython runs on microcontroller boards, such as our Feather, Metro, QT Py, and ItsyBitsy boards, using a variety of chips, such as the MicroChip SAMD21 SAMD51, the Raspberry Pi RP2040, the Nordic nRF52840, and the Espressif ESP32-S2 and ESP32-S3.
All of these chips have something in common - they are microcontrollers with hardware peripherals like SPI, I2C, ADCs etc. We squeeze Python into 'em and can then make the project portable.
But...sometimes you want to do more than a microcontroller can do. Like HDMI video output, or camera capture, or serving up a website, or just something that takes more memory and computing than a microcontroller board can do...
CircuitPython Libraries on Desktop Linux
By adding a software layer, you can use CircuitPython hardware control capabilities with "regular Python", as found on your desktop or single-board Linux computer/ There are tons of projects, libraries and example code for CircuitPython on microcontrollers, and thanks to the flexibility and power of Python its' pretty easy to get that code working on micro-computers like the Raspberry Pi or other single-board Linux computers with GPIO pins available.
You'll use a special library called adafruit_blinka (named after Blinka, the CircuitPython mascot) that provides a layer that translates the CircuitPython hardware API to whatever library the Linux board provides. For example, on Raspberry Pi we use the python RPi.GPIO library. For any I2C interfacing we'll use ioctl messages to the /dev/i2c device. For SPI we'll use the spidev python library, etc. These details don't matter so much because they all happen underneath the adafruit_blinka layer.
The upshot is that most code we write for CircuitPython will be instantly and easily runnable on Linux computers like Raspberry Pi.
In particular, you'll be able to use all of our device drivers - the sensors, led controllers, motor drivers, HATs, bonnets, etc. And nearly all of these use I2C or SPI!
The rest of this guide describes how to install and set up Blinka, and then how to use it to run CircuitPython code to control hardware.
Page last edited July 29, 2024
Text editor powered by tinymce.
CircuitPython & DragonBoard

CircuitPython Libraries on Linux & 96Boards DragonBoard
The next obvious step is to bring CircuitPython ease of use back to 'desktop Python'. We've got tons of projects, libraries and example code for CircuitPython on microcontrollers, and thanks to the flexibility and power of Python its pretty easy to get it working with microcomputers like the DragonBoard or other 'Linux with GPIO pins available' single board computers.
We'll use a special library called adafruit_blinka (named after Blinka, the CircuitPython mascot) to provide the layer that translates the CircuitPython hardware API to whatever library the Linux board provides. For example, on the DragonBoard we use the python libgpiod bindings. For any I2C interfacing we'll use ioctl messages to the /dev/i2c device. These details don't matter so much because they all happen underneath the adafruit_blinka layer.
The upshot is that any code we have for CircuitPython will be instantly and easily runnable on Linux computers like the DragonBoard.
In particular, we'll be able to use all of our device drivers - the sensors, led controllers, motor drivers, HATs, bonnets, etc. And nearly all of these use I2C or SPI!
Wait, isn't there already something that does this - libgpiod?
libgpiod is a python hardware interface class that works on the DragonBoard. It works just fine for I2C, SPI and GPIO but doesn't work with our drivers as it's a different API
By letting you use CircuitPython libraries on the DragonBoard via adafruit_blinka, you can unlock all of the drivers and example code we wrote! And you can keep using libgpiod if you like. We save time and effort so we can focus on getting code that works in one place, and you get to reuse all the code we've written already.
What about other Linux SBCs?
Yep! Blinka can easily be updated to add other boards. We've started with the ones we've got, so we could test them thoroughly. If you have other SBC board you'd like to adapt check out the adafruit_blinka code on github, pull requests are welcome as there's a ton of different Linux boards out there!
Page last edited July 29, 2024
Text editor powered by tinymce.
Initial Setup
Install Linaro on your DragonBoard 410c
We decided to try getting Blinka running in Linaro Debian because that's the recommended Debian installation available for the DragonBoard410c. Other distros could be made to work but you'd probably need to figure out how to detect the platform. Using other operating systems and CircuitPython is your call, we cannot provide support for that.
Download and install the latest linaro, for example we're using https://www.96boards.org/documentation/consumer/dragonboard/dragonboard410c/downloads/debian.md.html
There's some documentation to get started at https://www.96boards.org/documentation/consumer/dragonboard/dragonboard410c/installation/

If you are booting from an SD card, there's one small step you'll need to take before you can do that. There's a DIP switch on the underside labeled SD BOOT that you'll need to move to the ON position.
We've found the easiest way to connect is through a console cable, wired to the UART Serial port through a logic level shifter, and then on your computer, use a serial monitor at 115200 baud.


Once powered correctly and with the right SD card you should get a command prompt as root. You may need to press enter if it appears to stop.

You may want to create a new username, we recommend pi - if our instructions end up adding gpio access for the pi user, you can copy and paste them. You can do this by typing:
adduser pi
and then add the new user to the sudo group:
usermod -aG sudo pi

Just to secure the board, we also recommend you change the linaro user's password, which by default is linaro:
passwd linaro
Be sure to keep the password in a safe place in case you need it.

Once installed, you may want to enable mdns so you can ssh pi@linaro-developer instead of needing to know the IP address. First you will need to update, then install:
sudo apt updatesudo apt install avahi-daemon
then reboot
Connecting to the Network
Before you can use your DragonBoard 410c, you will need to connect to a network. The DragonBoard 410c does not come with any ethernet ports, but there's still a couple of different options available. The first option is to get a USB hub with an ethernet line.

Connecting to WiFi
The other option is to connect to an access point with the onboard WiFi.
To see a list of WiFi Access point SSIDs, type:
nmcli dev wifi list
To connect to a WIFI access point, first create the connection, replacing YOUR_SSID with your WiFi name:
nmcli con add con-name WiFi ifname wlan0 type wifi ssid YOUR_SSID
Then set up the password for your access point by enabling WPA PSK. Change this to the appropriate type if your connection is different.
nmcli con modify WiFi wifi-sec.key-mgmt wpa-psk
And add your password, replacing YOUR_PASSWORD with your WiFi password:
nmcli con modify WiFi wifi-sec.psk YOUR_PASSWORD
Finally enable the connection:
nmcli con up WiFi
You can check the connection status by typing:
nmcli connection show

Set your Python install to Python 3 Default
There's a few ways to do this, we recommend something like this:
sudo apt install -y python3 git python3-pipsudo update-alternatives --install /usr/bin/python python /usr/bin/python2.7 1sudo update-alternatives --install /usr/bin/python python /usr/bin/python3.7 2sudo update-alternatives --config python
Of course, change the version numbers if a newer version of Python is distributed.
Update Your Board and Python
Run the standard updates:
sudo apt update
sudo apt upgrade
Choose UTF-8 for character set if prompted
and
sudo pip3 install --upgrade setuptools
Update all your Python 3 packages with
pip3 freeze - local | grep -v '^\-e' | cut -d = -f 1 | xargs -n1 pip3 install -U
and
sudo bash
pip3 freeze - local | grep -v '^\-e' | cut -d = -f 1 | xargs -n1 pip3 install -U
Install libgpiod
libgpiod is what we use for gpio toggling. Fortunately it's available for the DragonBoard 410c. You can install it with the following command:
sudo apt install libgpiod2 python3-libgpiod gpiod

After installation, you should be able to import gpiod from within Python 3:

Enable UART, I2C and SPI
A vast number of our CircuitPython drivers use UART, I2C and SPI for interfacing, so you'll want to get those enabled.
You only have to do this once per board, unfortunately by default the SPI interface is disabled!

Install the support software with:
sudo apt install -y python-smbus python-dev i2c-toolssudo adduser pi i2c

To use SPI, you will need to enable SPIDEV by running the following commands to modify the device tree node:
cd ~git clone https://github.com/96boards/dt-updatecd dt-updatemakesudo scripts/db410c/enable-spidev.sh
Once you're done with both and have rebooted, verify you have the I2C and SPI devices with the command ls /dev/i2c* /dev/spi*
You should see at least one i2c device and one spi device


You can test to see what I2C addresses are connected by running sudo i2cdetect -r -y 0(on pins 15/17) or sudo i2cdetect -r -y 1 (on pins 19/21)
In this case I do have a sensor on the 'standard' i2c port i2c-0 under address 0x77
The UART1 Serial Console on the DragonBoard 410c is connected to /dev/ttyMSM0. The UART1 GPIO Serial Port is connected to /dev/ttyMSM1.
Install Python Libraries
Now you're ready to install all the Python support.
Run the following command to install wheel and flask:
sudo pip3 install wheel flask
Next, run the following command to install adafruit_blinka:
sudo pip3 install adafruit-blinka

The computer will install a few different libraries such as adafruit-pureio (our ioctl-only i2c library), Adafruit-GPIO (for detecting your board) and of course adafruit-blinka.
That's pretty much it! You're now ready to test.
Create a new file called blinkatest.py with nano or your favorite text editor and put the following in:
import board
import digitalio
import busio

print("Hello blinka!")

# Try to great a Digital input
pin = digitalio.DigitalInOut(board.GPIO_A)
print("Digital IO ok!")

# Try to create an I2C device
i2c = busio.I2C(board.SCL, board.SDA)
print("I2C ok!")

# Try to create an SPI device
spi = busio.SPI(board.SCLK, board.MOSI, board.MISO)
print("SPI ok!")

print("done!")
Save it and run at the command line with
sudo python3 blinkatest.py
You should see the following, indicating digital i/o, I2C and SPI all worked

Page last edited July 29, 2024
Text editor powered by tinymce.
Digital I/O
The first step with any new hardware is the 'hello world' of electronics - blinking an LED. This is very easy with CircuitPython and DragonBoard410c. We'll extend the example to also show how to wire up a button/switch.

Parts Used
Any old LED will work just fine as long as it's not an IR LED (you can't see those) and a 470 to 2.2K resistor


Some tactile buttons or switches:

Because the DragonBoard 410c uses 1.8V logic levels, you will need a logic level converter to interface with most peripherals.
We recommend using a breadboard and some male-male wires.

Wiring
- Connect the DragonBoard Ground pin to the blue ground rail on the breadboard
- Connect the DragonBoard +5V pin to the red 5V rail on the breadboard.
- Connect the DragonBoard +1.8V pin to the LV pin on the Logic Level Converter
- Connect the HV pin on the Logic Level Converter to the 5V rail
- Connect the Ground pin on the Logic Level Converter to the blue ground rail on the breadboard
- Connect one side of the tactile switch to the B1 pin on the Logic Level Converter
- Connect a ~10K pull up resistor from B1 to the 5V rail
- Connect the other side of the tactile switch to the ground rail
- Connect the longer/positive pin of the LED to the B2 pin on the Logic Level Converter
- Connect the shorter/negative pin of the LED to a 470ohm to 2.2K resistor, the other side of the resistor goes to ground rail
- Connect the DragonBoard GPIO_B pin (GPIO 12) to the A1 pin on the Logic Level Converter
- Connect the DragonBoard GPIO_A pin (GPIO 36) to the A2 pin on the Logic Level Converter

Double-check you have the right wires connected to the right location, it can be tough to keep track of GPIO pins as there are forty of them!
No additional libraries are needed so we can go straight on to the example code
However, we recommend running a pip3 update!
sudo pip3 install --upgrade adafruit_blinka
Blinky Time!
The finish line is right up ahead, let's start with an example that blinks the LED on and off once a second (half a second on, half a second off):
import time
import board
import digitalio

print("hello blinky!")

led = digitalio.DigitalInOut(board.GPIO_A)
led.direction = digitalio.Direction.OUTPUT

while True:
    led.value = True
    time.sleep(0.5)
    led.value = False
    time.sleep(0.5)
Verify the LED is blinking. If not, check that it's wired to the correct Logic Level Converter channel, that the Logic Level channel is connected to GPIO_A or GPIO_36, the resistor is installed correctly, and you have a Ground wire to the DragonBoard. Also, be sure to check the Power and Ground wires to the Logic Level Converter.
Type Control-C to quit
Button It Up
Now that you have the LED working, let's add code so the LED turns on whenever the button is pressed:
import time
import board
import digitalio

print("press the button!")

led = digitalio.DigitalInOut(board.GPIO_A)
led.direction = digitalio.Direction.OUTPUT

button = digitalio.DigitalInOut(board.GPIO_B)
button.direction = digitalio.Direction.INPUT
# use an external pullup since we don't have internal PU's
#button.pull = digitalio.Pull.UP

while True:
    led.value = not button.value # light when button is pressed!
Press the button - see that the LED lights up!
Type Control-C to quit
Page last edited July 29, 2024
Text editor powered by tinymce.
I2C Sensors & Devices
The most popular electronic sensors use I2C to communicate. This is a 'shared bus' 2 wire protocol, you can have multiple sensors connected to the two SDA and SCL pins as long as they have unique addresses (check this guide for a list of many popular devices and their addresses)
Lets show how to wire up a popular BME280. This sensor provides temperature, barometric pressure and humidity data over I2C
We're going to do this in a lot more depth than our guide pages for each sensor, but the overall technique is basically identical for any and all I2C sensors.
Honestly, the hardest part of using I2C devices is figuring out the I2C address and which pin is SDA and which pin is SCL!

Because the DragonBoard 410c uses 1.8V logic levels, you will need a logic level converter to interface with most peripherals.
We recommend using a breadboard and some male-male wires.
Wiring
- Connect the DragonBoard Ground pin to the ground on the Logic Level Converter
- Connect the DragonBoard +5V pin to the red 5V rail on the breadboard.
- Connect the DragonBoard +1.8V pin to the LV pin on the Logic Level Converter
- Connect the HV pin on the Logic Level Converter to the 5V rail
- Connect the Vin pin on the BME280 to the red 5V rail on the breadboard
- Connect the Ground pin on the BME280 to the ground on the Logic Level Converter
- Connect the B1 pin on the Logic Level Converter to the BME280 SCK
- Connect the B2 pin on the Logic Level Converter to the BME280 SDI
- Connect the DragonBoard I2C0 SCL to the A1 pin on the Logic Level Converter
- Connect the DragonBoard I2C0 SDA to the A2 pin on the Logic Level Converter

Double-check you have the right wires connected to the right location, it can be tough to keep track of header pins as there are forty of them!
After wiring, we recommend running I2C detection with sudo i2cdetect -r -y 0 to verify that you see the device, in this case its address 77

Install the CircuitPython BME280 Library
OK onto the good stuff, you can now install the Adafruit BME280 CircuitPython library.
As of this writing, not all libraries are up on PyPI so you may want to search before trying to install. Look for circuitpython and then the driver you want.

(If you don't see it you can open up a github issue on circuitpython to remind us!)
Once you know the name, install it with
sudo pip3 install adafruit-circuitpython-bme280

You'll notice we also installed a dependancy called adafruit-circuitpython-busdevice. This is a great thing about pip, if you have other required libraries they'll get installed too!
We also recommend an adafruit-blinka update in case we've fixed bugs:
sudo pip3 install --upgrade adafruit_blinka
Run that code!
The finish line is right up ahead. You can now run one of the (many in some cases) example scripts we've written for you.
Check out the examples for your library by visiting the repository for the library and looking in the example folder. In this case, it would be https://github.com/adafruit/Adafruit_CircuitPython_BME280/tree/master/examples
As of this writing there's only two examples. Here's the first one:
import time

import board
import busio
import adafruit_bme280

# Create library object using our Bus I2C port
i2c = busio.I2C(board.SCLK, board.SDA)
bme280 = adafruit_bme280.Adafruit_BME280_I2C(i2c)

# OR create library object using our Bus SPI port
#spi = busio.SPI(board.SCK, board.MOSI, board.MISO)
#bme_cs = digitalio.DigitalInOut(board.D10)
#bme280 = adafruit_bme280.Adafruit_BME280_SPI(spi, bme_cs)

# change this to match the location's pressure (hPa) at sea level
bme280.sea_level_pressure = 1013.25

while True:
    print("\nTemperature: %0.1f C" % bme280.temperature)
    print("Humidity: %0.1f %%" % bme280.humidity)
    print("Pressure: %0.1f hPa" % bme280.pressure)
    print("Altitude = %0.2f meters" % bme280.altitude)
    time.sleep(2)
Save this code to your DragonBoard by copying and pasting it into a text file, downloading it directly from the DragonBoard, etc.
Then in your command line run
sudo python3 bme280_simpletest.py

The code will loop with the sensor data until you quit with a Control-C
Here's the second example:
"""
Example showing how the BME280 library can be used to set the various
parameters supported by the sensor.
Refer to the BME280 datasheet to understand what these parameters do
"""
import time

import board
import busio
import adafruit_bme280

# Create library object using our Bus I2C port
i2c = busio.I2C(board.SCLK, board.SDA)
bme280 = adafruit_bme280.Adafruit_BME280_I2C(i2c)

# OR create library object using our Bus SPI port
#spi = busio.SPI(board.SCK, board.MOSI, board.MISO)
#bme_cs = digitalio.DigitalInOut(board.D10)
#bme280 = adafruit_bme280.Adafruit_BME280_SPI(spi, bme_cs)

# change this to match the location's pressure (hPa) at sea level
bme280.sea_level_pressure = 1013.25
bme280.mode = adafruit_bme280.MODE_NORMAL
bme280.standby_period = adafruit_bme280.STANDBY_TC_500
bme280.iir_filter = adafruit_bme280.IIR_FILTER_X16
bme280.overscan_pressure = adafruit_bme280.OVERSCAN_X16
bme280.overscan_humidity = adafruit_bme280.OVERSCAN_X1
bme280.overscan_temperature = adafruit_bme280.OVERSCAN_X2
#The sensor will need a moment to gather inital readings
time.sleep(1)

while True:
    print("\nTemperature: %0.1f C" % bme280.temperature)
    print("Humidity: %0.1f %%" % bme280.humidity)
    print("Pressure: %0.1f hPa" % bme280.pressure)
    print("Altitude = %0.2f meters" % bme280.altitude)
    time.sleep(2)
Save this code to your DragonBoard by copying and pasting it into a text file, downloading it directly from the DragonBoard, etc.
Then in your command line run
sudo python3 bme280_normal_mode.py

The code will loop with the sensor data until you quit with a Control-C
That's it! Now if you want to read the documentation on the library, what each function does in depth, visit our readthedocs documentation at
https://circuitpython.readthedocs.io/projects/bme280/en/latest/
Page last edited July 29, 2024
Text editor powered by tinymce.
SPI Sensors & Devices
SPI is less popular than I2C but still you'll see lots of sensors and chips use it. Unlike I2C, you don't have everything share two wires. Instead, there's three shared wires (clock, data in, data out) and then a unique 'chip select' line for each chip.
The nice thing about SPI is you can have as many chips as you like, even the same kind, all share the three SPI wires, as long as each one has a unique chip select pin.
The formal/technical names for the 4 pins used are:
- SPI clock - called SCLK, SCK or CLK
- SPI data out - called MOSI for Microcontroller Out Serial In. This is the wire that takes data from the Linux computer to the sensor/chip. Sometimes marked SDI or DI on chips
- SPI data in - called MISO for Microcontroller In Serial Out. This is the wire that takes data to the Linux computer from the sensor/chip. Sometimes marked SDO or DO on chips
- SPI chip select - called CS or CE
Remember, connect all SCK, MOSI and MISO pins together (unless there's some specific reason/instruction not to) and a unique CS pin for each device.
SPI on microcontrollers is fairly simple, you have an SPI peripheral and you can transfer data on it with some low level command. Its 'your job' as a programmer to control the CS lines with a GPIO. That's how CircuitPython is structured as well. busio does just the SPI transmit/receive part and busdevice handles the chip select pin as well.
Linux, on the other hand, doesn't let you send data to SPI without a CS line, and the CS lines are fixed in hardware as well. For example on the DragonBoard 410c, there's only one CS pin available for the hardware SPI pins - SPI_CS - and you have to use it. (In theory there's an ioctl option called no_cs but this does not actually work)
The upshot here is - to let you use more than 1 peripheral on SPI, we decided to let you use any CS pins you like, CircuitPython will toggle it the way you expect. But when we transfer SPI data we always tell the kernel to use SPI_CS. SPI_CS will toggle like a CS pin, but if we leave it disconnected, its no big deal
The upshot here is basically never connect anything to SPI_CS. Use whatever chip select pin you define in CircuitPython and just leave the CS pin alone, it will toggle as if it is the chip select line, completely on its own, so you shouldn't try to use it as a digital input/output/whatever.
Parts Used
OK now that we've gone thru the warning, let's wire up an SPI MAX31855 thermocouple sensor, this particular device doesn't have a MOSI pin so we'll not connect it.


Because the DragonBoard 410c uses 1.8V logic levels, you will need a logic level converter to interface with most peripherals.
We recommend using a breadboard and some male-male wires.
Wiring
- Connect the DragonBoard Ground pin to the blue ground rail on the breadboard
- Connect the DragonBoard +5V pin to the red 5V rail on the breadboard.
- Connect the DragonBoard +1.8V pin to the LV pin on the Logic Level Converter
- Connect the HV pin on the Logic Level Converter to the MAX3185 3Vo
- Connect the Ground pin on the Logic Level Converter to the blue ground rail on the breadboard
- Connect the Vin pin on the MAX31855 to the red 5V rail on the breadboard
- Connect the Ground pin on the MAX31855 to the blue ground rail on the breadboard
- Connect the B1 pin on the Logic Level Converter to the MAX31855 DO
- Connect the B2 pin on the Logic Level Converter to the MAX31855 CS
- Connect the B3 pin on the Logic Level Converter to the MAX31855 CLK
- Connect the DragonBoard SPI MISO to the A1 pin on the Logic Level Converter
- Connect the DragonBoard GPIO 12 to the A2 pin on the Logic Level Converter
- Connect the DragonBoard SPI CLK to the A3 pin on the Logic Level Converter

Double-check you have the right wires connected to the right location, it can be tough to keep track of Header pins as there are forty of them!
Install the CircuitPython MAX31855 Library
OK onto the good stuff, you can now install the Adafruit MAX31855 CircuitPython library.
As of this writing, not all libraries are up on PyPI so you may want to search before trying to install. Look for circuitpython and then the driver you want.

(If you don't see it you can open up a github issue on circuitpython to remind us!)
Once you know the name, install it with
sudo pip3 install adafruit-circuitpython-max31855

You'll notice we also installed a few other dependancies called spidev, adafruit-pureio, adafruit-circuitpython-busdevice and more. This is a great thing about pip, if you have other required libraries they'll get installed too!
We also recommend an adafruit-blinka update in case we've fixed bugs:
sudo pip3 install --upgrade adafruit_blinka
Run that code!
The finish line is right up ahead. You can now run one of the (many in some cases) example scripts we've written for you.
Check out the examples for your library by visiting the repository for the library and looking in the example folder. In this case, it would be https://github.com/adafruit/Adafruit_CircuitPython_MAX31855/tree/master/examples
As of this writing there's only one example. But that's cool, here it is:
# SPDX-FileCopyrightText: 2021 ladyada for Adafruit Industries
# SPDX-License-Identifier: MIT

import time

import board
import digitalio

import adafruit_max31855

spi = board.SPI()
cs = digitalio.DigitalInOut(board.D5)

max31855 = adafruit_max31855.MAX31855(spi, cs)
while True:
    tempC = max31855.temperature
    tempF = tempC * 9 / 5 + 32
    print(f"Temperature: {tempC} C {tempF} F ")
    time.sleep(2.0)
Save this code to your DragonBoard by copying and pasting it into a text file, downloading it directly from the Pi, etc.
Change the line that says
cs = digitalio.DigitalInOut(board.D5)
to
cs = digitalio.DigitalInOut(board.GPIO_12)
Then in your command line run
sudo python3 max31855_simpletest.py

The code will loop with the sensor data until you quit with a Control-C

That's it! Now if you want to read the documentation on the library, what each function does in depth, visit our readthedocs documentation at
https://circuitpython.readthedocs.io/projects/max31855/en/latest/
Page last edited July 29, 2024
Text editor powered by tinymce.
UART / Serial
After I2C and SPI, the third most popular "bus" protocol used is serial (also sometimes referred to as 'UART'). This is a non-shared two-wire protocol with an RX line, a TX line and a fixed baudrate. The most common devices that use UART are GPS units, MIDI interfaces, fingerprint sensors, thermal printers, and a scattering of sensors.
One thing you'll notice fast is that most Linux computers have minimal UARTs, often only 1 hardware port. And that hardware port may be shared with a console.
There are two ways to connect UART / Serial devices to your DragonBoard. The easy way, and the hard way.
We'll demonstrate wiring up & using an Ultimate GPS with both methods.

The Easy Way - An External USB-Serial Converter
By far the easiest way to add a serial port is to use a USB to serial converter cable or breakout. They're not expensive, and you simply plug it into the USB port. On the other end are wires or pins that provide power, ground, RX, TX and maybe some other control pads or extras.
Here are some options, they have varying chipsets and physical designs but all will do the job. We'll list them in order of recommendation.
The first cable is easy to use and even has little plugs that you can arrange however you like, it contains a CP2102
The CP2104 Friend is low cost, easy to use, but requires a little soldering, it has an '6-pin FTDI compatible' connector on the end, but all pins are broken out the sides.

Both the FTDI friend and cable use classic FTDI chips, these are more expensive than the CP2104 or PL2303 but sometimes people like them!


There is also a GPS module with integrated serial available which works like the GPS breakout connected to the USB to TTL Serial cable.

You can wire up the GPS by connecting the following
- GPS Vin to USB 5V or 3V (red wire on USB console cable)
- GPS Ground to USB Ground (black wire)
- GPS RX to USB TX (green wire)
- GPS TX to USB RX (white wire)

Once the USB adapter is plugged in, you'll need to figure out what the serial port name is. You can figure it out by unplugging-replugging in the USB and then typing dmesg | tail -10 (or just dmesg) and looking for text like this:

At the bottom, you'll see the 'name' of the attached device, in this case its ttyUSB0, that means our serial port device is available at /dev/ttyUSB0
If you don't want to plug in external hardware to the DragonBoard you can use the built in UART on the RX/TX pins. Unlike the Raspberry Pi, the DragonBoard isn't using the RX/TX pins for a console, those are on a different UART peripheral, so you should be good to go!
You can use the built in UART via /dev/ttyMSM1
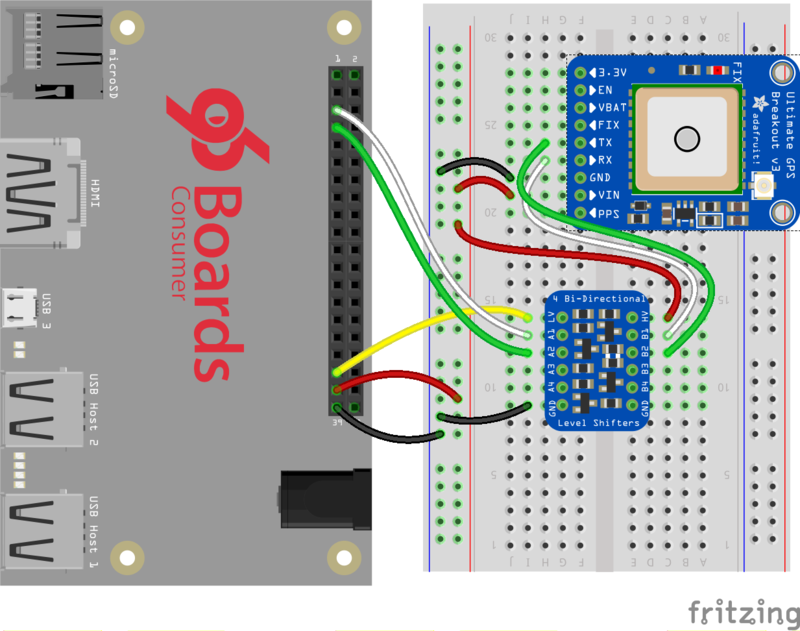
Wire the GPS as follows:
- Connect the DragonBoard Ground pin to the blue ground rail on the breadboard
- Connect the DragonBoard +5V pin to the red 5V rail on the breadboard.
- Connect the DragonBoard +1.8V pin to the LV pin on the Logic Level Converter
- Connect the HV pin on the Logic Level Converter to the red 5V rail
- Connect the Ground pin on the Logic Level Converter to the blue ground rail on the breadboard
- Connect the Vin pin on the GPS to the red 5V rail on the breadboard
- Connect the Ground pin on the GPS to the blue ground rail on the breadboard
- Connect the B1 pin on the Logic Level Converter to the GPS RX pin
- Connect the B2 pin on the Logic Level Converter to the GPS TX pin
- Connect the DragonBoard UART0 TX to the A1 pin on the Logic Level Converter
- Connect the DragonBoard UART0 RX to the A2 pin on the Logic Level Converter
Install the CircuitPython GPS Library
OK onto the good stuff, you can now install the Adafruit GPS CircuitPython library.
As of this writing, not all libraries are up on PyPI so you may want to search before trying to install. Look for circuitpython and then the driver you want.

(If you don't see it you can open up a github issue on circuitpython to remind us!)
Once you know the name, install it with
sudo pip3 install pyserial adafruit-circuitpython-gps
You'll notice we also installed a dependancy called pyserial. This is a great thing about pip, if you have other required libraries they'll get installed too!
We also recommend an adafruit-blinka update in case we've fixed bugs:
sudo pip3 install --upgrade adafruit_blinka
Run that code!
The finish line is right up ahead. You can now run one of the (many in some cases) example scripts we've written for you.
Check out the examples for your library by visiting the repository for the library and looking in the example folder. In this case, it would be https://github.com/adafruit/Adafruit_CircuitPython_GPS/tree/master/examples
Lets start with the simplest, the echo example:
# SPDX-FileCopyrightText: 2021 ladyada for Adafruit Industries
# SPDX-License-Identifier: MIT

# Simple GPS module demonstration.
# Will print NMEA sentences received from the GPS, great for testing connection
# Uses the GPS to send some commands, then reads directly from the GPS
import time

import board
import busio

import adafruit_gps

# Create a serial connection for the GPS connection using default speed and
# a slightly higher timeout (GPS modules typically update once a second).
# These are the defaults you should use for the GPS FeatherWing.
# For other boards set RX = GPS module TX, and TX = GPS module RX pins.
uart = busio.UART(board.TX, board.RX, baudrate=9600, timeout=10)

# for a computer, use the pyserial library for uart access
# import serial
# uart = serial.Serial("/dev/ttyUSB0", baudrate=9600, timeout=10)

# If using I2C, we'll create an I2C interface to talk to using default pins
# i2c = board.I2C()  # uses board.SCL and board.SDA
# i2c = board.STEMMA_I2C()  # For using the built-in STEMMA QT connector on a microcontroller

# Create a GPS module instance.
gps = adafruit_gps.GPS(uart)  # Use UART/pyserial
# gps = adafruit_gps.GPS_GtopI2C(i2c)  # Use I2C interface

# Initialize the GPS module by changing what data it sends and at what rate.
# These are NMEA extensions for PMTK_314_SET_NMEA_OUTPUT and
# PMTK_220_SET_NMEA_UPDATERATE but you can send anything from here to adjust
# the GPS module behavior:
#   https://cdn-shop.adafruit.com/datasheets/PMTK_A11.pdf

# Turn on the basic GGA and RMC info (what you typically want)
gps.send_command(b"PMTK314,0,1,0,1,0,0,0,0,0,0,0,0,0,0,0,0,0,0,0")
# Turn on just minimum info (RMC only, location):
# gps.send_command(b'PMTK314,0,1,0,0,0,0,0,0,0,0,0,0,0,0,0,0,0,0,0')
# Turn off everything:
# gps.send_command(b'PMTK314,0,0,0,0,0,0,0,0,0,0,0,0,0,0,0,0,0,0,0')
# Tuen on everything (not all of it is parsed!)
# gps.send_command(b'PMTK314,1,1,1,1,1,1,0,0,0,0,0,0,0,0,0,0,0,0,0')

# Set update rate to once a second (1hz) which is what you typically want.
gps.send_command(b"PMTK220,1000")
# Or decrease to once every two seconds by doubling the millisecond value.
# Be sure to also increase your UART timeout above!
# gps.send_command(b'PMTK220,2000')
# You can also speed up the rate, but don't go too fast or else you can lose
# data during parsing.  This would be twice a second (2hz, 500ms delay):
# gps.send_command(b'PMTK220,500')

# Main loop runs forever printing data as it comes in
timestamp = time.monotonic()
while True:
    data = gps.read(32)  # read up to 32 bytes
    # print(data)  # this is a bytearray type

    if data is not None:
        # convert bytearray to string
        data_string = "".join([chr(b) for b in data])
        print(data_string, end="")

    if time.monotonic() - timestamp > 5:
        # every 5 seconds...
        gps.send_command(b"PMTK605")  # request firmware version
        timestamp = time.monotonic()
We'll need to configure this code to work with our UART port name.
- If you're using a USB-to-serial converter, the device name is probably
/dev/ttyUSB0- but checkdmesgto make sure. - If you're using the built-in UART on the DragonBoard, the device name is
/dev/ttyMSM1.
Comment out the lines that reference board.TX, board.RX and busio.uart and uncomment the lines that import serial and define the serial device, like so:
# Define RX and TX pins for the board's serial port connected to the GPS.
# These are the defaults you should use for the GPS FeatherWing.
# For other boards set RX = GPS module TX, and TX = GPS module RX pins.
#RX = board.RX
#TX = board.TX

# Create a serial connection for the GPS connection using default speed and
# a slightly higher timeout (GPS modules typically update once a second).
#uart = busio.UART(TX, RX, baudrate=9600, timeout=3000)

# for a computer, use the pyserial library for uart access
import serial
uart = serial.Serial("/dev/ttyUSB0", baudrate=9600, timeout=3000)
And update the "/dev/ttyUSB0" device name if necessary to match your USB interface.
Whichever method you use, you should see output like this, with $GP "NMEA sentences" - there probably wont be actual location data because you haven't gotten a GPS fix. As long as you see those $GP strings sorta like the below, you've got it working!

Page last edited July 29, 2024
Text editor powered by tinymce.
More To Come!
That's just a taste of what we've got working so far
We're adding more support constantly, so please hold tight and visit the adafruit_blinka github repo to share your feedback and perhaps even submit some improvements!
If you'd like to contribute, but aren't sure where to start, check out the following guides:
Page last edited July 29, 2024
Text editor powered by tinymce.
FAQ & Troubleshooting
There's a few oddities when running Blinka/CircuitPython on Linux. Here's a list of stuff to watch for that we know of!
This FAQ covers all the various platforms and hardware setups you can run Blinka on. Therefore, some of the information may not apply to your specific setup.
Update Blinka/Platform Libraries
Most issues can be solved by forcing Python to upgrade to the latest blinka / platform-detect libraries. Try running
sudo python3 -m pip install --upgrade --force-reinstall adafruit-blinka Adafruit-PlatformDetect
Somehow you have ended up with either the wrong board module or no board module at all.
DO NOT try to fix this by manually installing a library named board. There is one out there and it has nothing to do with Blinka. You will break things if you install that library!
The easiest way to recover is to simply force a reinstall of Blinka with:python3 -m pip install --upgrade --force-reinstall adafruit-blinka
Additionally, and especially if you are using a more recent version of Python, you may run into this error if you either do not have a Virtual Environment active or setup. See the Python Virtual Environment Usage on Raspberry Pi guide for more information or check out the guide's Installation page.
Due to the way we share an SPI peripheral, you cannot have two SPI devices with different 'mode/polarity' on the same SPI bus - you'll get weird data
95% of SPI devices are mode 0, check the driver to see mode or polarity settings. For example:
- LSM9DS1 is mode 1, please use in I2C mode instead of SPI
- MAX31865 is phase 1, try using this on a separate SPI device, or read data twice.
This is due to having an older version of spidev. You need at least version 3.4. This should have been taken care of when you installed Blinka, but in some cases it does not seem to happen.
To check what version of spidev Python is using:
$ python3Python 3.6.8 (default, Oct 7 2019, 12:59:55)[GCC 8.3.0] on linuxType "help", "copyright", "credits" or "license" for more information.>>> import spidev>>> spidev.__version__'3.4'>>>
If you see a version lower then 3.4 reported, then try a force upgrade of spidev with (back at command line):
sudo python3 -m pip install --upgrade --force-reinstall spidev
Some Linux boards, for example, AllWinner-based, do not have support to set pull up or pull down on their GPIO. Use an external resistor instead!
If you are getting a stack trace that ends with something like:
return self._hid.read(64)File "hid.pyx", line 122, in hid.device.readOSError: read error
Try setting an environment variable named BLINKA_MCP2221_RESET_DELAY to a value of 0.5 or higher.
Windows:
set BLINKA_MCP2221_RESET_DELAY=0.5
Linux:
export BLINKA_MCP2221_RESET_DELAY=0.5
This is a value in seconds to wait between resetting the MCP2221 and the attempt to reopen it. The reset is seen by the operating system as a hardware disconnect/reconnect. Different operating systems can need different amounts of time to wait after the reconnect before the attempt to reopen. Setting the above environment variable will override the default reset delay time, allowing it to be increased as needed for different setups.
Blinka uses the libusbk driver to talk to the FT232H directly. If you have other FTDI devices installed that are using the FTDI VCP drivers, you may run into issues. See here for a possible workaround:
This is probably only an issue for older versions of Windows. If you run into something like this, see this issue thread:
https://github.com/pyusb/pyusb/issues/120
which describes copying the 32bit and 64bit DLLs into specific folders. (example for Win7)
Check out this issue thread:
https://github.com/pyusb/pyusb/issues/355
which has lots of discussion. It is probably worth reading through it all to determine what applies for your setup. Most solutions seem to rely on setting the DYLD_LIBRARY_PATH environment variable.
This issue thread has further information:
Some CircuitPython modules like may not be supported.
- Most SBCs do not have analog inputs so there is no
analogio - Few SBCs have
neopixelsupport so that is only available on Raspberry Pi (and any others that have low level neopixel protocol writing - Rotary encoders (
rotaryio) is handled by interrupts on microcontrollers, and is not supported on SBCs at this time - Likewise
pulseioPWM support is not supported on many SBCs, and if it is, it will not support a carrier wave (Infrared transmission) - For display usage, we suggest using python
Pillowlibrary orPygame, we do not havedisplayiosupport
We aim to have, at a minimum, digitalio and busio (I2C/SPI). This lets you use the vast number of driver libraries
For analog inputs, the MCP3xxx library will give you AnalogIn objects. For PWM outputs, try the PCA9685. For audio, use pygame or other Python3 libraries to play audio.
Some libraries, like Adafruit_CircuitPython_DHT will try to bit-bang if pulsein isn't available. Slow linux boards (<700MHz) may not be able to read the pins fast enough), you'll just have to try!
It looks like libgpiod may not be installed on your board.
Try running the command: sudo apt-get install libgpiod2
Be sure you have the latest libgpiod.py script and run it with the -l or --legacy flag:
sudo python3 libgpiod.py --legacy

All Raspberry Pi Computers Have:
- 1 x I2C port with busio (but clock stretching is not supported in hardware, so you must set the I2C bus speed to 10KHz to 'fix it')
- 2 x SPI ports with busio
- 1 x UART port with serial - note this is shared with the hardware console
- pulseio.pulseIn using gpiod
- neopixel support on a few pins
- No AnalogIn support (Use an MCP3008 or similar to add ADC)
- No PWM support (Use a PCA9685 or similar to add PWM)

Google Coral TPU Dev Boards Have:
- 1 x I2C port with busio
- 1 x SPI ports with busio
- 1 x UART port with serial - note this is shared with the hardware console
- 3 x PWMOut support
- No NeoPixel support
- No AnalogIn support (Use an MCP3008 or similar to add ADC)

Orange Pi PC Plus Boards Have:
- 1 x I2C port with busio
- 1 x SPI ports with busio
- 1 x UART port with serial
- No NeoPixel support
- No AnalogIn support (Use an MCP3008 or similar to add ADC)
- No PWM support (Use a PCA9685 or similar to add PWM)

Orange Pi R1 Boards Have:
- 1 x I2C port with busio
- 1 x SPI port with busio
- 1 x UART port with serial
- No NeoPixel support
- No AnalogIn support (Use an MCP3008 or similar to add ADC)
- No PWM support (Use a PCA9685 or similar to add PWM)

ODROID C2 Boards Have:
- 1 x I2C port with busio
- No SPI support
- 1 x UART port with serial - note this is shared with the hardware console
- No NeoPixel support
- No AnalogIn support (Use an MCP3008 or similar to add ADC)
- No PWM support (Use a PCA9685 or similar to add PWM)

DragonBoard 410c Boards Have:
- 2 x I2C port with busio
- 1 x SPI port with busio
- 1 x UART port with serial
- No NeoPixel support
- No AnalogIn support (Use an MCP3008 or similar to add ADC)
- No PWM support (Use a PCA9685 or similar to add PWM)

NVIDIA Jetson Nano Boards Have:
- 2 x I2C port with busio
- 2 x SPI ports with busio
- 2 x UART port with serial - note one of these is shared with the hardware console
- No NeoPixel support
- No AnalogIn support (Use an MCP3008 or similar to add ADC)
- No PWM support (Use a PCA9685 or similar to add PWM)

FT232H Breakouts Have:
- 1x I2C port OR SPI port with busio
- 12x GPIO pins with digitalio
- No UART
- No AnalogIn support
- No AnalogOut support
- No PWM support
If you are using Blinka in FT232H mode, then keep in mind these basic limitations.
- SPI and I2C can not be used at the same time since they share the same pins.
- GPIO speed is not super fast, so trying to do arbitrary bit bang like things may run into speed issues.
- There are no ADCs.
- There are no DACs.
- UART is not available (its a different FTDI mode)

MCP2221 Breakouts Have:
- 1x I2C port with busio
- 4x GPIO pins with digitalio
- 3x AnalogIn with analogio
- 1x AnalogOut with analogio
- 1x UART with pyserial
- No PWM support
- No hardware SPI support
If you are using Blinka in MCP2221 mode, then keep in mind these basic limitations.
- GPIO speed is not super fast, so trying to do arbitrary bit bang like things may run into speed issues.
- UART is available via
pyserial, the serial COM port shows up as a second USB device during enumeration
Page last edited July 29, 2024
Text editor powered by tinymce.


