

Code the Bubble Level
The project uses a specific set of CircuitPython libraries, and the main code.py file. To get everything you need, click on the Download Project Bundle link below, and uncompress the .zip file.
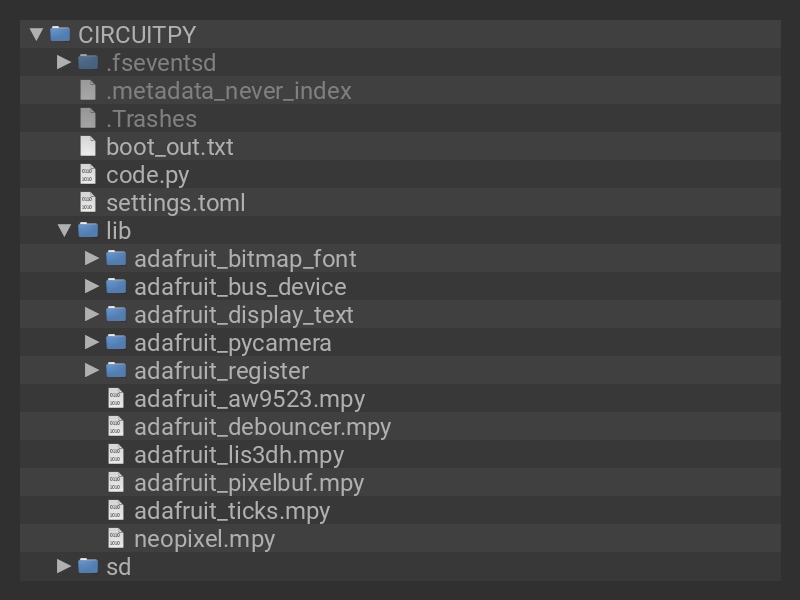
We can do this in one go. In the example code block below, click the Download Project Bundle button to download the necessary libraries and the code.py file as a zip file. Extract the contents of the zip file, open the directory MEMENTO/Memento_Bubble_Level/ and then click on the directory that matches the version of CircuitPython you're using and copy the contents of that directory to your CIRCUITPY drive.
CIRCUITPY
# SPDX-FileCopyrightText: Copyright (c) 2023 john park for Adafruit Industries
# SPDX-FileCopyrightText: 2026 Melissa LeBlanc-Williams for Adafruit Industries
#
# SPDX-License-Identifier: MIT
"""Camera preview with an accelerometer-driven bubble level for Adafruit MEMENTO."""

import math
import time

import adafruit_pycamera
import displayio
import vectorio

pycam = adafruit_pycamera.PyCamera()

# Settings
PHOTO_RESOLUTION = 8  # 0-12 preset resolutions:
#                      0: 240x240, 1: 320x240, 2: 640x480, 3: 800x600, 4: 1024x768,
#                      5: 1280x720, 6: 1280x1024, 7: 1600x1200, 8: 1920x1080, 9: 2048x1536,
#                      10: 2560x1440, 11: 2560x1600, 12: 2560x1920

LED_LEVEL = 0 # 0-4 preset brightness levels

FULL_SCALE_DEGREES = 8.0  # Bubble reaches the end at this much error
GREEN_DEGREES = 1.5
AMBER_DEGREES = 4.0
SMOOTHING = 0.18  # 0.0 = frozen, 1.0 = no filtering

# The gap between these angles prevents AUTO mode from flickering.
DOWN_ENTER_DEGREES = 35
DOWN_EXIT_DEGREES = 45

# Level geometry within the 240 x 32 band below the live preview.
BAR_WIDTH = 64
BAR_HEIGHT = 25
BAR_BOTTOM_MARGIN = 2
BUBBLE_RADIUS = 6

# Constants and Calculated Values
AUTO = 0
DOWN = 1
HORIZON = 2

GREEN = 0x00FF88
AMBER = 0xFFC43D
RED = 0xFF4D5A

BAR_LEFT = pycam.display.width // 2 - BAR_WIDTH // 2
BAR_TOP = pycam.display.height - BAR_HEIGHT - BAR_BOTTOM_MARGIN
BAR_CENTER_X = BAR_LEFT + BAR_WIDTH // 2
BAR_CENTER_Y = BAR_TOP + BAR_HEIGHT // 2
HORIZONTAL_TRAVEL = BAR_WIDTH // 2 - BUBBLE_RADIUS - 2
VERTICAL_TRAVEL = BAR_HEIGHT // 2 - BUBBLE_RADIUS - 2

def clamp(value, low, high):
    return max(low, min(high, value))

def level_color(error_degrees):
    if error_degrees <= GREEN_DEGREES:
        return GREEN
    if error_degrees <= AMBER_DEGREES:
        return AMBER
    return RED

def update_level(mode, _x_angle, _y_angle, _roll_angle):
    """Move and recolor the retained vector bubble."""
    down_references.hidden = mode != DOWN
    horizon_references.hidden = mode == DOWN

    if mode == DOWN:
        bubble_x = BAR_CENTER_X + int(
            clamp(_x_angle / FULL_SCALE_DEGREES, -1.0, 1.0) * HORIZONTAL_TRAVEL
        )
        bubble_y = BAR_CENTER_Y + int(
            clamp(_y_angle / FULL_SCALE_DEGREES, -1.0, 1.0) * VERTICAL_TRAVEL
        )
        error_amount = max(abs(_x_angle), abs(_y_angle))
    else:
        bubble_x = BAR_CENTER_X + int(
            clamp(_roll_angle / FULL_SCALE_DEGREES, -1.0, 1.0)
            * HORIZONTAL_TRAVEL
        )
        bubble_y = BAR_CENTER_Y
        error_amount = abs(_roll_angle)

    bubble_outline.x = bubble_x
    bubble_outline.y = bubble_y
    bubble_fill.x = bubble_x
    bubble_fill.y = bubble_y
    bubble_palette[0] = level_color(error_amount)

def take_photo(camera):
    camera.tone(1200, 0.04)
    camera.tone(1600, 0.04)
    try:
        camera.display_message("snap", color=0x00DD00)
        camera.capture_jpeg()
    except TypeError:
        camera.display_message("Capture failed", color=0xFF0000, scale=2)
        time.sleep(0.5)
    except RuntimeError:
        camera.display_message("No SD card", color=0xFF0000, scale=2)
        time.sleep(0.5)
    finally:
        camera.live_preview_mode()

pycam.mode = 0  # JPEG
pycam.resolution = PHOTO_RESOLUTION
pycam.led_level = LED_LEVEL
pycam.effect = 0

# Replace PyCamera's resolution/SD top bar with retained vector shapes. The
# camera preview begins at y=32, so this group never covers it.
black_palette = displayio.Palette(1)
black_palette[0] = 0x000000
white_palette = displayio.Palette(1)
white_palette[0] = 0xFFFFFF
bubble_palette = displayio.Palette(1)
bubble_palette[0] = RED

def white_rect(width, height, x, y):
    return vectorio.Rectangle(
        pixel_shader=white_palette, width=width, height=height, x=x, y=y
    )

level_group = displayio.Group()

# Four filled rectangles make an outlined vial.
level_group.append(white_rect(BAR_WIDTH, 1, BAR_LEFT, BAR_TOP))
level_group.append(
    white_rect(BAR_WIDTH, 1, BAR_LEFT, BAR_TOP + BAR_HEIGHT - 1)
)
level_group.append(white_rect(1, BAR_HEIGHT, BAR_LEFT, BAR_TOP))
level_group.append(
    white_rect(1, BAR_HEIGHT, BAR_LEFT + BAR_WIDTH - 1, BAR_TOP)
)

# DOWN gets a small two-axis target.
down_references = displayio.Group()
down_references.append(white_rect(9, 1, BAR_CENTER_X - 4, BAR_CENTER_Y))
down_references.append(white_rect(1, 9, BAR_CENTER_X, BAR_CENTER_Y - 4))
level_group.append(down_references)

# HORIZON gets three vertical vial marks.
horizon_references = displayio.Group()
for offset in (-HORIZONTAL_TRAVEL // 2, 0, HORIZONTAL_TRAVEL // 2):
    tick_height = 15 if offset == 0 else 9
    horizon_references.append(
        white_rect(
            1, tick_height, BAR_CENTER_X + offset, BAR_CENTER_Y - tick_height // 2
        )
    )
level_group.append(horizon_references)

bubble_outline = vectorio.Circle(
    pixel_shader=white_palette,
    radius=BUBBLE_RADIUS + 1,
    x=BAR_CENTER_X,
    y=BAR_CENTER_Y,
)
bubble_fill = vectorio.Circle(
    pixel_shader=bubble_palette,
    radius=BUBBLE_RADIUS - 1,
    x=BAR_CENTER_X,
    y=BAR_CENTER_Y,
)
level_group.append(bubble_outline)
level_group.append(bubble_fill)

# Add it on top of the toolbar
pycam.splash.append(level_group)
pycam.display.refresh()

mode_setting = AUTO
active_mode = HORIZON
screen_x, screen_y, forward = pycam.accel.acceleration
zero_down_x = 0.0
zero_down_y = 0.0
zero_horizon = 0.0
last_print = time.monotonic()

while True:
    frame = pycam.continuous_capture()
    pycam.keys_debounce()

    raw = pycam.accel.acceleration
    screen_x += (raw[0] - screen_x) * SMOOTHING
    screen_y += (raw[1] - screen_y) * SMOOTHING
    forward += (raw[2] - forward) * SMOOTHING

    angle_from_vertical = math.degrees(
        math.atan2(
            math.sqrt(screen_x * screen_x + screen_y * screen_y),
            abs(forward),
        )
    )

    if mode_setting == AUTO:
        if active_mode == HORIZON and angle_from_vertical <= DOWN_ENTER_DEGREES:
            active_mode = DOWN
        elif active_mode == DOWN and angle_from_vertical >= DOWN_EXIT_DEGREES:
            active_mode = HORIZON
    else:
        active_mode = mode_setting

    # atan2 keeps the reading stable even if total measured gravity varies.
    x_angle = math.degrees(math.atan2(screen_x, abs(forward))) - zero_down_x
    y_angle = math.degrees(math.atan2(screen_y, abs(forward))) - zero_down_y
    roll_angle = math.degrees(math.atan2(screen_x, abs(screen_y))) - zero_horizon

    if frame is not None and hasattr(frame, "width"):
        pycam.blit(frame)

    update_level(active_mode, x_angle, y_angle, roll_angle)
    pycam.display.refresh()

    if pycam.select.fell:
        mode_setting = (mode_setting + 1) % 3
        names = ("AUTO", "DOWN", "HORIZON")
        pycam.display_message(names[mode_setting], color=0xFFFFFF, scale=2)
        time.sleep(0.2)

    if pycam.ok.fell:
        if active_mode == DOWN:
            zero_down_x += x_angle
            zero_down_y += y_angle
            message = "DOWN zeroed"
        else:
            zero_horizon += roll_angle
            message = "HORIZON zeroed"
        pycam.display_message(message, color=0x00DD00, scale=2)
        time.sleep(0.2)

    if pycam.shutter.short_count:
        take_photo(pycam)

    if pycam.card_detect.fell:
        print("SD card removed")
        pycam.unmount_sd_card()
        pycam.display.refresh()

    if pycam.card_detect.rose:
        print("SD card inserted")
        pycam.display_message("Mounting SD", color=0xFFFFFF, scale=2)
        try:
            pycam.mount_sd_card()
        except OSError as error:
            print("SD mount failed:", error)
            pycam.display_message("SD failed", color=0xFF0000, scale=2)
            time.sleep(0.5)
        pycam.display.refresh()
How the Code Works
The code starts off with a few imports and a number of settings. We'll start by going over the settings. The first couple of settings are from the basic camera code and set the Resolution and LED modes:
# Settings
PHOTO_RESOLUTION = 8  # 0-12 preset resolutions:
#                      0: 240x240, 1: 320x240, 2: 640x480, 3: 800x600, 4: 1024x768,
#                      5: 1280x720, 6: 1280x1024, 7: 1600x1200, 8: 1920x1080, 9: 2048x1536,
#                      10: 2560x1440, 11: 2560x1600, 12: 2560x1920

LED_LEVEL = 0 # 0-4 preset brightness levels
The next series of settings are for the bubble level itself:
FULL_SCALE_DEGREES = 8.0  # Bubble reaches the end at this much error
GREEN_DEGREES = 1.5
AMBER_DEGREES = 4.0
SMOOTHING = 0.18  # 0.0 = frozen, 1.0 = no filtering

# The gap between these angles prevents AUTO mode from flickering.
DOWN_ENTER_DEGREES = 35
DOWN_EXIT_DEGREES = 45

# Level geometry within the 240 x 32 band below the live preview.
BAR_WIDTH = 64
BAR_HEIGHT = 25
BAR_BOTTOM_MARGIN = 2
BUBBLE_RADIUS = 6
Here are the settings specific to the bubble level:
- FULL_SCALE_DEGREES: The amount of tilt between one end of the level and the and the other on each axis
- GREEN_DEGREES: The tolerance in degrees for the bubble to show green
- AMBER_DEGREES: The tolerance in degrees for the bubble to show amber. This should always be larger than GREEN_DEGREES.
- SMOOTHING: This value is between 0.0 and 1.0 and controls how fast the bubble moves side to side. If it's too low, it will move very slowly and too fast will make it appear jittery. This is similar to controlling the viscosity of the liquid that the bubble moves through with low numbers being more viscous.
- DOWN_ENTER_DEGREES: This is the point in degrees that the bubble level changes modes and enters into a downward type level.
- DOWN_EXIT_DEGREES: This is the point in degrees that the bubble level changes modes and enters into a horizontal type level.
- BAR_WIDTH: The width of the bubble level bar
- BAR_HEIGHT: The height of the bubble level bar
- BAR_BOTTOM_MARGIN: The amount of gap from the bottom of the display
- BUBBLE_RADIUS: The size of the bubble itself
Helper Functions
There are a few functions that help with either simplifying the code by grouping sections that need to run multiple times or by just making the code easier to read:
clamp(): This function will keep a given value within a certain range. Any number outside this range will be set to the end of the range that it exceeds.
level_color(): This will return the color based on how close to the amount of levelness the camera is off by.
update_level(): This function will take the accelerometer values along with the current mode and update the UI elements to reflect the current level.
take_photo(): This function is the photo capture section from the basic camera example.
white_rectangle(): This function just creates and returns a white vectorio rectangle.
UI Elements
The UI elements are made from vectorio shapes. Since there are no line elements, they are mostly created using white rectangles. First the bar is added and then the downward facing and horizontal facing level elements are added, which display depending on the angle of the level.
The bubble itself is drawn next with an outline of white and a fill of the color determined by the amount of error. Afterwards, the rest of the UI is drawn as normal.
Main Loop
The main loop involves reading the accelerometer, applying a smoothing factor so that the bubble doesn't move too fast, and monitoring which mode the bubble level is in. After that, the update_level() function is called to update the UI elements.
The rest of the main loop involves checking for the SD card and updating the pycam library by calling its refresh method.
Page last edited July 30, 2026
Text editor powered by tinymce.


