

Overview

The Adafruit MagTag combines the new ESP32-S2 wireless module and a 2.9" grayscale E-Ink display to make a low-power IoT display that can show data on its screen even when power is removed! The ESP32-S2 is great because it builds on the years of code and support for the ESP32 and also adds native USB support so you can use this board with Arduino or CircuitPython!
New for 2025! After a long break, the MagTag is back in stock, we've found a 2.9" grayscale E-Ink display that replaces the old discontinued ILI0373. The new display has an SSD1680 chip driver and is supported in Arduino and CircuitPython version 10+!

We designed this board to be low-power friendly - with a spot for a 350 or 420 mAh battery and built in battery charging over USB C. During deep sleep, with the NeoPixels and speaker amplifier disabled, we measured 250uA power draw so you can run for a few weeks between charges.

And of course, the Mag in MagTag stands for magnetic. We have four M3 standoffs that will work perfectly with these mini magnet feet. (Originally they're designed for RGB Matrices but they'll do an excellent job here as well). Screw on the feet and you can attach this display to a metallic shelf, fridge, or bench.
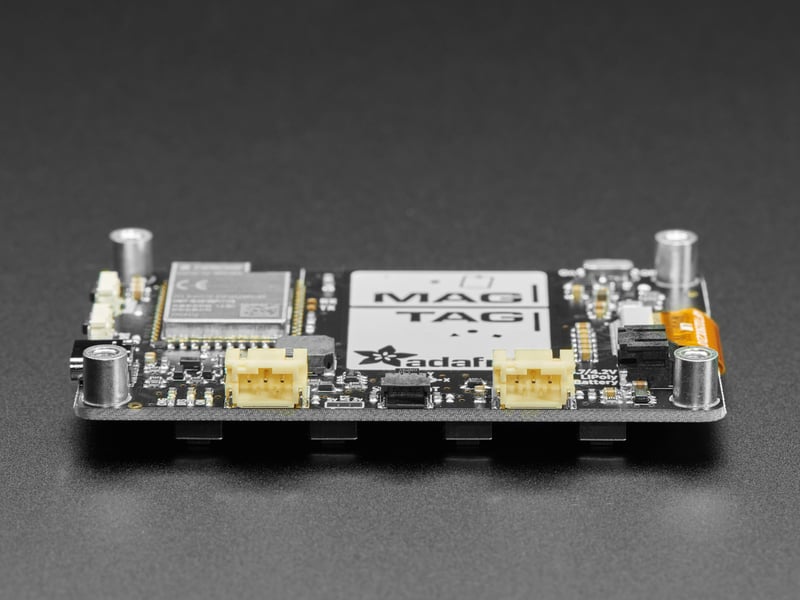
Here's the cool hardware we put together:
- ESP32-S2 240MHz Tensilica processor - the next generation of ESP32, now with native USB so it can act like a keyboard/mouse, MIDI device, disk drive, etc!
- WROVER module has FCC/CE certification and comes with 4 MByte of Flash and 2 MByte of PSRAM - you can have huge data buffers
- 2.9" grayscale display with 296x128 pixels. Each pixel can be white, light gray, dark gray or black. Compared to 'tri-color' displays with a red pigment, this display takes a lot less time to update, only about a second instead of 15 seconds!
- USB C power and data connector
- Four RGB side-emitting NeoPixels so you can light up the display with any color or pattern
- Four buttons can be used to wake up the ESP32 from deep-sleep, or select different modes
- Triple-axis accelerometer (LIS3DH) can be used to detect orientation of the display
- Speaker/Buzzer with mini class D amplifier on DAC output A0 can play tones or lo-fi audio clips.
- Front facing light sensor
- STEMMA QT port for attaching all sorts of I2C devices
- Two STEMMA 3 pin JST connectors for attaching NeoPixels, speakers, servos or relays.
- On/Off switch
- Boot and Reset buttons for re-programming

Revision History:
- As of July 22, 2025 – The display has been updated (old one discontinued); it now uses a modern SSD1680 chip instead of the discontinued ILI0373 - we have support in CircuitPython/Python/Arduino for it!
- As of June 17, 2022 - This board may come with a different regulator than AP2112K due to parts shortages. The regulator can provide at least 500mA.
- As of Dec 14, 2020 we're shipping with a different front silkscreen (black not white) Product is otherwise the same
Page last edited August 04, 2025
Text editor powered by tinymce.
Pinouts


The MagTag has a great eInk display. It's also packed with buttons, connectors and sensors. Time to take a tour!


Front and center is a 2.9" grayscale eInk display with 296x128 pixels. Each pixel can be white, light gray, dark gray or black.
To use with general Arduino libraries, the 2025 version of the MagTag uses the ThinkInk_290_Grayscale4_EAAMFGN. The original version of the MagTag uses GxEPD2_290_T5 - the Arduino library Adafruit uses is ThinkInk_290_Grayscale4_T5.
On the back, along the right side, the display cable wraps around the board to the display connector on the back.

The on/off switch is circled in red. Ensure the switch is on to use the board.
There are two ways to power the MagTag board: the USB type C connector or a 3.7/4.2V Lipoly battery.
Power Inputs
-
USB C port - This is used for both powering and programming the board. You can power it with any USB C cable and will request 5V from a USB C PD.
When USB is plugged in it will charge the Lipoly battery. If there is no battery attached, the yellow LED will flicker (it's looking for a battery!) -
LiPoly connector/charger - You can plug in any 250mAh or larger 3.7/4.2V Lipoly battery into this JST 2-PH port to both power your MagTag and charge the battery. The battery will charge from the USB, even if the board is powered off via the switch.
If the battery is plugged in and USB is plugged in, the MagTag will power itself from USB and it will charge the battery up.
When the battery is charging, the yellow CHG LED will be lit. When charging is complete, the LED will turn off.
Power Control
- On/Off switch - This switch controls power to the board. If you plug in your board and nothing happens, make sure the switch is flipped to "ON"!
Power LEDs
- OK LED - This green LED indicates the board is powered on, it is connected to the 3.3V power supply. This LED draws 40uA. If you need lower power you can remove this LED with a soldering iron.
- CHG LED - This yellow LED lets you know when the plugged in battery is charging and when it's fully charged. It's normal for this LED to flicker when no battery is in place, that's the charge circuitry trying to detect whether a battery is there or not.

The ESP32-S2 WROVER module.
The ESP32-S2 is a highly-integrated, low-power, 2.4 GHz Wi-Fi System-on-Chip (SoC) solution that now has built-in native USB as well as some other interesting new technologies like Time of Flight distance measurements. With its state-of-the-art power and RF performance, this SoC is an ideal choice for a wide variety of application scenarios relating to the Internet of Things (IoT), wearable electronics, and smart homes.
Please note, this is a single-core 240 MHz chip so it won't be as fast as ESP32's with dual-core. Also, there is no Bluetooth support. However, we are super excited about the ESP32-S2's native USB which unlocks a lot of capabilities for advanced interfacing! This WROVER module comes with 4 MB flash and 2 MB PSRAM.
The 4 MB of flash is inside the module and is used for both program firmware and filesystem storage. For example, in CircuitPython, we have 3 MB set aside for program firmware (this includes two OTA option spots as well) and a 1MB section for CircuitPython scripts and files.


NeoPixel LEDs and red LED.
- On the front of the board, along the top, are four addressable RGB side-emitting NeoPixel LEDs labeled together as NeoPix D1, and individually labeled #0, #1, #2, and #3, so you can light up the display with any color or pattern. You can use GPIO 1 to control the NeoPixels.
- On the back, on the bottom left, is a red LED labeled D13. It is user-controllable for blinky needs. You can blink this at any time.
To use the NeoPixel LEDs you must also set pin 21 to be an output and LOW - this is the NeoPixel power pin. If not using the NeoPixels, keep pin 21 as an input or HIGH output - that will remove the quiescent power usage of the NeoPixels so you can have lower power in sleep mode.

STEMMA QT - This JST SH 4-pin connector breaks out I2C (SCL, SDA, 3.3V, GND). It allows you to connect to various breakouts and sensors with STEMMA QT connectors or to other things using assorted associated accessories.
In CircuitPython, you can use the STEMMA connector with board.SCL and board.SDA, or board.STEMMA_I2C().
Works great with any STEMMA QT or Qwiic sensor/device
You can also use it with Grove I2C devices thanks to this handy cable

On the bottom are two connectors labeled D10 and A1. These are STEMMA 3 pin JST digital or analog connectors for attaching NeoPixels, speakers, servos or relays. These pins can be analog inputs or digital I/O.
Both connectors have protection 1K resistors + 3.6V zener diodes so you can drive an LED directly from the output. The maximum current from these connectors is 200mA.
A1 is a 'true' analog output. Both can be used for PWM as well as analog inputs. The maximum input voltage is 2.6V, after which the zener diode will kick in to drain excess voltage.
The power output is 5V by default, but a jumper can be cut/soldered to change it to 3.3V.


- Towards the middle of the board, at the bottom right corner of the ESP32-S2 module, is a speaker/buzzer labeled with A0 and a musical note. This includes a mini class D amplifier on DAC output A0 and can play tones or lo-fi audio clips.
- In the center of the board, towards the bottom, is an LIS3DH accelerometer labeled with X, Y and Z, that can be used to detect the orientation of the display. It is connected to the I2C port and available on I2C address 0x19. The IRQ line is connected to GPIO 9.
- On the front of the board, in the center of the top is a front-facing light sensor labeled with A3 and an eye.
Note that to use the speaker you must also set the speaker shutdown pin IO 16 to be an output and HIGH. If not playing audio, keep this pin as an input or LOW, to reduce the power usage of the amplifier circuit.
To use the light sensor you must also set pin 21 to be an output and LOW to turn on the power supply to it and the NeoPixels. If not using the light sensor or NeoPixels, keep pin 21 as an input or HIGH output - that will remove the quiescent power usage of the NeoPixels and light sensor so you can have lower power in sleep mode.

On the front of the board, along the bottom, there are four user-controllable buttons labeled both with pin names and a different arrow for each button. The buttons are on D11, D12, D14 and D15. Can be used to wake up the ESP32-S2 from deep-sleep, or select different modes.
There are no pull-ups on board, use internal pullups for this pins - when the buttons are pressed the IO pin labeled is set to LOW

- Reset button - The reset button in the top left corner is used to reset the board.
-
Boot0 button - This is connected to BOOT0 and can be used to put the board into ROM bootloader mode. To enter ROM bootloader mode, hold down the BOOT0 button while clicking reset button mentioned above. When in the ROM bootloader, you can upload code and query the chip using
esptool.

The hardware UART debug port has two broken out pins. You can connect these to a USB console cable in order to read the debug output from the ESP32 IDF. This is useful if you are writing software and need to see the low level debug output.
This is not where default Serial.print() or CircuitPython print() outputs go, because those will go through the USB port instead!
Page last edited August 04, 2025
Text editor powered by tinymce.
Update TinyUF2 Bootloader for CircuitPython 10 and Later
CircuitPython 10 changes the flash storage layout on Espressif boards with 4MB flash, to allow for larger CircuitPython builds with more features. This page describes how to update your bootloader to use the new storage layout.
Originally, these 4MB boards had two "ota" (over-the-air) partitions. One contained the CIrcuitPython firmware, and the other was empty, to be used as to update the firmware "over the air". However, that functionality was never fully developed, and the space consumed by the unused partition limited the firmware size of CIrcuitPython. The smaller partition size limited the features that could be included.
This diagram shows the old and new partition layout, and how the two partitions are combined into one.

Install the Updated TinyUF2 Bootloader on your Board
To update the TinyUF2 bootloader for your board, go to the Factory Reset section in this guide, and follow the instructions for UF2 Bootloader Installation/Repair. You will find a TinyUF2 bootloader listed for 4MB boards for CircuitPython 10.0.0.
Load a CircuitPython 10 (or later) build onto your board
After you've successfully loaded the new bootloader, when you double-click the Reset button, a ...BOOT drive should appear, such as FTHRS3BOOT. The INFO_UF2.TXT file in that drive should show that it's version 0.33.0 or later. At this point you can load the CircuitPython .uf2 file for your board as usual.
Note that this TinyUF2 upgrade is upward compatible with CircuitPython 9.1.0 and later, so if you need to go back to, say, CircuitPython 9.2.8 from CircuitPython 10, you don't need to reinstall the TinyUF2 bootloader.
Page last edited August 04, 2025
Text editor powered by tinymce.
Install CircuitPython

CircuitPython is a derivative of MicroPython designed to simplify experimentation and education on low-cost microcontrollers. It makes it easier than ever to get prototyping by requiring no upfront desktop software downloads. Simply copy and edit files on the CIRCUITPY drive to iterate.


Click the link above and download the latest .BIN and .UF2 file
You can use a 9.x.x release for a pre-2025 MagTag. You must use a 10.x.x release for the updated MagTag 2025 Edition.
(depending on how you program the ESP32S2 board you may need one or the other, might as well get both)
Download and save it to your desktop (or wherever is handy).

Plug your MagTag into your computer using a known-good USB cable.
A lot of people end up using charge-only USB cables and it is very frustrating! So make sure you have a USB cable you know is good for data sync.
Option 1 - Load with UF2 Bootloader
This is by far the easiest way to load CircuitPython. However it requires your board has the UF2 bootloader installed. Some early boards do not (we hadn't written UF2 yet!) - in which case you can load using the built in ROM bootloader.
Still, try this first!

Try Launching UF2 Bootloader
Loading CircuitPython by drag-n-drop UF2 bootloader is the easier way and we recommend it. If you have a MagTag where the front of the board is black, your MagTag came with UF2 already on it.

Launch UF2 by double-clicking the Reset button (the one next to the USB C port). You may have to try a few times to get the timing right.


If you're using Windows and you get an error at the end of the file copy that says Error from the file copy, Error 0x800701B1: A device which does not exist was specified. You can ignore this error, the bootloader sometimes disconnects without telling Windows, the install completed just fine and you can continue. If its really annoying, you can also upgrade the bootloader (the latest version of the UF2 bootloader fixes this warning)

Your board should auto-reset into CircuitPython, or you may need to press reset. A CIRCUITPY drive will appear. You're done! Go to the next pages.
Option 2 - Use esptool to load BIN file
If you have an original MagTag with while soldermask on the front, we didn't have UF2 written for the ESP32S2 yet so it will not come with the UF2 bootloader.
You can upload with esptool to the ROM (hardware) bootloader instead!

Follow the initial steps found in the Run esptool and check connection section of the ROM Bootloader page to verify your environment is set up, your board is successfully connected, and which port it's using.
In the final command to write a binary file to the board, replace the port with your port, and replace "firmware.bin" with the the file you downloaded above.
The output should look something like the output in the image.

Press reset to exit the bootloader.
Your CIRCUITPY drive should appear!
You're all set! Go to the next pages.
Option 3 - Use Chrome Browser To Upload BIN file
If for some reason you cannot get esptool to run, you can always try using the Chrome-browser version of esptool we have written. This is handy if you don't have Python on your computer, or something is really weird with your setup that makes esptool not run (which happens sometimes and isn't worth debugging!) You can follow along on the Web Serial ESPTool page and either load the UF2 bootloader and then come back to Option 1 on this page, or you can download the CircuitPython BIN file directly using the tool in the same manner as the bootloader.
Page last edited August 04, 2025
Text editor powered by tinymce.
CircuitPython Internet Test
One of the great things about most Espressif microcontrollers are their built-in WiFi capabilities. This page covers the basics of getting connected using CircuitPython.
The first thing you need to do is update your code.py to the following (it will error until WiFi details are added). Click the Download Project Bundle button to download the necessary libraries and the code.py file in a zip file. Extract the contents of the zip file, and copy the entire lib folder and the code.py file to your CIRCUITPY drive.
# SPDX-FileCopyrightText: 2020 Brent Rubell for Adafruit Industries
#
# SPDX-License-Identifier: MIT

import os
import ipaddress
import ssl
import wifi
import socketpool
import adafruit_requests

# URLs to fetch from
TEXT_URL = "http://wifitest.adafruit.com/testwifi/index.html"
JSON_QUOTES_URL = "https://www.adafruit.com/api/quotes.php"
JSON_STARS_URL = "https://api.github.com/repos/adafruit/circuitpython"

print("ESP32-S2 WebClient Test")

print(f"My MAC address: {[hex(i) for i in wifi.radio.mac_address]}")

print("Available WiFi networks:")
for network in wifi.radio.start_scanning_networks():
    print("\t%s\t\tRSSI: %d\tChannel: %d" % (str(network.ssid, "utf-8"),
                                             network.rssi, network.channel))
wifi.radio.stop_scanning_networks()

print(f"Connecting to {os.getenv('CIRCUITPY_WIFI_SSID')}")
wifi.radio.connect(os.getenv("CIRCUITPY_WIFI_SSID"), os.getenv("CIRCUITPY_WIFI_PASSWORD"))
print(f"Connected to {os.getenv('CIRCUITPY_WIFI_SSID')}")
print(f"My IP address: {wifi.radio.ipv4_address}")

ping_ip = ipaddress.IPv4Address("8.8.8.8")
ping = wifi.radio.ping(ip=ping_ip)

# retry once if timed out
if ping is None:
    ping = wifi.radio.ping(ip=ping_ip)

if ping is None:
    print("Couldn't ping 'google.com' successfully")
else:
    # convert s to ms
    print(f"Pinging 'google.com' took: {ping * 1000} ms")

pool = socketpool.SocketPool(wifi.radio)
requests = adafruit_requests.Session(pool, ssl.create_default_context())

print(f"Fetching text from {TEXT_URL}")
response = requests.get(TEXT_URL)
print("-" * 40)
print(response.text)
print("-" * 40)

print(f"Fetching json from {JSON_QUOTES_URL}")
response = requests.get(JSON_QUOTES_URL)
print("-" * 40)
print(response.json())
print("-" * 40)

print()

print(f"Fetching and parsing json from {JSON_STARS_URL}")
response = requests.get(JSON_STARS_URL)
print("-" * 40)
print(f"CircuitPython GitHub Stars: {response.json()['stargazers_count']}")
print("-" * 40)

print("Done")
Your CIRCUITPY drive should resemble the following.

To get connected, the next thing you need to do is update the settings.toml file.
The settings.toml File
We expect people to share tons of projects as they build CircuitPython WiFi widgets. What we want to avoid is people accidentally sharing their passwords or secret tokens and API keys. So, we designed all our examples to use a settings.toml file, that is on your CIRCUITPY drive, to hold secret/private/custom data. That way you can share your main project without worrying about accidentally sharing private stuff.
If you have a fresh install of CircuitPython on your board, the initial settings.toml file on your CIRCUITPY drive is empty.
To get started, you can update the settings.toml on your CIRCUITPY drive to contain the following code.
# SPDX-FileCopyrightText: 2023 Adafruit Industries
#
# SPDX-License-Identifier: MIT

# This is where you store the credentials necessary for your code.
# The associated demo only requires WiFi, but you can include any
# credentials here, such as Adafruit IO username and key, etc.
CIRCUITPY_WIFI_SSID = "your-wifi-ssid"
CIRCUITPY_WIFI_PASSWORD = "your-wifi-password"
This file should contain a series of Python variables, each assigned to a string. Each variable should describe what it represents (say wifi_ssid), followed by an = (equals sign), followed by the data in the form of a Python string (such as "my-wifi-password" including the quote marks).
At a minimum you'll need to add/update your WiFi SSID and WiFi password, so do that now!
As you make projects you may need more tokens and keys, just add them one line at a time. See for example other tokens such as one for accessing GitHub or the Hackaday API. Other non-secret data like your timezone can also go here.
For the correct time zone string, look at http://worldtimeapi.org/timezones and remember that if your city is not listed, look for a city in the same time zone, for example Boston, New York, Philadelphia, Washington DC, and Miami are all on the same time as New York.
Of course, don't share your settings.toml - keep that out of GitHub, Discord or other project-sharing sites.
If you connect to the serial console, you should see something like the following:

In order, the example code...
Checks the ESP32's MAC address.
print(f"My MAC address: {[hex(i) for i in wifi.radio.mac_address]}")
Performs a scan of all access points and prints out the access point's name (SSID), signal strength (RSSI), and channel.
print("Available WiFi networks:")
for network in wifi.radio.start_scanning_networks():
    print("\t%s\t\tRSSI: %d\tChannel: %d" % (str(network.ssid, "utf-8"),
                                             network.rssi, network.channel))
wifi.radio.stop_scanning_networks()
Connects to the access point you defined in the settings.toml file, and prints out its local IP address.
print(f"Connecting to {os.getenv('WIFI_SSID')}")
wifi.radio.connect(os.getenv("WIFI_SSID"), os.getenv("WIFI_PASSWORD"))
print(f"Connected to {os.getenv('WIFI_SSID')}")
print(f"My IP address: {wifi.radio.ipv4_address}")
Attempts to ping a Google DNS server to test connectivity. If a ping fails, it returns None. Initial pings can sometimes fail for various reasons. So, if the initial ping is successful (is not None), it will print the echo speed in ms. If the initial ping fails, it will try one more time to ping, and then print the returned value. If the second ping fails, it will result in "Ping google.com: None ms" being printed to the serial console. Failure to ping does not always indicate a lack of connectivity, so the code will continue to run.
ping_ip = ipaddress.IPv4Address("8.8.8.8")
ping = wifi.radio.ping(ip=ping_ip) * 1000
if ping is not None:
print(f"Ping google.com: {ping} ms")
else:
ping = wifi.radio.ping(ip=ping_ip)
print(f"Ping google.com: {ping} ms")
The code creates a socketpool using the wifi radio's available sockets. This is performed so we don't need to re-use sockets. Then, it initializes a a new instance of the requests interface - which makes getting data from the internet really really easy.
pool = socketpool.SocketPool(wifi.radio) requests = adafruit_requests.Session(pool, ssl.create_default_context())
To read in plain-text from a web URL, call requests.get - you may pass in either a http, or a https url for SSL connectivity.
print(f"Fetching text from {TEXT_URL}")
response = requests.get(TEXT_URL)
print("-" * 40)
print(response.text)
print("-" * 40)
Requests can also display a JSON-formatted response from a web URL using a call to requests.get.
print(f"Fetching json from {JSON_QUOTES_URL}")
response = requests.get(JSON_QUOTES_URL)
print("-" * 40)
print(response.json())
print("-" * 40)
Finally, you can fetch and parse a JSON URL using requests.get. This code snippet obtains the stargazers_count field from a call to the GitHub API.
print(f"Fetching and parsing json from {JSON_STARS_URL}")
response = requests.get(JSON_STARS_URL)
print("-" * 40)
print(f"CircuitPython GitHub Stars: {response.json()['stargazers_count']}")
print("-" * 40)
OK you now have your ESP32 board set up with a proper settings.toml file and can connect over the Internet. If not, check that your settings.toml file has the right SSID and password and retrace your steps until you get the Internet connectivity working!
IPv6 Networking
Starting in CircuitPython 9.2, IPv6 networking is available on most Espressif wifi boards. Socket-using libraries like adafruit_requests and adafruit_ntp will need to be updated to use the new APIs and for now can only connect to services on IPv4.
IPv6 connectivity & privacy
IPv6 addresses are divided into many special kinds, and many of those kinds (like those starting with FC, FD, FE) are private or local; Addresses starting with other prefixes like 2002: and 2001: are globally routable. In 2024, far from all ISPs and home networks support IPv6 internet connectivity. For more info consult resources like Wikipedia. If you're interested in global IPv6 connectivity you can use services like Hurricane Electric to create an "IPv6 tunnel" (free as of 2024, but requires expertise and a compatible router or host computer to set up)
It's also important to be aware that, as currently implemented by Espressif, there are privacy concerns especially when these devices operate on the global IPv6 network: The device's unique identifier (its EUI-64 or MAC address) is used by default as part of its IPv6 address. This means that the device identity can be tracked across multiple networks by any service it connects to.
Enable IPv6 networking
Due to the privacy consideration, IPv6 networking is not automatically enabled. Instead, it must be explicitly enabled by a call to start_dhcp_client with the ipv6=True argument specified:
wifi.start_dhcp_client(ipv6=True)
Check IP addresses
The read-only addresses property of the wifi.radio object holds all addresses, including IPv4 and IPv6 addresses:
>>> wifi.radio.addresses
('FE80::7EDF:A1FF:FE00:518C', 'FD5F:3F5C:FE50:0:7EDF:A1FF:FE00:518C', '10.0.3.96')
The wifi.radio.dns servers can be IPv4 or IPv6:
>>> wifi.radio.dns
('FD5F:3F5C:FE50::1',)
>>> wifi.radio.dns = ("1.1.1.1",)
>>> wifi.radio.dns
('1.1.1.1',)
>>> wifi.radio.ping("google.com")
0.043
>>> wifi.radio.ping("ipv6.google.com")
0.048
Create & use IPv6 sockets
Use the address family socket.AF_INET6. After the socket is created, use methods like connect, send, recfrom_into, etc just like for IPv4 sockets. This code snippet shows communicating with a private-network NTP server; this IPv6 address will not work on your network:
>>> ntp_addr = ("fd5f:3f5c:fe50::20e", 123)
>>> PACKET_SIZE = 48
>>>
>>> buf = bytearray(PACKET_SIZE)
>>> with socket.socket(socket.AF_INET6, socket.SOCK_DGRAM) as s:
... s.settimeout(1)
... buf[0] = 0b0010_0011
... s.sendto(buf, ntp_addr)
... print(s.recvfrom_into(buf))
... print(buf)
...
48
(48, ('fd5f:3f5c:fe50::20e', 123))
bytearray(b'$\x01\x03\xeb\x00\x00\x00\x00\x00\x00\x00GGPS\x00\xeaA0h\x07s;\xc0\x00\x00\x00\x00\x00\x00\x00\x00\xeaA0n\xeb4\x82-\xeaA0n\xebAU\xb1')
Page last edited August 04, 2025
Text editor powered by tinymce.
Getting The Date & Time
A very common need for projects is to know the current date and time. Especially when you want to deep sleep until an event, or you want to change your display based on what day, time, date, etc. it is
Determining the correct local time is really really hard. There are various time zones, Daylight Savings dates, leap seconds, etc. Trying to get NTP time and then back-calculating what the local time is, is extraordinarily hard on a microcontroller just isn't worth the effort and it will get out of sync as laws change anyways.
For that reason, we have the free adafruit.io time service. Free for anyone with a free adafruit.io account. You do need an account because we have to keep accidentally mis-programmed-board from overwhelming adafruit.io and lock them out temporarily. Again, it's free!
Step 1) Make an Adafruit account
It's free! Visit https://accounts.adafruit.com/ to register and make an account if you do not already have one
Step 2) Sign into Adafruit IO
Head over to io.adafruit.com and click Sign In to log into IO using your Adafruit account. It's free and fast to join.

You will get a popup with your Username and Key (In this screenshot, we've covered it with red blocks)

Go to the settings.toml file on your CIRCUITPY drive (or create one with the text editor with your operating system) and add three lines for AIO_USERNAME, ADAFRUIT_AIO_KEY and TIMEZONE so you get something like the following:
# This file is where you keep secret settings, passwords, and tokens! # If you put them in the code you risk committing that info or sharing it CIRCUITPY_WIFI_SSID = "your-wifi-ssid" CIRCUITPY_WIFI_PASSWORD = "your-wifi-password" ADAFRUIT_AIO_USERNAME = "your-adafruit-io-username" ADAFRUIT_AIO_KEY = "your-adafruit-io-key" # Timezone names from http://worldtimeapi.org/timezones TIMEZONE="America/New_York"
The timezone is optional, if you don't have that entry, adafruit.io will guess your timezone based on geographic IP address lookup. You can visit http://worldtimeapi.org/timezones to see all the time zones available (even though we do not use Worldtime for time-keeping, we do use the same time zone table).
Step 4) Upload Test Python Code
This code is like the Internet Test code from before, but this time it will connect to adafruit.io and get the local time
import ipaddress
import os
import ssl
import wifi
import socketpool
import adafruit_requests
# Get our username, key and desired timezone
ssid = os.getenv("CIRCUITPY_WIFI_SSID")
password = os.getenv("CIRCUITPY_WIFI_PASSWORD")
aio_username = os.getenv("ADAFRUIT_AIO_USERNAME")
aio_key = os.getenv("ADAFRUIT_AIO_KEY")
timezone = os.getenv("TIMEZONE")
TIME_URL = f"https://io.adafruit.com/api/v2/{aio_username}/integrations/time/strftime?x-aio-key={aio_key}&tz={timezone}"
TIME_URL += "&fmt=%25Y-%25m-%25d+%25H%3A%25M%3A%25S.%25L+%25j+%25u+%25z+%25Z"
print("ESP32-S2 Adafruit IO Time test")
print("My MAC addr:", [hex(i) for i in wifi.radio.mac_address])
print("Available WiFi networks:")
for network in wifi.radio.start_scanning_networks():
    print("\t%s\t\tRSSI: %d\tChannel: %d" % (str(network.ssid, "utf-8"),
                                             network.rssi, network.channel))
wifi.radio.stop_scanning_networks()
print("Connecting to", ssid)
wifi.radio.connect(ssid, password)
print(f"Connected to {ssid}!")
print("My IP address is", wifi.radio.ipv4_address)
ipv4 = ipaddress.ip_address("8.8.4.4")
print("Ping google.com:", wifi.radio.ping(ipv4), "ms")
pool = socketpool.SocketPool(wifi.radio)
requests = adafruit_requests.Session(pool, ssl.create_default_context())
print("Fetching text from", TIME_URL)
response = requests.get(TIME_URL)
print("-" * 40)
print(response.text)
print("-" * 40)
After running this, you will see something like the below text. We have blocked out the part with the secret username and key data!

Note at the end you will get the date, time, and your timezone! If so, you have correctly configured your settings.toml and can continue to the next steps!
Page last edited August 04, 2025
Text editor powered by tinymce.
MagTag-Specific CircuitPython Libraries
To use all the amazing features of your MagTag with CircuitPython, you must first install a number of libraries. This page covers that process.
Get Latest Adafruit CircuitPython Bundle
Download the Adafruit CircuitPython Library Bundle. You can find the latest release here:
Download the adafruit-circuitpython-bundle-version-mpy-*.zip bundle zip file, and unzip a folder of the same name. Inside you'll find a lib folder. The entire collection of libraries is too large to fit on the CIRCUITPY drive. Therefore, you'll need to copy the necessary libraries to your board individually.
At a minimum, the following libraries are required. Copy the following folders or .mpy files to the lib folder on your CIRCUITPY drive. If the library is a folder, copy the entire folder to the lib folder on your board.
Library folders (copy the whole folder over to lib):
- adafruit_magtag - This is a helper library designed for using all of the features of the MagTag, including networking, buttons, NeoPixels, etc.
- adafruit_portalbase - This library is the base library that adafruit_magtag is built on top of.
- adafruit_bitmap_font - There is fancy font support, and it's easy to make new fonts. This library reads and parses font files.
- adafruit_display_text - This library displays text on the screen.
- adafruit_io - This library helps connect the MagTag to our free data logging and viewing service
- adafruit_minimqtt - This library provides MQTT service for Adafruit IO.
Library files:
- adafruit_requests.mpy - This library allows us to perform HTTP requests and get responses back from servers. GET/POST/PUT/PATCH - they're all in here!
- adafruit_fakerequests.mpy - This library allows you to create fake HTTP requests by using local files.
- adafruit_miniqr.mpy - QR creation library lets us add easy-to-scan 2D barcodes to the E-Ink display
- neopixel.mpy - This library is used to control the onboard NeoPixels.
- simpleio.mpy - This library is used for tone generation.
settings.toml
Even if you aren't planning to go online with your MagTag, you'll need to have a settings.toml file in the root directory (top level) of your CIRCUITPY drive. If you do not intend to connect to wireless, it does not need to have valid data in it. See the previous page on creating a settings.toml file.
Page last edited August 04, 2025
Text editor powered by tinymce.
Welcome To CircuitPython

So, you've got a new CircuitPython compatible board. You plugged it in. Maybe it showed up as a disk drive called CIRCUITPY. Maybe it didn't! Either way, you need to know where to go from here. Well, this guide has you covered!
This guide will get you started with CircuitPython!
There are many amazing things about your new board. One of them is the ability to run CircuitPython. You may have seen that name on the Adafruit site somewhere. Not sure what it is? This guide can help!
"But I've never coded in my life. There's no way I do it!" You absolutely can! CircuitPython is designed to help you learn from the ground up. If you're new to everything, this is the place to start!
This guide will walk you through how to get started with CircuitPython. You'll learn how to install CircuitPython, get updated to the newest version of CircuitPython, setup a serial connection, and edit your code. You'll learn some basics of how CircuitPython works, and about the CircuitPython libraries. You'll also find a list of frequently asked questions, and a series of troubleshooting steps if you run into any issues.
Welcome to CircuitPython!
Page last edited August 04, 2025
Text editor powered by tinymce.
Installing the Mu Editor
Mu is a simple code editor that works with the Adafruit CircuitPython boards. It's written in Python and works on Windows, MacOS, Linux and Raspberry Pi. The serial console is built right in so you get immediate feedback from your board's serial output!
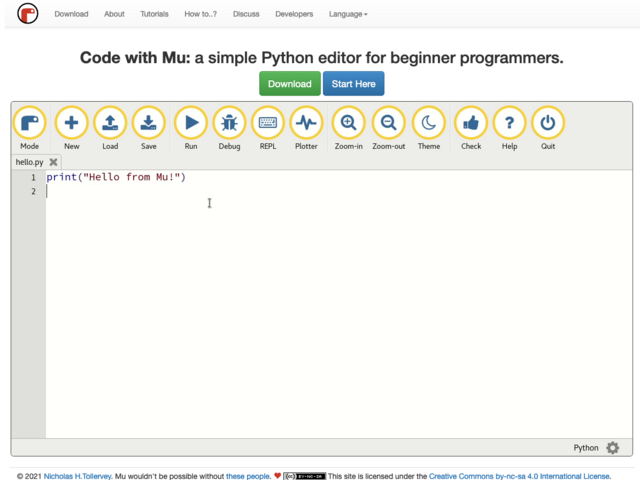
Download Mu from https://codewith.mu.
Click the Download link for downloads and installation instructions.
Click Start Here to find a wealth of other information, including extensive tutorials and and how-to's.

The first time you start Mu, you will be prompted to select your 'mode' - you can always change your mind later. For now please select CircuitPython!
The current mode is displayed in the lower right corner of the window, next to the "gear" icon. If the mode says "Microbit" or something else, click the Mode button in the upper left, and then choose "CircuitPython" in the dialog box that appears.

Mu attempts to auto-detect your board on startup, so if you do not have a CircuitPython board plugged in with a CIRCUITPY drive available, Mu will inform you where it will store any code you save until you plug in a board.
To avoid this warning, plug in a board and ensure that the CIRCUITPY drive is mounted before starting Mu.
Using Mu
You can now explore Mu! The three main sections of the window are labeled below; the button bar, the text editor, and the serial console / REPL.

Now you're ready to code! Let's keep going...
Page last edited August 04, 2025
Text editor powered by tinymce.
Creating and Editing Code
One of the best things about CircuitPython is how simple it is to get code up and running. This section covers how to create and edit your first CircuitPython program.
To create and edit code, all you'll need is an editor. There are many options. Adafruit strongly recommends using Mu! It's designed for CircuitPython, and it's really simple and easy to use, with a built in serial console!
If you don't or can't use Mu, there are a number of other editors that work quite well. The Recommended Editors page has more details. Otherwise, make sure you do "Eject" or "Safe Remove" on Windows or "sync" on Linux after writing a file if you aren't using Mu. (This was formerly not a problem on macOS, but see the warning below.)

Installing CircuitPython generates a code.py file on your CIRCUITPY drive. To begin your own program, open your editor, and load the code.py file from the CIRCUITPY drive.
If you are using Mu, click the Load button in the button bar, navigate to the CIRCUITPY drive, and choose code.py.
Copy and paste the following code into your editor:
import board
import digitalio
import time

led = digitalio.DigitalInOut(board.LED)
led.direction = digitalio.Direction.OUTPUT

while True:
    led.value = True
    time.sleep(0.5)
    led.value = False
    time.sleep(0.5)
If you're using a KB2040, QT Py, Quaila, or a Trinkey, or any other board without a single-color LED that can blink, please download the NeoPixel blink example.

It will look like this. Note that under the while True: line, the next four lines begin with four spaces to indent them, and they're indented exactly the same amount. All the lines before that have no spaces before the text.

The little LED should now be blinking. Once per half-second.
Congratulations, you've just run your first CircuitPython program!

To edit code, open the code.py file on your CIRCUITPY drive into your editor.
Make the desired changes to your code. Save the file. That's it!
Your code changes are run as soon as the file is done saving.
There's one warning before you continue...
The CircuitPython code on your board detects when the files are changed or written and will automatically re-start your code. This makes coding very fast because you save, and it re-runs. If you unplug or reset the board before your computer finishes writing the file to your board, you can corrupt the drive. If this happens, you may lose the code you've written, so it's important to backup your code to your computer regularly.
There are a couple of ways to avoid filesystem corruption.
1. Use an editor that writes out the file completely when you save it.
Check out the Recommended Editors page for details on different editing options.
2. Eject or Sync the Drive After Writing
If you are using one of our not-recommended-editors, not all is lost! You can still make it work.
On Windows, you can Eject or Safe Remove the CIRCUITPY drive. It won't actually eject, but it will force the operating system to save your file to disk. On Linux, use the sync command in a terminal to force the write to disk.
You also need to do this if you use Windows Explorer or a Linux graphical file manager to drag a file onto CIRCUITPY.
Don't worry! Corrupting the drive isn't the end of the world (or your board!). If this happens, follow the steps found on the Troubleshooting page of every board guide to get your board up and running again.
import supervisor
supervisor.runtime.autoreload = False
Back to Editing Code...
Now! Let's try editing the program you added to your board. Open your code.py file into your editor. You'll make a simple change. Change the first 0.5 to 0.1. The code should look like this:
import board
import digitalio
import time
led = digitalio.DigitalInOut(board.LED)
led.direction = digitalio.Direction.OUTPUT
while True:
led.value = True
time.sleep(0.1)
led.value = False
time.sleep(0.5)
Leave the rest of the code as-is. Save your file. See what happens to the LED on your board? Something changed! Do you know why?
You don't have to stop there! Let's keep going. Change the second 0.5 to 0.1 so it looks like this:
while True:
led.value = True
time.sleep(0.1)
led.value = False
time.sleep(0.1)
Now it blinks really fast! You decreased the both time that the code leaves the LED on and off!
Now try increasing both of the 0.1 to 1. Your LED will blink much more slowly because you've increased the amount of time that the LED is turned on and off.
Well done! You're doing great! You're ready to start into new examples and edit them to see what happens! These were simple changes, but major changes are done using the same process. Make your desired change, save it, and get the results. That's really all there is to it!
CircuitPython looks for a code file on the board to run. There are four options: code.txt, code.py, main.txt and main.py. CircuitPython looks for those files, in that order, and then runs the first one it finds. While code.py is the recommended name for your code file, it is important to know that the other options exist. If your program doesn't seem to be updating as you work, make sure you haven't created another code file that's being read instead of the one you're working on.
Page last edited August 04, 2025
Text editor powered by tinymce.
Connecting to the Serial Console
One of the staples of CircuitPython (and programming in general!) is something called a "print statement". This is a line you include in your code that causes your code to output text. A print statement in CircuitPython (and Python) looks like this:
print("Hello, world!")
This line in your code.py would result in:
Hello, world!
However, these print statements need somewhere to display. That's where the serial console comes in!
The serial console receives output from your CircuitPython board sent over USB and displays it so you can see it. This is necessary when you've included a print statement in your code and you'd like to see what you printed. It is also helpful for troubleshooting errors, because your board will send errors and the serial console will display those too.
The serial console requires an editor that has a built in terminal, or a separate terminal program. A terminal is a program that gives you a text-based interface to perform various tasks.
Are you using Mu?
If so, good news! The serial console is built into Mu and will autodetect your board making using the serial console really really easy.

First, make sure your CircuitPython board is plugged in.
If you open Mu without a board plugged in, you may encounter the error seen here, letting you know no CircuitPython board was found and indicating where your code will be stored until you plug in a board.
If you are using Windows 7, make sure you installed the drivers.
Once you've opened Mu with your board plugged in, look for the Serial button in the button bar and click it.

The Mu window will split in two, horizontally, and display the serial console at the bottom.

Serial Console Issues or Delays on Linux
If you're on Linux, and are seeing multi-second delays connecting to the serial console, or are seeing "AT" and other gibberish when you connect, then the modemmanager service might be interfering. Just remove it; it doesn't have much use unless you're still using dial-up modems.
To remove modemmanager, type the following command at a shell:
sudo apt purge modemmanager
Setting Permissions on Linux
On Linux, if you see an error box something like the one below when you press the Serial button, you need to add yourself to a user group to have permission to connect to the serial console.

On Ubuntu and Debian, add yourself to the dialout group by doing:
sudo adduser $USER dialout
After running the command above, reboot your machine to gain access to the group. On other Linux distributions, the group you need may be different. See the Advanced Serial Console on Linux for details on how to add yourself to the right group.
Using Something Else?
If you're not using Mu to edit, or if for some reason you are not a fan of its built in serial console, you can run the serial console from a separate program.
Windows requires you to download a terminal program. Check out the Advanced Serial Console on Windows page for more details.
MacOS has serial connection programs you can run in Terminal. Check the Advanced Serial Console on Mac page for more details.
Linux has multiple terminal programs included options are available for download. Check the Advanced Serial Console on Linux page for more details.
Once connected, you'll see something like the following.

Page last edited August 04, 2025
Text editor powered by tinymce.
Interacting with the Serial Console
Once you've successfully connected to the serial console, it's time to start using it.
The code you wrote earlier has no output to the serial console. So, you're going to edit it to create some output.
Open your code.py file into your editor, and include a print statement. You can print anything you like! Just include your phrase between the quotation marks inside the parentheses. For example:
import board
import digitalio
import time
led = digitalio.DigitalInOut(board.LED)
led.direction = digitalio.Direction.OUTPUT
while True:
print("Hello, CircuitPython!")
led.value = True
time.sleep(1)
led.value = False
time.sleep(1)
Save your file.
Now, let's go take a look at the window with our connection to the serial console.

Excellent! Our print statement is showing up in our console! Try changing the printed text to something else.
import board
import digitalio
import time
led = digitalio.DigitalInOut(board.LED)
led.direction = digitalio.Direction.OUTPUT
while True:
print("Hello back to you!")
led.value = True
time.sleep(1)
led.value = False
time.sleep(1)
Keep your serial console window where you can see it. Save your file. You'll see what the serial console displays when the board reboots. Then you'll see your new change!

The Traceback (most recent call last): is telling you the last thing your board was doing before you saved your file. This is normal behavior and will happen every time the board resets. This is really handy for troubleshooting. Let's introduce an error so you can see how it is used.
Delete the e at the end of True from the line led.value = True so that it says led.value = Tru
import board
import digitalio
import time
led = digitalio.DigitalInOut(board.LED)
led.direction = digitalio.Direction.OUTPUT
while True:
print("Hello back to you!")
led.value = Tru
time.sleep(1)
led.value = False
time.sleep(1)
Save your file. You will notice that your red LED will stop blinking, and you may have a colored status LED blinking at you. This is because the code is no longer correct and can no longer run properly. You need to fix it!
Usually when you run into errors, it's not because you introduced them on purpose. You may have 200 lines of code, and have no idea where your error could be hiding. This is where the serial console can help. Let's take a look!

The Traceback (most recent call last): is telling you that the last thing it was able to run was line 10 in your code. The next line is your error: NameError: name 'Tru' is not defined. This error might not mean a lot to you, but combined with knowing the issue is on line 10, it gives you a great place to start!
Go back to your code, and take a look at line 10. Obviously, you know what the problem is already. But if you didn't, you'd want to look at line 10 and see if you could figure it out. If you're still unsure, try googling the error to get some help. In this case, you know what to look for. You spelled True wrong. Fix the typo and save your file.

Nice job fixing the error! Your serial console is streaming and your red LED Is blinking again.
The serial console will display any output generated by your code. Some sensors, such as a humidity sensor or a thermistor, receive data and you can use print statements to display that information. You can also use print statements for troubleshooting, which is called "print debugging". Essentially, if your code isn't working, and you want to know where it's failing, you can put print statements in various places to see where it stops printing.
The serial console has many uses, and is an amazing tool overall for learning and programming!
Page last edited August 04, 2025
Text editor powered by tinymce.
The REPL
The other feature of the serial connection is the Read-Evaluate-Print-Loop, or REPL. The REPL allows you to enter individual lines of code and have them run immediately. It's really handy if you're running into trouble with a particular program and can't figure out why. It's interactive so it's great for testing new ideas.
Entering the REPL
To use the REPL, you first need to be connected to the serial console. Once that connection has been established, you'll want to press CTRL+C.
If there is code running, in this case code measuring distance, it will stop and you'll see Press any key to enter the REPL. Use CTRL-D to reload. Follow those instructions, and press any key on your keyboard.
The Traceback (most recent call last): is telling you the last thing your board was doing before you pressed Ctrl + C and interrupted it. The KeyboardInterrupt is you pressing CTRL+C. This information can be handy when troubleshooting, but for now, don't worry about it. Just note that it is expected behavior.

If your code.py file is empty or does not contain a loop, it will show an empty output and Code done running.. There is no information about what your board was doing before you interrupted it because there is no code running.

If you have no code.py on your CIRCUITPY drive, you will enter the REPL immediately after pressing CTRL+C. Again, there is no information about what your board was doing before you interrupted it because there is no code running.

Regardless, once you press a key you'll see a >>> prompt welcoming you to the REPL!

If you have trouble getting to the >>> prompt, try pressing Ctrl + C a few more times.
The first thing you get from the REPL is information about your board.

This line tells you the version of CircuitPython you're using and when it was released. Next, it gives you the type of board you're using and the type of microcontroller the board uses. Each part of this may be different for your board depending on the versions you're working with.
This is followed by the CircuitPython prompt.

Interacting with the REPL
From this prompt you can run all sorts of commands and code. The first thing you'll do is run help(). This will tell you where to start exploring the REPL. To run code in the REPL, type it in next to the REPL prompt.
Type help() next to the prompt in the REPL.

Then press enter. You should then see a message.

First part of the message is another reference to the version of CircuitPython you're using. Second, a URL for the CircuitPython related project guides. Then... wait. What's this? To list built-in modules type help("modules"). Remember the modules you learned about while going through creating code? That's exactly what this is talking about! This is a perfect place to start. Let's take a look!
Type help("modules") into the REPL next to the prompt, and press enter.

This is a list of all the core modules built into CircuitPython, including board. Remember, board contains all of the pins on the board that you can use in your code. From the REPL, you are able to see that list!
Type import board into the REPL and press enter. It'll go to a new prompt. It might look like nothing happened, but that's not the case! If you recall, the import statement simply tells the code to expect to do something with that module. In this case, it's telling the REPL that you plan to do something with that module.

Next, type dir(board) into the REPL and press enter.

This is a list of all of the pins on your board that are available for you to use in your code. Each board's list will differ slightly depending on the number of pins available. Do you see LED? That's the pin you used to blink the red LED!
The REPL can also be used to run code. Be aware that any code you enter into the REPL isn't saved anywhere. If you're testing something new that you'd like to keep, make sure you have it saved somewhere on your computer as well!
Every programmer in every programming language starts with a piece of code that says, "Hello, World." You're going to say hello to something else. Type into the REPL:
print("Hello, CircuitPython!")
Then press enter.

That's all there is to running code in the REPL! Nice job!
You can write single lines of code that run stand-alone. You can also write entire programs into the REPL to test them. Remember that nothing typed into the REPL is saved.
There's a lot the REPL can do for you. It's great for testing new ideas if you want to see if a few new lines of code will work. It's fantastic for troubleshooting code by entering it one line at a time and finding out where it fails. It lets you see what modules are available and explore those modules.
Try typing more into the REPL to see what happens!
Returning to the Serial Console
When you're ready to leave the REPL and return to the serial console, simply press CTRL+D. This will reload your board and reenter the serial console. You will restart the program you had running before entering the REPL. In the console window, you'll see any output from the program you had running. And if your program was affecting anything visual on the board, you'll see that start up again as well.
You can return to the REPL at any time!

Page last edited August 04, 2025
Text editor powered by tinymce.
Advanced Serial Console on Windows
What's the COM?
First, you'll want to find out which serial port your board is using. When you plug your board in to USB on your computer, it connects to a serial port. The port is like a door through which your board can communicate with your computer using USB.
You'll use Windows Device Manager to determine which port the board is using. The easiest way to determine which port the board is using is to first check without the board plugged in. Open Device Manager. Click on Ports (COM & LPT). You should find something already in that list with (COM#) after it where # is a number.

Now plug in your board. The Device Manager list will refresh and a new item will appear under Ports (COM & LPT). You'll find a different (COM#) after this item in the list.

Sometimes the item will refer to the name of the board. Other times it may be called something like USB Serial Device, as seen in the image above. Either way, there is a new (COM#) following the name. This is the port your board is using.
Windows Serial Port Terminal Programs
- Putty is a venerable serial port connection program. More details are below.
- Tera Term is a nice terminal program. It will reconnect automatically after disconnections
- VSCode has a number of serial port extensions, such as Serial Monitor.
- PyCharm has a Serial Port Monitor plugin.
Install Putty
PuTTY is a well-known choice for connecting to serial ports on Windows.
The first thing to do is download the latest version of PuTTY. You'll want to download the Windows installer file. It is most likely that you'll need the 64-bit version. Download the file and install the program on your machine. If you run into issues, you can try downloading the 32-bit version instead. However, the 64-bit version will work on most PCs.
Now you need to open PuTTY.
- Under Connection type: choose the button next to Serial.
- In the box under Serial line, enter the serial port you found that your board is using.
- In the box under Speed, enter 115200. This called the baud rate, which is the speed in bits per second that data is sent over the serial connection. For boards with built in USB it doesn't matter so much but for ESP8266 and other board with a separate chip, the speed required by the board is 115200 bits per second. So you might as well just use 115200!
If you want to save those settings for later, use the options under Load, save or delete a stored session. Enter a name in the box under Saved Sessions, and click the Save button on the right.

Once your settings are entered, you're ready to connect to the serial console. Click "Open" at the bottom of the window. A new window will open.

If no code is running, the window will either be blank or will look like the window above. Now you're ready to see the results of your code.
Great job! You've connected to the serial console!
Windows 7 and 8.1
If you're using Windows 7 (or 8 or 8.1), you'll need to install drivers. See the Windows 7 and 8.1 Drivers page for details. You will not need to install drivers on Mac, Linux or Windows 10 or 11.
Page last edited August 04, 2025
Text editor powered by tinymce.
CircuitPython Libraries
Each CircuitPython program you run needs to have a lot of information to work. The reason CircuitPython is so simple to use is that most of that information is stored in other files and works in the background. These files are called libraries. Some of them are built into CircuitPython. Others are stored on your CIRCUITPY drive in a folder called lib. Part of what makes CircuitPython so great is its ability to store code separately from the firmware itself. Storing code separately from the firmware makes it easier to update both the code you write and the libraries you depend.
Your board may ship with a lib folder already, it's in the base directory of the drive. If not, simply create the folder yourself. When you first install CircuitPython, an empty lib directory will be created for you.

CircuitPython libraries work in the same way as regular Python modules so the Python docs are an excellent reference for how it all should work. In Python terms, you can place our library files in the lib directory because it's part of the Python path by default.
One downside of this approach of separate libraries is that they are not built in. To use them, one needs to copy them to the CIRCUITPY drive before they can be used. Fortunately, there is a library bundle.
The bundle and the library releases on GitHub also feature optimized versions of the libraries with the .mpy file extension. These files take less space on the drive and have a smaller memory footprint as they are loaded.
Due to the regular updates and space constraints, Adafruit does not ship boards with the entire bundle. Therefore, you will need to load the libraries you need when you begin working with your board. You can find example code in the guides for your board that depends on external libraries.
Either way, as you start to explore CircuitPython, you'll want to know how to get libraries on board.
The Adafruit Learn Guide Project Bundle
The quickest and easiest way to get going with a project from the Adafruit Learn System is by utilising the Project Bundle. Most guides now have a Download Project Bundle button available at the top of the full code example embed. This button downloads all the necessary files, including images, etc., to get the guide project up and running. Simply click, open the resulting zip, copy over the right files, and you're good to go!
The first step is to find the Download Project Bundle button in the guide you're working on.

The Download Project Bundle button downloads a zip file. This zip contains a series of directories, nested within which is the code.py, any applicable assets like images or audio, and the lib/ folder containing all the necessary libraries. The following zip was downloaded from the Piano in the Key of Lime guide.

When you open the zip, you'll find some nested directories. Navigate through them until you find what you need. You'll eventually find a directory for your CircuitPython version (in this case, 7.x). In the version directory, you'll find the file and directory you need: code.py and lib/. Once you find the content you need, you can copy it all over to your CIRCUITPY drive, replacing any files already on the drive with the files from the freshly downloaded zip.
Once you copy over all the relevant files, the project should begin running! If you find that the project is not running as expected, make sure you've copied ALL of the project files onto your microcontroller board.
That's all there is to using the Project Bundle!
The Adafruit CircuitPython Library Bundle
Adafruit provides CircuitPython libraries for much of the hardware they provide, including sensors, breakouts and more. To eliminate the need for searching for each library individually, the libraries are available together in the Adafruit CircuitPython Library Bundle. The bundle contains all the files needed to use each library.
Downloading the Adafruit CircuitPython Library Bundle
You can download the latest Adafruit CircuitPython Library Bundle release by clicking the button below. The libraries are being constantly updated and improved, so you'll always want to download the latest bundle.
Match up the bundle version with the version of CircuitPython you are running. For example, you would download the 6.x library bundle if you're running any version of CircuitPython 6, or the 7.x library bundle if you're running any version of CircuitPython 7, etc. If you mix libraries with major CircuitPython versions, you will get incompatible mpy errors due to changes in library interfaces possible during major version changes.
Download the bundle version that matches your CircuitPython firmware version. If you don't know the version, check the version info in boot_out.txt file on the CIRCUITPY drive, or the initial prompt in the CircuitPython REPL. For example, if you're running v7.0.0, download the 7.x library bundle.
There's also a py bundle which contains the uncompressed python files, you probably don't want that unless you are doing advanced work on libraries.
The CircuitPython Community Library Bundle
The CircuitPython Community Library Bundle is made up of libraries written and provided by members of the CircuitPython community. These libraries are often written when community members encountered hardware not supported in the Adafruit Bundle, or to support a personal project. The authors all chose to submit these libraries to the Community Bundle make them available to the community.
These libraries are maintained by their authors and are not supported by Adafruit. As you would with any library, if you run into problems, feel free to file an issue on the GitHub repo for the library. Bear in mind, though, that most of these libraries are supported by a single person and you should be patient about receiving a response. Remember, these folks are not paid by Adafruit, and are volunteering their personal time when possible to provide support.
Downloading the CircuitPython Community Library Bundle
You can download the latest CircuitPython Community Library Bundle release by clicking the button below. The libraries are being constantly updated and improved, so you'll always want to download the latest bundle.
The link takes you to the latest release of the CircuitPython Community Library Bundle on GitHub. There are multiple versions of the bundle available. Download the bundle version that matches your CircuitPython firmware version. If you don't know the version, check the version info in boot_out.txt file on the CIRCUITPY drive, or the initial prompt in the CircuitPython REPL. For example, if you're running v7.0.0, download the 7.x library bundle.
Understanding the Bundle
After downloading the zip, extract its contents. This is usually done by double clicking on the zip. On Mac OSX, it places the file in the same directory as the zip.

Open the bundle folder. Inside you'll find two information files, and two folders. One folder is the lib bundle, and the other folder is the examples bundle.

Now open the lib folder. When you open the folder, you'll see a large number of .mpy files, and folders.

Example Files
All example files from each library are now included in the bundles in an examples directory (as seen above), as well as an examples-only bundle. These are included for two main reasons:
- Allow for quick testing of devices.
- Provide an example base of code, that is easily built upon for individualized purposes.

Copying Libraries to Your Board
First open the lib folder on your CIRCUITPY drive. Then, open the lib folder you extracted from the downloaded zip. Inside you'll find a number of folders and .mpy files. Find the library you'd like to use, and copy it to the lib folder on CIRCUITPY.
If the library is a directory with multiple .mpy files in it, be sure to copy the entire folder to CIRCUITPY/lib.
This also applies to example files. Open the examples folder you extracted from the downloaded zip, and copy the applicable file to your CIRCUITPY drive. Then, rename it to code.py to run it.
Understanding Which Libraries to Install
You now know how to load libraries on to your CircuitPython-compatible microcontroller board. You may now be wondering, how do you know which libraries you need to install? Unfortunately, it's not always straightforward. Fortunately, there is an obvious place to start, and a relatively simple way to figure out the rest. First up: the best place to start.
When you look at most CircuitPython examples, you'll see they begin with one or more import statements. These typically look like the following:
import library_or_module
However, import statements can also sometimes look like the following:
from library_or_module import namefrom library_or_module.subpackage import namefrom library_or_module import name as local_name
They can also have more complicated formats, such as including a try / except block, etc.
The important thing to know is that an import statement will always include the name of the module or library that you're importing.
Therefore, the best place to start is by reading through the import statements.
Here is an example import list for you to work with in this section. There is no setup or other code shown here, as the purpose of this section involves only the import list.
import time import board import neopixel import adafruit_lis3dh import usb_hid from adafruit_hid.consumer_control import ConsumerControl from adafruit_hid.consumer_control_code import ConsumerControlCode
Keep in mind, not all imported items are libraries. Some of them are almost always built-in CircuitPython modules. How do you know the difference? Time to visit the REPL.
In the Interacting with the REPL section on The REPL page in this guide, the help("modules") command is discussed. This command provides a list of all of the built-in modules available in CircuitPython for your board. So, if you connect to the serial console on your board, and enter the REPL, you can run help("modules") to see what modules are available for your board. Then, as you read through the import statements, you can, for the purposes of figuring out which libraries to load, ignore the statement that import modules.
The following is the list of modules built into CircuitPython for the Feather RP2040. Your list may look similar or be anything down to a significant subset of this list for smaller boards.

Now that you know what you're looking for, it's time to read through the import statements. The first two, time and board, are on the modules list above, so they're built-in.
The next one, neopixel, is not on the module list. That means it's your first library! So, you would head over to the bundle zip you downloaded, and search for neopixel. There is a neopixel.mpy file in the bundle zip. Copy it over to the lib folder on your CIRCUITPY drive. The following one, adafruit_lis3dh, is also not on the module list. Follow the same process for adafruit_lis3dh, where you'll find adafruit_lis3dh.mpy, and copy that over.
The fifth one is usb_hid, and it is in the modules list, so it is built in. Often all of the built-in modules come first in the import list, but sometimes they don't! Don't assume that everything after the first library is also a library, and verify each import with the modules list to be sure. Otherwise, you'll search the bundle and come up empty!
The final two imports are not as clear. Remember, when import statements are formatted like this, the first thing after the from is the library name. In this case, the library name is adafruit_hid. A search of the bundle will find an adafruit_hid folder. When a library is a folder, you must copy the entire folder and its contents as it is in the bundle to the lib folder on your CIRCUITPY drive. In this case, you would copy the entire adafruit_hid folder to your CIRCUITPY/lib folder.
Notice that there are two imports that begin with adafruit_hid. Sometimes you will need to import more than one thing from the same library. Regardless of how many times you import the same library, you only need to load the library by copying over the adafruit_hid folder once.
That is how you can use your example code to figure out what libraries to load on your CircuitPython-compatible board!
There are cases, however, where libraries require other libraries internally. The internally required library is called a dependency. In the event of library dependencies, the easiest way to figure out what other libraries are required is to connect to the serial console and follow along with the ImportError printed there. The following is a very simple example of an ImportError, but the concept is the same for any missing library.
Example: ImportError Due to Missing Library
If you choose to load libraries as you need them, or you're starting fresh with an existing example, you may end up with code that tries to use a library you haven't yet loaded. This section will demonstrate what happens when you try to utilise a library that you don't have loaded on your board, and cover the steps required to resolve the issue.
This demonstration will only return an error if you do not have the required library loaded into the lib folder on your CIRCUITPY drive.
Let's use a modified version of the Blink example.
import board
import time
import simpleio
led = simpleio.DigitalOut(board.LED)
while True:
led.value = True
time.sleep(0.5)
led.value = False
time.sleep(0.5)
Save this file. Nothing happens to your board. Let's check the serial console to see what's going on.

You have an ImportError. It says there is no module named 'simpleio'. That's the one you just included in your code!
Click the link above to download the correct bundle. Extract the lib folder from the downloaded bundle file. Scroll down to find simpleio.mpy. This is the library file you're looking for! Follow the steps above to load an individual library file.
The LED starts blinking again! Let's check the serial console.

No errors! Excellent. You've successfully resolved an ImportError!
If you run into this error in the future, follow along with the steps above and choose the library that matches the one you're missing.
Library Install on Non-Express Boards
If you have an M0 non-Express board such as Trinket M0, Gemma M0, QT Py M0, or one of the M0 Trinkeys, you'll want to follow the same steps in the example above to install libraries as you need them. Remember, you don't need to wait for an ImportError if you know what library you added to your code. Open the library bundle you downloaded, find the library you need, and drag it to the lib folder on your CIRCUITPY drive.
You can still end up running out of space on your M0 non-Express board even if you only load libraries as you need them. There are a number of steps you can use to try to resolve this issue. You'll find suggestions on the Troubleshooting page.
Updating CircuitPython Libraries and Examples
Libraries and examples are updated from time to time, and it's important to update the files you have on your CIRCUITPY drive.
To update a single library or example, follow the same steps above. When you drag the library file to your lib folder, it will ask if you want to replace it. Say yes. That's it!
A new library bundle is released every time there's an update to a library. Updates include things like bug fixes and new features. It's important to check in every so often to see if the libraries you're using have been updated.
CircUp CLI Tool
There is a command line interface (CLI) utility called CircUp that can be used to easily install and update libraries on your device. Follow the directions on the install page within the CircUp learn guide. Once you've got it installed you run the command circup update in a terminal to interactively update all libraries on the connected CircuitPython device. See the usage page in the CircUp guide for a full list of functionality
Page last edited August 04, 2025
Text editor powered by tinymce.
CircuitPython Pins and Modules
CircuitPython is designed to run on microcontrollers and allows you to interface with all kinds of sensors, inputs and other hardware peripherals. There are tons of guides showing how to wire up a circuit, and use CircuitPython to, for example, read data from a sensor, or detect a button press. Most CircuitPython code includes hardware setup which requires various modules, such as board or digitalio. You import these modules and then use them in your code. How does CircuitPython know to look for hardware in the specific place you connected it, and where do these modules come from?
This page explains both. You'll learn how CircuitPython finds the pins on your microcontroller board, including how to find the available pins for your board and what each pin is named. You'll also learn about the modules built into CircuitPython, including how to find all the modules available for your board.
CircuitPython Pins
When using hardware peripherals with a CircuitPython compatible microcontroller, you'll almost certainly be utilising pins. This section will cover how to access your board's pins using CircuitPython, how to discover what pins and board-specific objects are available in CircuitPython for your board, how to use the board-specific objects, and how to determine all available pin names for a given pin on your board.
import board
When you're using any kind of hardware peripherals wired up to your microcontroller board, the import list in your code will include import board. The board module is built into CircuitPython, and is used to provide access to a series of board-specific objects, including pins. Take a look at your microcontroller board. You'll notice that next to the pins are pin labels. You can always access a pin by its pin label. However, there are almost always multiple names for a given pin.
To see all the available board-specific objects and pins for your board, enter the REPL (>>>) and run the following commands:
import board dir(board)
Here is the output for the QT Py SAMD21. You may have a different board, and this list will vary, based on the board.

The following pins have labels on the physical QT Py SAMD21 board: A0, A1, A2, A3, SDA, SCL, TX, RX, SCK, MISO, and MOSI. You see that there are many more entries available in board than the labels on the QT Py.
You can use the pin names on the physical board, regardless of whether they seem to be specific to a certain protocol.
For example, you do not have to use the SDA pin for I2C - you can use it for a button or LED.
On the flip side, there may be multiple names for one pin. For example, on the QT Py SAMD21, pin A0 is labeled on the physical board silkscreen, but it is available in CircuitPython as both A0 and D0. For more information on finding all the names for a given pin, see the What Are All the Available Pin Names? section below.
The results of dir(board) for CircuitPython compatible boards will look similar to the results for the QT Py SAMD21 in terms of the pin names, e.g. A0, D0, etc. However, some boards, for example, the Metro ESP32-S2, have different styled pin names. Here is the output for the Metro ESP32-S2.

Note that most of the pins are named in an IO# style, such as IO1 and IO2. Those pins on the physical board are labeled only with a number, so an easy way to know how to access them in CircuitPython, is to run those commands in the REPL and find the pin naming scheme.
I2C, SPI, and UART
You'll also see there are often (but not always!) three special board-specific objects included: I2C, SPI, and UART - each one is for the default pin-set used for each of the three common protocol busses they are named for. These are called singletons.
What's a singleton? When you create an object in CircuitPython, you are instantiating ('creating') it. Instantiating an object means you are creating an instance of the object with the unique values that are provided, or "passed", to it.
For example, When you instantiate an I2C object using the busio module, it expects two pins: clock and data, typically SCL and SDA. It often looks like this:
i2c = busio.I2C(board.SCL, board.SDA)
Then, you pass the I2C object to a driver for the hardware you're using. For example, if you were using the TSL2591 light sensor and its CircuitPython library, the next line of code would be:
tsl2591 = adafruit_tsl2591.TSL2591(i2c)
However, CircuitPython makes this simpler by including the I2C singleton in the board module. Instead of the two lines of code above, you simply provide the singleton as the I2C object. So if you were using the TSL2591 and its CircuitPython library, the two above lines of code would be replaced with:
tsl2591 = adafruit_tsl2591.TSL2591(board.I2C())
This eliminates the need for the busio module, and simplifies the code. Behind the scenes, the board.I2C() object is instantiated when you call it, but not before, and on subsequent calls, it returns the same object. Basically, it does not create an object until you need it, and provides the same object every time you need it. You can call board.I2C() as many times as you like, and it will always return the same object.
What Are All the Available Names?
Many pins on CircuitPython compatible microcontroller boards have multiple names, however, typically, there's only one name labeled on the physical board. So how do you find out what the other available pin names are? Simple, with the following script! Each line printed out to the serial console contains the set of names for a particular pin.
On a microcontroller board running CircuitPython, first, connect to the serial console.
In the example below, click the Download Project Bundle button below to download the necessary libraries and the code.py file in a zip file. Extract the contents of the zip file, open the directory CircuitPython_Essentials/Pin_Map_Script/ and then click on the directory that matches the version of CircuitPython you're using and copy the contents of that directory to your CIRCUITPY drive.
Your CIRCUITPY
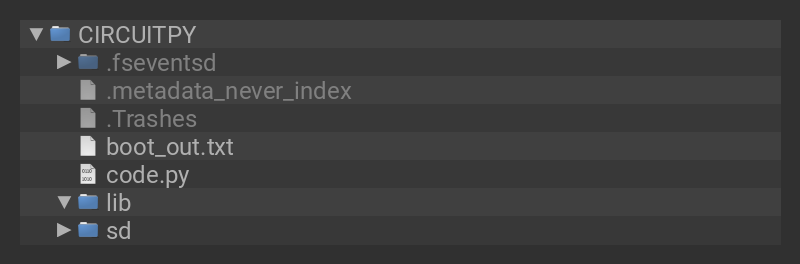
# SPDX-FileCopyrightText: 2020 anecdata for Adafruit Industries
# SPDX-FileCopyrightText: 2021 Neradoc for Adafruit Industries
# SPDX-FileCopyrightText: 2021-2023 Kattni Rembor for Adafruit Industries
# SPDX-FileCopyrightText: 2023 Dan Halbert for Adafruit Industries
#
# SPDX-License-Identifier: MIT
"""CircuitPython Essentials Pin Map Script"""
import microcontroller
import board
try:
import cyw43 # raspberrypi
except ImportError:
cyw43 = None
board_pins = []
for pin in dir(microcontroller.pin):
if (isinstance(getattr(microcontroller.pin, pin), microcontroller.Pin) or
(cyw43 and isinstance(getattr(microcontroller.pin, pin), cyw43.CywPin))):
pins = []
for alias in dir(board):
if getattr(board, alias) is getattr(microcontroller.pin, pin):
pins.append(f"board.{alias}")
# Add the original GPIO name, in parentheses.
if pins:
# Only include pins that are in board.
pins.append(f"({str(pin)})")
board_pins.append(" ".join(pins))
for pins in sorted(board_pins):
print(pins)
Here is the result when this script is run on QT Py SAMD21:

Each line represents a single pin. Find the line containing the pin name that's labeled on the physical board, and you'll find the other names available for that pin. For example, the first pin on the board is labeled A0. The first line in the output is board.A0 board.D0 (PA02). This means that you can access pin A0 in CircuitPython using both board.A0 and board.D0.
The pins in parentheses are the microcontroller pin names. See the next section for more info on those.
You'll notice there are two "pins" that aren't labeled on the board but appear in the list: board.NEOPIXEL and board.NEOPIXEL_POWER. Many boards have several of these special pins that give you access to built-in board hardware, such as an LED or an on-board sensor. The QT Py SAMD21 only has one on-board extra piece of hardware, a NeoPixel LED, so there's only the one available in the list. But you can also control whether or not power is applied to the NeoPixel, so there's a separate pin for that.
That's all there is to figuring out the available names for a pin on a compatible microcontroller board in CircuitPython!
Microcontroller Pin Names
The pin names available to you in the CircuitPython board module are not the same as the names of the pins on the microcontroller itself. The board pin names are aliases to the microcontroller pin names. If you look at the datasheet for your microcontroller, you'll likely find a pinout with a series of pin names, such as "PA18" or "GPIO5". If you want to get to the actual microcontroller pin name in CircuitPython, you'll need the microcontroller.pin module. As with board, you can run dir(microcontroller.pin) in the REPL to receive a list of the microcontroller pin names.

CircuitPython Built-In Modules
There is a set of modules used in most CircuitPython programs. One or more of these modules is always used in projects involving hardware. Often hardware requires installing a separate library from the Adafruit CircuitPython Bundle. But, if you try to find board or digitalio in the same bundle, you'll come up lacking. So, where do these modules come from? They're built into CircuitPython! You can find an comprehensive list of built-in CircuitPython modules and the technical details of their functionality from CircuitPython here and the Python-like modules included here. However, not every module is available for every board due to size constraints or hardware limitations. How do you find out what modules are available for your board?
There are two options for this. You can check the support matrix, and search for your board by name. Or, you can use the REPL.
Plug in your board, connect to the serial console and enter the REPL. Type the following command.
help("modules")

That's it! You now know two ways to find all of the modules built into CircuitPython for your compatible microcontroller board.
Page last edited August 04, 2025
Text editor powered by tinymce.
Advanced Serial Console on Mac
Connecting to the serial console on Mac does not require installing any drivers or extra software. You'll use a terminal program to find your board, and screen to connect to it. Terminal and screen both come installed by default.
What's the Port?
First you'll want to find out which serial port your board is using. When you plug your board in to USB on your computer, it connects to a serial port. The port is like a door through which your board can communicate with your computer using USB.
The easiest way to determine which port the board is using is to first check without the board plugged in. Open Terminal and type the following:
ls /dev/tty.*
Each serial connection shows up in the /dev/ directory. It has a name that starts with tty.. The command ls shows you a list of items in a directory. You can use * as a wildcard, to search for files that start with the same letters but end in something different. In this case, you're asking to see all of the listings in /dev/ that start with tty. and end in anything. This will show us the current serial connections.

Now, plug your board. In Terminal, type:
ls /dev/tty.*
This will show you the current serial connections, which will now include your board.

A new listing has appeared called /dev/tty.usbmodem141441. The tty.usbmodem141441 part of this listing is the name the example board is using. Yours will be called something similar.
screen terminal program can cause your CircuitPython program to hang when trying to print, if you exit screen after you've used it to connect.
macOS Serial Port Terminal Programs
-
screenis included with macOS. However, it's problematic because when it starts up, it enables the using DTR/RTS flow control signals and does not turn that off when it quits. This causes CircuitPython to block sending output whenscreenhas exited, which will cause your program to stall until it is reconnected. See this issue for a discussion. -
tiois a nice terminal program that works properly. You can install it with Homebrew. - VSCode has a number of serial port extensions, such as Serial Monitor.
- PyCharm has a Serial Port Monitor plugin.
Connect with screen
Despite the caveats above, if you can't download a better terminal program, you can use screen. The screen command is included with MacOS. To connect to the serial console, use Terminal. Type the following command, replacing board_name with the name you found your board is using:
screen /dev/tty.board_name 115200
The first part of this establishes using the screen command. The second part tells screen the name of the board you're trying to use. The third part tells screen what baud rate to use for the serial connection. The baud rate is the speed in bits per second that data is sent over the serial connection. In this case, the speed required by the board is 115200 bits per second.

Press enter to run the command. It will open in the same window. If no code is running, the window will be blank. Otherwise, you'll see the output of your code.
Great job! You've connected to the serial console!
Page last edited August 04, 2025
Text editor powered by tinymce.
Frequently Asked Questions
These are some of the common questions regarding CircuitPython and CircuitPython microcontrollers.
CP or CPy = CircuitPython
CPC = Circuit Playground Classic (does not run CircuitPython)
CPX = Circuit Playground Express
CPB = Circuit Playground Bluefruit
We are no longer building or supporting the CircuitPython 8.x or earlier library bundles. We highly encourage you to update CircuitPython to the latest version and use the current version of the libraries. However, if for some reason you cannot update, here are the last available library bundles for older versions:
All CircuitPython boards support floating point arithmetic, even if the microcontroller chip does not support floating point in hardware. Floating point numbers are stored in 30 bits, with an 8-bit exponent and a 22-bit mantissa. Note that this is two bits less than standard 32-bit single-precision floats. You will get about 5-1/2 digits of decimal precision.
(The broadcom port may provide 64-bit floats in some cases.)
Python long integers (integers of arbitrary size) are available on most builds, except those on boards with the smallest available firmware size. On these boards, integers are stored in 31 bits.
Boards without long integer support are mostly SAMD21 ("M0") boards without an external flash chip, such as the Adafruit Gemma M0, Trinket M0, QT Py M0, and the Trinkey series. There are also a number of third-party boards in this category. There are also a few small STM third-party boards without long integer support.
time.localtime(), time.mktime(), time.time(), and time.monotonic_ns() are available only on builds with long integers.
If you'd like to include WiFi in your project, your best bet is to use a board that is running natively on ESP32 chipsets - those have WiFi built in!
If your development board has an SPI port and at least 4 additional pins, you can check out this guide on using AirLift with CircuitPython - extra wiring is required and some boards like the MacroPad or NeoTrellis do not have enough available pins to add the hardware support.
For further project examples, and guides about using AirLift with specific hardware, check out the Adafruit Learn System.
nRF52840, nRF52833, and as of CircuitPython 9.1.0, ESP32, ESP32-C3, and ESP32-S3 boards (with 8MB) have the most complete BLE implementation. Your program can act as both a BLE central and peripheral. As a central, you can scan for advertisements, and connect to an advertising board. As a peripheral, you can advertise, and you can create services available to a central. Pairing and bonding are supported.
Most Espressif boards with only 4MB of flash do not have enough room to include BLE in CircuitPython 9. Check the Module Support Matrix to see if your board has support for _bleio. CircuitPython 10 is planned to support _bleio on Espressif boards with 4MB flash.
Note that the ESP32-S2 does not have Bluetooth capability.
On most other boards with adequate firmware space, BLE is available for use with AirLift or other NINA-FW-based co-processors. Some boards have this coprocessor on board, such as the PyPortal. Currently, this implementation only supports acting as a BLE peripheral. Scanning and connecting as a central are not yet implemented. Bonding and pairing are not supported.
Check out Adafruit's RFM boards for simple radio communication supported by CircuitPython, which can be used over distances of 100m to over a km, depending on the version. The RFM SAMD21 M0 boards can be used, but they were not designed for CircuitPython, and have limited RAM and flash space; using the RFM breakouts or FeatherWings with more capable boards will be easier.
There is support for asyncio starting with CircuitPython 7.1.0, on all boards except the smallest SAMD21 builds. Read about using it in the Cooperative Multitasking in CircuitPython Guide.
No. CircuitPython does not currently support interrupts - please use asyncio for multitasking / 'threaded' control of your code
The status LED can tell you what's going on with your CircuitPython board. Read more here for what the colors mean!
Memory allocation errors happen when you're trying to store too much on the board. The CircuitPython microcontroller boards have a limited amount of memory available. You can have about 250 lines of code on the M0 Express boards. If you try to import too many libraries, a combination of large libraries, or run a program with too many lines of code, your code will fail to run and you will receive a MemoryError in the serial console.
Try resetting your board. Each time you reset the board, it reallocates the memory. While this is unlikely to resolve your issue, it's a simple step and is worth trying.
Make sure you are using .mpy versions of libraries. All of the CircuitPython libraries are available in the bundle in a .mpy format which takes up less memory than .py format. Be sure that you're using the latest library bundle for your version of CircuitPython.
If that does not resolve your issue, try shortening your code. Shorten comments, remove extraneous or unneeded code, or any other clean up you can do to shorten your code. If you're using a lot of functions, you could try moving those into a separate library, creating a .mpy of that library, and importing it into your code.
You can turn your entire file into a .mpy and import that into code.py. This means you will be unable to edit your code live on the board, but it can save you space.
import statements affect memory?
It can because the memory gets fragmented differently depending on allocation order and the size of objects. Loading .mpy files uses less memory so its recommended to do that for files you aren't editing.
You can make your own .mpy versions of files with mpy-cross.
You can download mpy-cross for your operating system from here. Builds are available for Windows, macOS, x64 Linux, and Raspberry Pi Linux. Choose the latest mpy-cross whose version matches the version of CircuitPython you are using.
On macOS and Linux, after you download mpy-cross, you must make the the file executable by doing chmod +x name-of-the-mpy-cross-executable.
To make a .mpy file, run ./mpy-cross path/to/yourfile.py to create a yourfile.mpy in the same directory as the original file.
Run the following to see the number of bytes available for use:
import gcgc.mem_free()
We dropped ESP8266 support as of 4.x - For more information please read about it here!
We also support ESP32-S2 & ESP32-S3, which have native USB.
Page last edited August 04, 2025
Text editor powered by tinymce.
ESP32-S2 Bugs & Limitations
Nobody likes bugs, but all nontrivial software and hardware has some. The master list of problems is the Issues list on github.
The default I2C bus clock speed is 100 kHz (100000) . At that rate, the ESP32-S2 will leave 10ms gaps between I2C transactions. This can slow down your I2C interactions considerably, such as when you are controlling a stepper motor with a PCA9685 controller.
Raising the I2C bus frequency to 125 kHz (125000) or higher fixes this problem. If your I2C peripheral can handle higher frequencies, you can use 400 kHz (400000) or even in some cases 1 MHz (1000000).
Note that board.I2C() creates an I2C bus that runs at 100 kHz. The bus frequency cannot be changed.. To create an I2C bus on the default I2C pins that runs at a different frequency, you must use busio.I2C(board.SCL, board.SDA, frequency=).
Current versions of the ESP-IDF SDK do not have the required APIs for DAC-based audio output. Once a future version of ESP-IDF that adds it, it will be possible to implement DAC-based AudioOut in CircuitPython.
Workaround: PWMOut can create tones and buzzes.
Workaround: I2SOut audio is currently being developed and will work with boards such as the I2S 3W Class D Amplifier Breakout - MAX98357A.
ESP32-S2 has hardware limitations on what kind of "pin alarms" can wake it. The following combinations are possible:
- EITHER one or two pins that wake from deep sleep when they are pulled LOW
- OR an arbitrary number of pins that wake from deep sleep when they are pulled HIGH, and optionally one pin that wakes from deep sleep when pulled LOW
This means that "wake" buttons should be wired so that pressing them pulls HIGH and a pull DOWN resistor is used with the pin. However, in some hardware designs including the original MagTag, the integrated buttons are pulled LOW when pressed and so only 1 or 2 buttons can be selected to wake the MagTag.
Page last edited August 04, 2025
Text editor powered by tinymce.
Troubleshooting
From time to time, you will run into issues when working with CircuitPython. Here are a few things you may encounter and how to resolve them.
Always Run the Latest Version of CircuitPython and Libraries
As CircuitPython development continues and there are new releases, Adafruit will stop supporting older releases. You need to update to the latest CircuitPython.
You need to download the CircuitPython Library Bundle that matches your version of CircuitPython. Please update CircuitPython and then download the latest bundle.
As new versions of CircuitPython are released, Adafruit will stop providing the previous bundles as automatically created downloads on the Adafruit CircuitPython Library Bundle repo. If you must continue to use an earlier version, you can still download the appropriate version of mpy-cross from the particular release of CircuitPython on the CircuitPython repo and create your own compatible .mpy library files. However, it is best to update to the latest for both CircuitPython and the library bundle.
I have to continue using CircuitPython 7.x or earlier. Where can I find compatible libraries?
Adafruit is no longer building or supporting the CircuitPython 7.x or earlier library bundles. You are highly encourged to update CircuitPython to the latest version and use the current version of the libraries. However, if for some reason you cannot update, links to the previous bundles are available in the FAQ.
macOS Sonoma before 14.4: Errors Writing to CIRCUITPY
macOS 14.4 - 15.1: Slow Writes to CIRCUITPY
macOS Sonoma before 14.4 took many seconds to complete writes to small FAT drives, 8MB or smaller. This causes errors when writing to CIRCUITPY. The best solution was to remount the CIRCUITPY drive after it is automatically mounted. Or consider downgrading back to Ventura if that works for you. This problem was tracked in CircuitPython GitHub issue 8449.
Below is a shell script to do this remount conveniently (courtesy @czei in GitHub). Copy the code here into a file named, say, remount-CIRCUITPY.sh. Place the file in a directory on your PATH, or in some other convenient place.
macOS Sonoma 14.4 and versions of macOS before Sequoia 15.2 did not have the problem above, but did take an inordinately long time to write to FAT drives of size 1GB or less (40 times longer than 2GB drives). As of macOS 15.2, writes are no longer very slow. This problem was tracked in CircuitPython GitHub issue 8918.
#!/bin/sh # # This works around bug where, by default, # macOS 14.x before 14.4 writes part of a file immediately, # and then doesn't update the directory for 20-60 seconds, causing # the file system to be corrupted. # disky=`df | grep CIRCUITPY | cut -d" " -f1` sudo umount /Volumes/CIRCUITPY sudo mkdir /Volumes/CIRCUITPY sleep 2 sudo mount -v -o noasync -t msdos $disky /Volumes/CIRCUITPY
Then in a Terminal window, do this to make this script executable:
chmod +x remount-CIRCUITPY.sh
Place the file in a directory on your PATH, or in some other convenient place.
Now, each time you plug in or reset your CIRCUITPY board, run the file remount-CIRCUITPY.sh. You can run it in a Terminal window or you may be able to place it on the desktop or in your dock to run it just by double-clicking.
This will be something of a nuisance but it is the safest solution.
This problem is being tracked in this CircuitPython issue.
Bootloader (boardnameBOOT) Drive Not Present
You may have a different board.
Only Adafruit Express boards and the SAMD21 non-Express boards ship with the UF2 bootloader installed. The Feather M0 Basic, Feather M0 Adalogger, and similar boards use a regular Arduino-compatible bootloader, which does not show a boardnameBOOT drive.
MakeCode
If you are running a MakeCode program on Circuit Playground Express, press the reset button just once to get the CPLAYBOOT drive to show up. Pressing it twice will not work.
macOS
DriveDx and its accompanything SAT SMART Driver can interfere with seeing the BOOT drive. See this forum post for how to fix the problem.
Windows 10 or later
Did you install the Adafruit Windows Drivers package by mistake, or did you upgrade to Windows 10 or later with the driver package installed? You don't need to install this package on Windows 10 or 11for most Adafruit boards. The old version (v1.5) can interfere with recognizing your device. Go to Settings -> Apps and uninstall all the "Adafruit" driver programs.
Windows 7 or 8.1
Windows 7 and 8.1 have reached end of life. It is recommended that you upgrade to Windows 10 or 11 if possible. Drivers are available for some older CircuitPython boards, but there are no plans to release drivers for newer boards.
You should now be done! Test by unplugging and replugging the board. You should see the CIRCUITPY drive, and when you double-click the reset button (single click on Circuit Playground Express running MakeCode), you should see the appropriate boardnameBOOT drive.
Let us know in the Adafruit support forums or on the Adafruit Discord if this does not work for you!
Windows Explorer Locks Up When Accessing boardnameBOOT Drive
On Windows, several third-party programs that can cause issues. The symptom is that you try to access the boardnameBOOT drive, and Windows or Windows Explorer seems to lock up. These programs are known to cause trouble:
- AIDA64: to fix, stop the program. This problem has been reported to AIDA64. They acquired hardware to test, and released a beta version that fixes the problem. This may have been incorporated into the latest release. Please let us know in the forums if you test this.
- BitDefender anti-virus
- Hard Disk Sentinel
- Kaspersky anti-virus: To fix, you may need to disable Kaspersky completely. Disabling some aspects of Kaspersky does not always solve the problem. This problem has been reported to Kaspersky.
- ESET NOD32 anti-virus: There have been problems with at least version 9.0.386.0, solved by uninstallation.
Copying UF2 to boardnameBOOT Drive Hangs at 0% Copied
On Windows, a Western DIgital (WD) utility that comes with their external USB drives can interfere with copying UF2 files to the boardnameBOOT drive. Uninstall that utility to fix the problem.
CIRCUITPY Drive Does Not Appear or Disappears Quickly
BitDefender anti-virus has been reported to block access to CIRCUITPY. You can set an exception for the drive letter.
Kaspersky anti-virus can block the appearance of the CIRCUITPY drive. There has not yet been settings change discovered that prevents this. Complete uninstallation of Kaspersky fixes the problem.
Norton anti-virus can interfere with CIRCUITPY. A user has reported this problem on Windows 7. The user turned off both Smart Firewall and Auto Protect, and CIRCUITPY then appeared.
Sophos Endpoint security software can cause CIRCUITPY to disappear and the BOOT drive to reappear. It is not clear what causes this behavior.
Samsung Magician can cause CIRCUITPY to disappear (reported here and here).
"M105" Seen on Display, Crashes, Missing CIRCUITPY
The Cura 3D printing program sends 3D printing GCODE commands to unused serial ports to try to find 3D printers connected over serial. This causes a variety of problems. Disable (uncheck) USB Printing in Cura in the Market -> Installed menu, or uninstall Cura. For more information see this forum post, this CircuitPython issue, and this Cura issue.
Device Errors or Problems on Windows
Windows can become confused about USB device installations. Try cleaning up your USB devices. Use Uwe Sieber's Device Cleanup Tool (on that page, scroll down to "Device Cleanup Tool"). Download and unzip the tool. Unplug all the boards and other USB devices you want to clean up. Run the tool as Administrator. You will see a listing like this, probably with many more devices. It is listing all the USB devices that are not currently attached.

Select all the devices you want to remove, and then press Delete. It is usually safe just to select everything. Any device that is removed will get a fresh install when you plug it in. Using the Device Cleanup Tool also discards all the COM port assignments for the unplugged boards. If you have used many Arduino and CircuitPython boards, you have probably seen higher and higher COM port numbers used, seemingly without end. This will fix that problem.
Serial Console in Mu Not Displaying Anything
There are times when the serial console will accurately not display anything, such as, when no code is currently running, or when code with no serial output is already running before you open the console. However, if you find yourself in a situation where you feel it should be displaying something like an error, consider the following.
Depending on the size of your screen or Mu window, when you open the serial console, the serial console panel may be very small. This can be a problem. A basic CircuitPython error takes 10 lines to display!
Auto-reload is on. Simply save files over USB to run them or enter REPL to disable. code.py output: Traceback (most recent call last): File "code.py", line 7 SyntaxError: invalid syntax Press any key to enter the REPL. Use CTRL-D to reload.
More complex errors take even more lines!
Therefore, if your serial console panel is five lines tall or less, you may only see blank lines or blank lines followed by Press any key to enter the REPL. Use CTRL-D to reload.. If this is the case, you need to either mouse over the top of the panel to utilise the option to resize the serial panel, or use the scrollbar on the right side to scroll up and find your message.

This applies to any kind of serial output whether it be error messages or print statements. So before you start trying to debug your problem on the hardware side, be sure to check that you haven't simply missed the serial messages due to serial output panel height.
code.py Restarts Constantly
CircuitPython will restart code.py if you or your computer writes to something on the CIRCUITPY drive. This feature is called auto-reload, and lets you test a change to your program immediately.
Some utility programs, such as backup, anti-virus, or disk-checking apps, will write to the CIRCUITPY as part of their operation. Sometimes they do this very frequently, causing constant restarts.
Acronis True Image and related Acronis programs on Windows are known to cause this problem. It is possible to prevent this by disabling the "Acronis Managed Machine Service Mini".
If you cannot stop whatever is causing the writes, you can disable auto-reload by putting this code in boot.py or code.py:
import supervisor
supervisor.runtime.autoreload = False
CircuitPython RGB Status Light
Nearly all CircuitPython-capable boards have a single NeoPixel or DotStar RGB LED on the board that indicates the status of CircuitPython. A few boards designed before CircuitPython existed, such as the Feather M0 Basic, do not.
Circuit Playground Express and Circuit Playground Bluefruit have multiple RGB LEDs, but do NOT have a status LED. The LEDs are all green when in the bootloader. In versions before 7.0.0, they do NOT indicate any status while running CircuitPython.
CircuitPython 7.0.0 and Later
The status LED blinks were changed in CircuitPython 7.0.0 in order to save battery power and simplify the blinks. These blink patterns will occur on single color LEDs when the board does not have any RGB LEDs. Speed and blink count also vary for this reason.
On start up, the LED will blink YELLOW multiple times for 1 second. Pressing the RESET button (or on Espressif, the BOOT button) during this time will restart the board and then enter safe mode. On Bluetooth capable boards, after the yellow blinks, there will be a set of faster blue blinks. Pressing reset during the BLUE blinks will clear Bluetooth information and start the device in discoverable mode, so it can be used with a BLE code editor.
Once started, CircuitPython will blink a pattern every 5 seconds when no user code is running to indicate why the code stopped:
- 1 GREEN blink: Code finished without error.
- 2 RED blinks: Code ended due to an exception. Check the serial console for details.
- 3 YELLOW blinks: CircuitPython is in safe mode. No user code was run. Check the serial console for safe mode reason.
When in the REPL, CircuitPython will set the status LED to WHITE. You can change the LED color from the REPL. The status indicator will not persist on non-NeoPixel or DotStar LEDs.

CircuitPython 6.3.0 and earlier
Here's what the colors and blinking mean:
- steady GREEN: code.py (or code.txt, main.py, or main.txt) is running
- pulsing GREEN: code.py (etc.) has finished or does not exist
- steady YELLOW at start up: (4.0.0-alpha.5 and newer) CircuitPython is waiting for a reset to indicate that it should start in safe mode
- pulsing YELLOW: Circuit Python is in safe mode: it crashed and restarted
- steady WHITE: REPL is running
- steady BLUE: boot.py is running
Colors with multiple flashes following indicate a Python exception and then indicate the line number of the error. The color of the first flash indicates the type of error:
- GREEN: IndentationError
- CYAN: SyntaxError
- WHITE: NameError
- ORANGE: OSError
- PURPLE: ValueError
- YELLOW: other error
These are followed by flashes indicating the line number, including place value. WHITE flashes are thousands' place, BLUE are hundreds' place, YELLOW are tens' place, and CYAN are one's place. So for example, an error on line 32 would flash YELLOW three times and then CYAN two times. Zeroes are indicated by an extra-long dark gap.

Serial console showing ValueError: Incompatible .mpy file
This error occurs when importing a module that is stored as a .mpy binary file that was generated by a different version of CircuitPython than the one its being loaded into. In particular, the mpy binary format changed between CircuitPython versions 6.x and 7.x, 2.x and 3.x, and 1.x and 2.x.
So, for instance, if you upgraded to CircuitPython 7.x from 6.x you’ll need to download a newer version of the library that triggered the error on import. All libraries are available in the Adafruit bundle.
CIRCUITPY Drive Issues
You may find that you can no longer save files to your CIRCUITPY drive. You may find that your CIRCUITPY stops showing up in your file explorer, or shows up as NO_NAME. These are indicators that your filesystem has issues. When the CIRCUITPY disk is not safely ejected before being reset by the button or being disconnected from USB, it may corrupt the flash drive. It can happen on Windows, Mac or Linux, though it is more common on Windows.
Be aware, if you have used Arduino to program your board, CircuitPython is no longer able to provide the USB services. You will need to reload CircuitPython to resolve this situation.
The easiest first step is to reload CircuitPython. Double-tap reset on the board so you get a boardnameBOOT drive rather than a CIRCUITPY drive, and copy the latest version of CircuitPython (.uf2) back to the board. This may restore CIRCUITPY functionality.
If reloading CircuitPython does not resolve your issue, the next step is to try putting the board into safe mode.
Safe Mode
Whether you've run into a situation where you can no longer edit your code.py on your CIRCUITPY drive, your board has gotten into a state where CIRCUITPY is read-only, or you have turned off the CIRCUITPY drive altogether, safe mode can help.
Safe mode in CircuitPython does not run any user code on startup, and disables auto-reload. This means a few things. First, safe mode bypasses any code in boot.py (where you can set CIRCUITPY read-only or turn it off completely). Second, it does not run the code in code.py. And finally, it does not automatically soft-reload when data is written to the CIRCUITPY drive.
Therefore, whatever you may have done to put your board in a non-interactive state, safe mode gives you the opportunity to correct it without losing all of the data on the CIRCUITPY drive.
Entering Safe Mode in CircuitPython 7.x and Later
You can enter safe by pressing reset during the right time when the board boots. Immediately after the board starts up or resets, it waits one second. On some boards, the onboard status LED will blink yellow during that time. If you press reset during that one second period, the board will start up in safe mode. It can be difficult to react to the yellow LED, so you may want to think of it simply as a "slow" double click of the reset button. (Remember, a fast double click of reset enters the bootloader.)
Entering Safe Mode in CircuitPython 6.x
You can enter safe by pressing reset during the right time when the board boots.. Immediately after the board starts up or resets, it waits 0.7 seconds. On some boards, the onboard status LED (highlighted in green above) will turn solid yellow during this time. If you press reset during that 0.7 seconds, the board will start up in safe mode. It can be difficult to react to the yellow LED, so you may want to think of it simply as a slow double click of the reset button. (Remember, a fast double click of reset enters the bootloader.)
In Safe Mode
Once you've entered safe mode successfully in CircuitPython 6.x, the LED will pulse yellow.
If you successfully enter safe mode on CircuitPython 7.x, the LED will intermittently blink yellow three times.
If you connect to the serial console, you'll find the following message.
Auto-reload is off.
Running in safe mode! Not running saved code.

CircuitPython is in safe mode because you pressed the reset button during boot. Press again to exit safe mode.

Press any key to enter the REPL. Use CTRL-D to reload.
You can now edit the contents of the CIRCUITPY drive. Remember, your code will not run until you press the reset button, or unplug and plug in your board, to get out of safe mode.
At this point, you'll want to remove any user code in code.py and, if present, the boot.py file from CIRCUITPY. Once removed, tap the reset button, or unplug and plug in your board, to restart CircuitPython. This will restart the board and may resolve your drive issues. If resolved, you can begin coding again as usual.
If safe mode does not resolve your issue, the board must be completely erased and CircuitPython must be reloaded onto the board.
To erase CIRCUITPY: storage.erase_filesystem()
CircuitPython includes a built-in function to erase and reformat the filesystem. If you have a version of CircuitPython older than 2.3.0 on your board, you can update to the newest version to do this.
- Connect to the CircuitPython REPL using Mu or a terminal program.
- Type the following into the REPL:
>>> import storage
>>> storage.erase_filesystem()
CIRCUITPY will be erased and reformatted, and your board will restart. That's it!
Erase CIRCUITPY Without Access to the REPL
If you can't access the REPL, or you're running a version of CircuitPython previous to 2.3.0 and you don't want to upgrade, there are options available for some specific boards.
The options listed below are considered to be the "old way" of erasing your board. The method shown above using the REPL is highly recommended as the best method for erasing your board.
For the specific boards listed below:
If the board you are trying to erase is listed below, follow the steps to use the file to erase your board.
1. Download the correct erase file:
2. Double-click the reset button on the board to bring up the boardnameBOOT drive.
3. Drag the erase .uf2 file to the boardnameBOOT drive.
4. The status LED will turn yellow or blue, indicating the erase has started.
5. After approximately 15 seconds, the status LED will light up green. On the NeoTrellis M4 this is the first NeoPixel on the grid
6. Double-click the reset button on the board to bring up the boardnameBOOT drive.
7. Drag the appropriate latest release of CircuitPython .uf2 file to the boardnameBOOT drive.
It should reboot automatically and you should see CIRCUITPY in your file explorer again.
If the LED flashes red during step 5, it means the erase has failed. Repeat the steps starting with 2.
If you haven't already downloaded the latest release of CircuitPython for your board, check out the installation page. You'll also need to load your code and reinstall your libraries!
For SAMD21 non-Express boards that have a UF2 bootloader:
Any SAMD21-based microcontroller that does not have external flash available is considered a SAMD21 non-Express board. Non-Express boards that have a UF2 bootloader include Trinket M0, GEMMA M0, QT Py M0, and the SAMD21-based Trinkey boards.
If you are trying to erase a SAMD21 non-Express board, follow these steps to erase your board.
1. Download the erase file:
2. Double-click the reset button on the board to bring up the boardnameBOOT drive.
3. Drag the erase .uf2 file to the boardnameBOOT drive.
4. The boot LED will start flashing again, and the boardnameBOOT drive will reappear.
5. Drag the appropriate latest release CircuitPython .uf2 file to the boardnameBOOT drive.
It should reboot automatically and you should see CIRCUITPY in your file explorer again.
If you haven't already downloaded the latest release of CircuitPython for your board, check out the installation page YYou'll also need to load your code and reinstall your libraries!
For SAMD21 non-Express boards that do not have a UF2 bootloader:
Any SAMD21-based microcontroller that does not have external flash available is considered a SAMD21 non-Express board. Non-Express boards that do not have a UF2 bootloader include the Feather M0 Basic Proto, Feather Adalogger, or the Arduino Zero.
If you are trying to erase a non-Express board that does not have a UF2 bootloader, follow these directions to reload CircuitPython using bossac, which will erase and re-create CIRCUITPY.
Running Out of File Space on SAMD21 Non-Express Boards
Any SAMD21-based microcontroller that does not have external flash available is considered a SAMD21 non-Express board. This includes boards like the Trinket M0, GEMMA M0, QT Py M0, and the SAMD21-based Trinkey boards.
The file system on the board is very tiny. (Smaller than an ancient floppy disk.) So, its likely you'll run out of space but don't panic! There are a number of ways to free up space.

Delete something!
The simplest way of freeing up space is to delete files from the drive. Perhaps there are libraries in the lib folder that you aren't using anymore or test code that isn't in use. Don't delete the lib folder completely, though, just remove what you don't need.
The board ships with the Windows 7 serial driver too! Feel free to delete that if you don't need it or have already installed it. It's ~12KiB or so.
Use tabs
One unique feature of Python is that the indentation of code matters. Usually the recommendation is to indent code with four spaces for every indent. In general, that is recommended too. However, one trick to storing more human-readable code is to use a single tab character for indentation. This approach uses 1/4 of the space for indentation and can be significant when you're counting bytes.
On macOS?
MacOS loves to generate hidden files. Luckily you can disable some of the extra hidden files that macOS adds by running a few commands to disable search indexing and create zero byte placeholders. Follow the steps below to maximize the amount of space available on macOS.
Prevent & Remove macOS Hidden Files
First find the volume name for your board. With the board plugged in run this command in a terminal to list all the volumes:
ls -l /Volumes
Look for a volume with a name like CIRCUITPY (the default for CircuitPython). The full path to the volume is the /Volumes/CIRCUITPY path.
Now follow the steps from this question to run these terminal commands that stop hidden files from being created on the board:
mdutil -i off /Volumes/CIRCUITPY
cd /Volumes/CIRCUITPY
rm -rf .{,_.}{fseventsd,Spotlight-V*,Trashes}
mkdir .fseventsd
touch .fseventsd/no_log .metadata_never_index .Trashes
cd -
Replace /Volumes/CIRCUITPY in the commands above with the full path to your board's volume if it's different. At this point all the hidden files should be cleared from the board and some hidden files will be prevented from being created.
Alternatively, with CircuitPython 4.x and above, the special files and folders mentioned above will be created automatically if you erase and reformat the filesystem. WARNING: Save your files first! Do this in the REPL:
>>> import storage>>> storage.erase_filesystem()
However there are still some cases where hidden files will be created by MacOS. In particular if you copy a file that was downloaded from the internet it will have special metadata that MacOS stores as a hidden file. Luckily you can run a copy command from the terminal to copy files without this hidden metadata file. See the steps below.
Copy Files on macOS Without Creating Hidden Files
Once you've disabled and removed hidden files with the above commands on macOS you need to be careful to copy files to the board with a special command that prevents future hidden files from being created. Unfortunately you cannot use drag and drop copy in Finder because it will still create these hidden extended attribute files in some cases (for files downloaded from the internet, like Adafruit's modules).
To copy a file or folder use the -X option for the cp command in a terminal. For example to copy a file_name.mpy file to the board use a command like:
cp -X file_name.mpy /Volumes/CIRCUITPY
(Replace file_name.mpy with the name of the file you want to copy.)
Or to copy a folder and all of the files and folders contained within, use a command like:
cp -rX folder_to_copy /Volumes/CIRCUITPY
If you are copying to the lib folder, or another folder, make sure it exists before copying.
# if lib does not exist, you'll create a file named lib !
cp -X file_name.mpy /Volumes/CIRCUITPY/lib
# This is safer, and will complain if a lib folder does not exist.
cp -X file_name.mpy /Volumes/CIRCUITPY/lib/
Other macOS Space-Saving Tips
If you'd like to see the amount of space used on the drive and manually delete hidden files here's how to do so. First, move into the Volumes/ directory with cd /Volumes/, and then list the amount of space used on the CIRCUITPY drive with the df command.

That's not very much space left! The next step is to show a list of the files currently on the CIRCUITPY drive, including the hidden files, using the ls command. You cannot use Finder to do this, you must do it via command line!

There are a few of the hidden files that MacOS loves to generate, all of which begin with a ._ before the file name. Remove the ._ files using the rm command. You can remove them all once by running rm CIRCUITPY/._*. The * acts as a wildcard to apply the command to everything that begins with ._ at the same time.

Finally, you can run df again to see the current space used.

Nice! You have 12Ki more than before! This space can now be used for libraries and code!
Device Locked Up or Boot Looping
In rare cases, it may happen that something in your code.py or boot.py files causes the device to get locked up, or even go into a boot loop. A boot loop occurs when the board reboots repeatedly and never fully loads. These are not caused by your everyday Python exceptions, typically it's the result of a deeper problem within CircuitPython. In this situation, it can be difficult to recover your device if CIRCUITPY is not allowing you to modify the code.py or boot.py files. Safe mode is one recovery option. When the device boots up in safe mode it will not run the code.py or boot.py scripts, but will still connect the CIRCUITPY drive so that you can remove or modify those files as needed.
For more information on safe mode and how to enter safe mode, see the Safe Mode section on this page.
Page last edited August 04, 2025
Text editor powered by tinymce.
Welcome to the Community!
CircuitPython is a programming language that's super simple to get started with and great for learning. It runs on microcontrollers and works out of the box. You can plug it in and get started with any text editor. The best part? CircuitPython comes with an amazing, supportive community.
Everyone is welcome! CircuitPython is Open Source. This means it's available for anyone to use, edit, copy and improve upon. This also means CircuitPython becomes better because of you being a part of it. Whether this is your first microcontroller board or you're a seasoned software engineer, you have something important to offer the Adafruit CircuitPython community. This page highlights some of the many ways you can be a part of it!

The Adafruit Discord server is the best place to start. Discord is where the community comes together to volunteer and provide live support of all kinds. From general discussion to detailed problem solving, and everything in between, Discord is a digital maker space with makers from around the world.
There are many different channels so you can choose the one best suited to your needs. Each channel is shown on Discord as "#channelname". There's the #help-with-projects channel for assistance with your current project or help coming up with ideas for your next one. There's the #show-and-tell channel for showing off your newest creation. Don't be afraid to ask a question in any channel! If you're unsure, #general is a great place to start. If another channel is more likely to provide you with a better answer, someone will guide you.
The help with CircuitPython channel is where to go with your CircuitPython questions. #help-with-circuitpython is there for new users and developers alike so feel free to ask a question or post a comment! Everyone of any experience level is welcome to join in on the conversation. Your contributions are important! The #circuitpython-dev channel is available for development discussions as well.
The easiest way to contribute to the community is to assist others on Discord. Supporting others doesn't always mean answering questions. Join in celebrating successes! Celebrate your mistakes! Sometimes just hearing that someone else has gone through a similar struggle can be enough to keep a maker moving forward.
The Adafruit Discord is the 24x7x365 hackerspace that you can bring your granddaughter to.
Visit https://adafru.it/discord to sign up for Discord. Everyone is looking forward to meeting you!

Beyond the Adafruit Learn System, which you are viewing right now, the best place to find information about CircuitPython is circuitpython.org. Everything you need to get started with your new microcontroller and beyond is available. You can do things like download CircuitPython for your microcontroller or download the latest CircuitPython Library bundle, or check out which single board computers support Blinka. You can also get to various other CircuitPython related things like Awesome CircuitPython or the Python for Microcontrollers newsletter. This is all incredibly useful, but it isn't necessarily community related. So why is it included here? The Contributing page.
CircuitPython itself is written in C. However, all of the Adafruit CircuitPython libraries are written in Python. If you're interested in contributing to CircuitPython on the Python side of things, check out circuitpython.org/contributing. You'll find information pertaining to every Adafruit CircuitPython library GitHub repository, giving you the opportunity to join the community by finding a contributing option that works for you.
Note the date on the page next to Current Status for:

If you submit any contributions to the libraries, and do not see them reflected on the Contributing page, it could be that the job that checks for new updates hasn't yet run for today. Simply check back tomorrow!
Now, a look at the different options.
Pull Requests
The first tab you'll find is a list of open pull requests.

GitHub pull requests, or PRs, are opened when folks have added something to an Adafruit CircuitPython library GitHub repo, and are asking for Adafruit to add, or merge, their changes into the main library code. For PRs to be merged, they must first be reviewed. Reviewing is a great way to contribute! Take a look at the list of open pull requests, and pick one that interests you. If you have the hardware, you can test code changes. If you don't, you can still check the code updates for syntax. In the case of documentation updates, you can verify the information, or check it for spelling and grammar. Once you've checked out the update, you can leave a comment letting us know that you took a look. Once you've done that for a while, and you're more comfortable with it, you can consider joining the CircuitPythonLibrarians review team. The more reviewers we have, the more authors we can support. Reviewing is a crucial part of an open source ecosystem, CircuitPython included.
Open Issues
The second tab you'll find is a list of open issues.

GitHub issues are filed for a number of reasons, including when there is a bug in the library or example code, or when someone wants to make a feature request. Issues are a great way to find an opportunity to contribute directly to the libraries by updating code or documentation. If you're interested in contributing code or documentation, take a look at the open issues and find one that interests you.
If you're not sure where to start, you can search the issues by label. Labels are applied to issues to make the goal easier to identify at a first glance, or to indicate the difficulty level of the issue. Click on the dropdown next to "Sort by issue labels" to see the list of available labels, and click on one to choose it.

If you're new to everything, new to contributing to open source, or new to contributing to the CircuitPython project, you can choose "Good first issue". Issues with that label are well defined, with a finite scope, and are intended to be easy for someone new to figure out.
If you're looking for something a little more complicated, consider "Bug" or "Enhancement". The Bug label is applied to issues that pertain to problems or failures found in the library. The Enhancement label is applied to feature requests.
Don't let the process intimidate you. If you're new to Git and GitHub, there is a guide to walk you through the entire process. As well, there are always folks available on Discord to answer questions.
Library Infrastructure Issues
The third tab you'll find is a list of library infrastructure issues.

This section is generated by a script that runs checks on the libraries, and then reports back where there may be issues. It is made up of a list of subsections each containing links to the repositories that are experiencing that particular issue. This page is available mostly for internal use, but you may find some opportunities to contribute on this page. If there's an issue listed that sounds like something you could help with, mention it on Discord, or file an issue on GitHub indicating you're working to resolve that issue. Others can reply either way to let you know what the scope of it might be, and help you resolve it if necessary.
CircuitPython Localization
The fourth tab you'll find is the CircuitPython Localization tab.
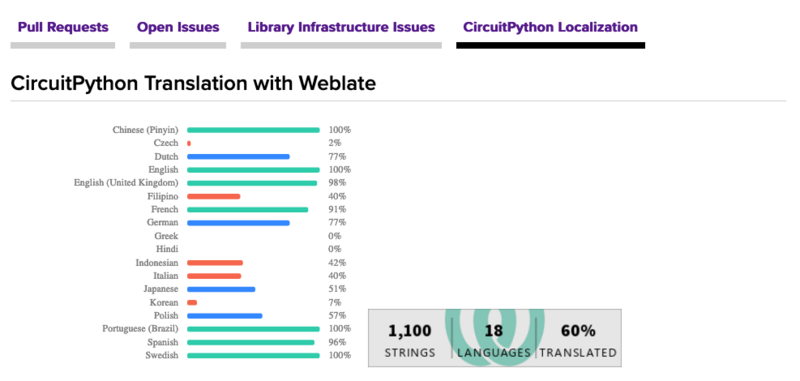
If you speak another language, you can help translate CircuitPython! The translations apply to informational and error messages that are within the CircuitPython core. It means that folks who do not speak English have the opportunity to have these messages shown to them in their own language when using CircuitPython. This is incredibly important to provide the best experience possible for all users. CircuitPython uses Weblate to translate, which makes it much simpler to contribute translations. You will still need to know some CircuitPython-specific practices and a few basics about coding strings, but as with any CircuitPython contributions, folks are there to help.
Regardless of your skill level, or how you want to contribute to the CircuitPython project, there is an opportunity available. The Contributing page is an excellent place to start!

Whether you're just beginning or are life-long programmer who would like to contribute, there are ways for everyone to be a part of the CircuitPython project. The CircuitPython core is written in C. The libraries are written in Python. GitHub is the best source of ways to contribute to the CircuitPython core, and the CircuitPython libraries. If you need an account, visit https://github.com/ and sign up.
If you're new to GitHub or programming in general, there are great opportunities for you. For the CircuitPython core, head over to the CircuitPython repository on GitHub, click on "Issues", and you'll find a list that includes issues labeled "good first issue". For the libraries, head over to the Contributing page Issues list, and use the drop down menu to search for "good first issue". These issues are things that have been identified as something that someone with any level of experience can help with. These issues include options like updating documentation, providing feedback, and fixing simple bugs. If you need help getting started with GitHub, there is an excellent guide on Contributing to CircuitPython with Git and GitHub.

Already experienced and looking for a challenge? Checkout the rest of either issues list and you'll find plenty of ways to contribute. You'll find all sorts of things, from new driver requests, to library bugs, to core module updates. There's plenty of opportunities for everyone at any level!
When working with or using CircuitPython or the CircuitPython libraries, you may find problems. If you find a bug, that's great! The team loves bugs! Posting a detailed issue to GitHub is an invaluable way to contribute to improving CircuitPython. For CircuitPython itself, file an issue here. For the libraries, file an issue on the specific library repository on GitHub. Be sure to include the steps to replicate the issue as well as any other information you think is relevant. The more detail, the better!
Testing new software is easy and incredibly helpful. Simply load the newest version of CircuitPython or a library onto your CircuitPython hardware, and use it. Let us know about any problems you find by posting a new issue to GitHub. Software testing on both stable and unstable releases is a very important part of contributing CircuitPython. The developers can't possibly find all the problems themselves! They need your help to make CircuitPython even better.
On GitHub, you can submit feature requests, provide feedback, report problems and much more. If you have questions, remember that Discord and the Forums are both there for help!

The Adafruit Forums are the perfect place for support. Adafruit has wonderful paid support folks to answer any questions you may have. Whether your hardware is giving you issues or your code doesn't seem to be working, the forums are always there for you to ask. You need an Adafruit account to post to the forums. You can use the same account you use to order from Adafruit.
While Discord may provide you with quicker responses than the forums, the forums are a more reliable source of information. If you want to be certain you're getting an Adafruit-supported answer, the forums are the best place to be.
There are forum categories that cover all kinds of topics, including everything Adafruit. The Adafruit CircuitPython category under "Supported Products & Projects" is the best place to post your CircuitPython questions.

Be sure to include the steps you took to get to where you are. If it involves wiring, post a picture! If your code is giving you trouble, include your code in your post! These are great ways to make sure that there's enough information to help you with your issue.
You might think you're just getting started, but you definitely know something that someone else doesn't. The great thing about the forums is that you can help others too! Everyone is welcome and encouraged to provide constructive feedback to any of the posted questions. This is an excellent way to contribute to the community and share your knowledge!

Read the Docs is a an excellent resource for a more detailed look at the CircuitPython core and the CircuitPython libraries. This is where you'll find things like API documentation and example code. For an in depth look at viewing and understanding Read the Docs, check out the CircuitPython Documentation page!

Page last edited August 04, 2025
Text editor powered by tinymce.
Arduino IDE Setup
The first thing you will need to do is to download the latest release of the Arduino IDE. You will need to be using version 1.8 or higher for this guide
To use the ESP32-S2/S3 with Arduino, you'll need to follow the steps below for your operating system. You can also check out the Espressif Arduino repository for the most up to date details on how to install it.
After you have downloaded and installed the latest version of Arduino IDE, you will need to start the IDE and navigate to the Preferences menu. You can access it from the File menu in Windows or Linux, or the Arduino menu on OS X.

A dialog will pop up just like the one shown below.

We will be adding a URL to the new Additional Boards Manager URLs option. The list of URLs is comma separated, and you will only have to add each URL once. New Adafruit boards and updates to existing boards will automatically be picked up by the Board Manager each time it is opened. The URLs point to index files that the Board Manager uses to build the list of available & installed boards.
To find the most up to date list of URLs you can add, you can visit the list of third party board URLs on the Arduino IDE wiki. We will only need to add one URL to the IDE in this example, but you can add multiple URLS by separating them with commas. Copy and paste the link below into the Additional Boards Manager URLs option in the Arduino IDE preferences.
https://raw.githubusercontent.com/espressif/arduino-esp32/gh-pages/package_esp32_index.json

If you're an advanced hacker and want the 'bleeding edge' release that may have fixes (or bugs!) you can check out the dev url instead:
https://raw.githubusercontent.com/espressif/arduino-esp32/gh-pages/package_esp32_dev_index.json
If you have multiple boards you want to support, say ESP8266 and Adafruit, have both URLs in the text box separated by a comma (,)
Once done click OK to save the new preference settings.
The next step is to actually install the Board Support Package (BSP). Go to the Tools → Board → Board Manager submenu. A dialog should come up with various BSPs. Search for esp32. Choose the latest version, which may be later than the version shown in the screenshot below.

Click the Install button and wait for it to finish. Once it is finished, you can close the dialog.
In the Tools → Board submenu you should see ESP32 Arduino and in that dropdown it should contain the ESP32 boards along with all the latest ESP32-S2/S3 boards.
Look for the board called Adafruit MagTag 2.9".

Page last edited August 04, 2025
Text editor powered by tinymce.
Using with Arduino IDE
Blink
Now you can upload your first blink sketch!
Plug in the ESP32-S2/S3 board and wait for it to be recognized by the OS (just takes a few seconds).
Select ESP32-S2/S3 Board in Arduino IDE


On the Arduino IDE, click:
Tools -> Board -> ESP32 Arduino -> Your Adafruit ESP32-S2/S3 board
The screenshot shows Metro S2 but you may have a different board. Make sure the name matches the exact product you purchased. If you don't see your board, make sure you have the latest version of the ESP32 board support package
Before we upload a sketch, place your ESP32-S2/S3 board into ROM bootloader mode.
Look for the Reset button and a second DFU / BOOT0 button
HOLD down the DFU/Boot0 button while you click Reset. Then release DFU/Boot0 button
The GIF shows a Metro S2 but your board may look different. It will still have BOOT and Reset buttons somewhere
It should appear under Tools -> Port as ESP32-S2/S3 Dev Module.

// the setup function runs once when you press reset or power the board
void setup() {
  // initialize built in LED pin as an output.
  pinMode(LED_BUILTIN, OUTPUT);
  // initialize USB serial converter so we have a port created
  Serial.begin();
}

// the loop function runs over and over again forever
void loop() {
  digitalWrite(LED_BUILTIN, HIGH);   // turn the LED on (HIGH is the voltage level)
  delay(1000);              // wait for a second
  digitalWrite(LED_BUILTIN, LOW);    // turn the LED off by making the voltage LOW
  delay(1000);              // wait for a second
}
And click upload! After uploading, you may see something like this:

And click upload! After uploading, you may see something like this, warning you that we could not get out of reset.
This is normal! Press the RESET button on your board to launch the sketch
That's it, you will be able to see the red LED blink. You will also see a new serial port created.
You may call Serial.begin(); in your sketch to create the serial port so don't forget it, it is not required for other Arduinos or previous ESP boards!

You can now select the new serial port name which will be different than the bootloader serial port. Arduino IDE will try to use auto-reset to automatically put the board into bootloader mode when you ask it to upload new code
If you ever DON'T see a serial port, or something is not working out with upload you can always manually enter bootloader mode:
- Reset board into ROM bootloader with DFU/BOOT0 + Reset buttons
- Select the ESP32S2/S3 Dev Board ROM bootloader serial port in Tools->Port menu
- Upload sketch
- Click reset button to launch code
Page last edited August 04, 2025
Text editor powered by tinymce.
Arduino Basics
Once you have Arduino installed and set up and you can upload simple blink sketches, you can move on to using each element of the MagTag board.
Using the Red LED
It's always good to blink the LED when you want to verify if something is happening on your board. The LED is on IO #13, but we recommend you use the LED_BUILTIN macro and you can use this simple sketch example to blink the LED:
void setup() {
  // initialize built in LED pin as an output.
  pinMode(LED_BUILTIN, OUTPUT);
  // initialize USB serial converter so we have a port created
  Serial.begin();
}

// the loop function runs over and over again forever
void loop() {
  digitalWrite(LED_BUILTIN, HIGH);   // turn the LED on (HIGH is the voltage level)
  delay(1000);              // wait for a second
  digitalWrite(LED_BUILTIN, LOW);    // turn the LED off by making the voltage LOW
  delay(1000);              // wait for a second
}
Reading the Buttons
There are four buttons on the front of the MagTag - they're connected to digital pins IO 11, 12, 14, and 15. (Note we skip 13 since thats the built in Red LED). However, we recommend you use the constants BUTTON_A, BUTTON_B, BUTTON_C, BUTTON_D.
// SPDX-FileCopyrightText: 2020 Limor Fried for Adafruit Industries
//
// SPDX-License-Identifier: MIT

void setup() {
  Serial.begin(115200);

  pinMode(BUTTON_A, INPUT_PULLUP);
  pinMode(BUTTON_B, INPUT_PULLUP);
  pinMode(BUTTON_C, INPUT_PULLUP);
  pinMode(BUTTON_D, INPUT_PULLUP);
}

void loop() {
  if (! digitalRead(BUTTON_A)) {
    Serial.println("Button A pressed");
  }
  if (! digitalRead(BUTTON_B)) {
    Serial.println("Button B pressed");
  }
  if (! digitalRead(BUTTON_C)) {
    Serial.println("Button C pressed");
  }
  if (! digitalRead(BUTTON_D)) {
    Serial.println("Button D pressed");
  }

  // small debugging delay
  delay(10);
}
Open the serial console and press buttons to see the serial output printed!

Using On-board Speaker
A small buzzer on the back of the MagTag can be used to create tones!
Note that, by default, the speaker amplifer is disabled so you have to enable it like so:
// set speaker enable pin to output
  pinMode(SPEAKER_SHUTDOWN, OUTPUT);
  // and immediately disable it to save power
  digitalWrite(SPEAKER_SHUTDOWN, LOW);
You can then turn it back on with
digitalWrite(SPEAKER_SHUTDOWN, HIGH);
when you're ready to play tones or short audio clips
Using On-Board NeoPixels
There are 4 NeoPixels on pin IO #1 (we recommend using the macro PIN_NEOPIXEL), they also have a power enable pin on NEOPIXEL_POWER you will need to set it to be an OUTPUT and LOW before writing data to the NeoPixels. If you turn the power pin off (by setting it HIGH) you will need to re-send your NeoPixel data after re-enabling power because the pixels will forget their setting when they lose power.
Start by installing NeoPixel library support for Arduino.
Here's an example sketch that builds on the button press example to turn the LEDs different colors when you press the buttons.
Note we fill the NeoPixels after we turn on the power and then turn them off when no buttons are pressed.
// SPDX-FileCopyrightText: 2020 Limor Fried for Adafruit Industries
//
// SPDX-License-Identifier: MIT

#include <Adafruit_NeoPixel.h>

Adafruit_NeoPixel pixels = Adafruit_NeoPixel(4, PIN_NEOPIXEL, NEO_GRB + NEO_KHZ800);

void setup() {
  //Initialize serial
  Serial.begin(115200);

  pinMode(BUTTON_A, INPUT_PULLUP);
  pinMode(BUTTON_B, INPUT_PULLUP);
  pinMode(BUTTON_C, INPUT_PULLUP);
  pinMode(BUTTON_D, INPUT_PULLUP);

  // Neopixel power
  pinMode(NEOPIXEL_POWER, OUTPUT);
  digitalWrite(NEOPIXEL_POWER, LOW); // on

  pixels.begin();
  pixels.setBrightness(50);
  pixels.fill(0xFF00FF);
  pixels.show(); // Initialize all pixels to 'off'
}

void loop() {
  if (! digitalRead(BUTTON_A)) {
    Serial.println("Button A pressed");
    digitalWrite(NEOPIXEL_POWER, LOW); // on
    pixels.fill(0xFF0000);
    pixels.show();
  }
  else if (! digitalRead(BUTTON_B)) {
    Serial.println("Button B pressed");
    digitalWrite(NEOPIXEL_POWER, LOW); // on
    pixels.fill(0x00FF00);
    pixels.show();
  }
  else if (! digitalRead(BUTTON_C)) {
    Serial.println("Button C pressed");
    digitalWrite(NEOPIXEL_POWER, LOW); // on
    pixels.fill(0x0000FF);
    pixels.show();
  }
  else if (! digitalRead(BUTTON_D)) {
    Serial.println("Button D pressed");
    digitalWrite(NEOPIXEL_POWER, LOW); // on
    pixels.fill(0xFF00FF);
    pixels.show();
  }
  else {
    // No buttons pressed! turn em off
    digitalWrite(NEOPIXEL_POWER, HIGH);
  }
}
Using On-board Accelerometer
There's a pre-soldered accelerometer that you can use to detect orientation or motion.
Start by installing the Arduino LIS3DH library
You can test the LIS3DH by loading the included acceldemo in the Arduino library

Before you upload, go down to find this section:
if (! lis.begin(0x18)) {   // change this to 0x19 for alternative i2c address
    Serial.println("Couldnt start");
    while (1) yield();
  }
And change lis.begin(0x18) to lis.begin(0x19)
Now you can upload, reset, and check the serial port for acceleration data!

Using the E-Ink Display
You've been so patient, it's time to draw to the display!
Install the Adafruit EPD / ThinkInk library and helper libraries as shown here, and then return once installed.
Open the ThinkInk_gray4 example

Change the pin definitions near the top to:
#define EPD_DC      7
#define EPD_CS      8
#define EPD_BUSY    -1
#define SRAM_CS     -1
#define EPD_RESET   6
Make sure this line near the top is uncommented, for the ThinkInk_290_Grayscale_T5 type of display (there are a lot of different displays!)
// 2.9" Grayscale Featherwing, MagTag or Breakout:
ThinkInk_290_Grayscale4_T5 display(EPD_DC, EPD_RESET, EPD_CS, SRAM_CS, EPD_BUSY);
You can now upload the example to your MagTag to see it display various graphics and text in monochrome and grayscale.
For more information on E-Ink displays, check out our detailed guide
For more information on how to display graphics, and text, check out the Adafruit GFX guide
Page last edited August 04, 2025
Text editor powered by tinymce.
WiFi Test
Thanksfully if you have ESP32 sketches, they'll 'just work' with variations of ESP32. You can find a wide range of examples in the File->Examples->Examples for Adafruit Metro ESP32-S2 subheading (the name of the board may vary so it could be "Examples for Adafruit Feather ESP32 V2" etc)

Let's start by scanning the local networks.
Load up the WiFiScan example under Examples->Examples for YOUR BOARDNAME->WiFi->WiFiScan

And upload this example to your board. The ESP32 should scan and find WiFi networks around you.
For ESP32, open the serial monitor, to see the scan begin.
For ESP32-S2, -S3 and -C3, don't forget you have to click Reset after uploading through the ROM bootloader. Then select the new USB Serial port created by the ESP32. It will take a few seconds for the board to complete the scan.

If you can not scan any networks, check your power supply. You need a solid power supply in order for the ESP32 to not brown out. A skinny USB cable or drained battery can cause issues.
WiFi Connection Test
Now that you can scan networks around you, its time to connect to the Internet!
Copy the example below and paste it into the Arduino IDE:
// SPDX-FileCopyrightText: 2020 Brent Rubell for Adafruit Industries
//
// SPDX-License-Identifier: MIT


/*
  Web client

 This sketch connects to a website (wifitest.adafruit.com/testwifi/index.html)
 using the WiFi module.

 This example is written for a network using WPA encryption. For
 WEP or WPA, change the Wifi.begin() call accordingly.

 This example is written for a network using WPA encryption. For
 WEP or WPA, change the Wifi.begin() call accordingly.

 created 13 July 2010
 by dlf (Metodo2 srl)
 modified 31 May 2012
 by Tom Igoe
 */

#include <WiFi.h>

// Enter your WiFi SSID and password
char ssid[] = "YOUR_SSID";             // your network SSID (name)
char pass[] = "YOUR_SSID_PASSWORD";    // your network password (use for WPA, or use as key for WEP)
int keyIndex = 0;                      // your network key Index number (needed only for WEP)

int status = WL_IDLE_STATUS;
// if you don't want to use DNS (and reduce your sketch size)
// use the numeric IP instead of the name for the server:
//IPAddress server(74,125,232,128);  // numeric IP for Google (no DNS)

char server[] = "wifitest.adafruit.com";    // name address for adafruit test
char path[]   = "/testwifi/index.html";

// Initialize the Ethernet client library
// with the IP address and port of the server
// that you want to connect to (port 80 is default for HTTP):
WiFiClient client;

void setup() {
  //Initialize serial and wait for port to open:
  Serial.begin(115200);
  while (!Serial) {
    ; // wait for serial port to connect. Needed for native USB port only
  }

  // attempt to connect to Wifi network:
  Serial.print("Attempting to connect to SSID: ");
  Serial.println(ssid);

  WiFi.begin(ssid, pass);
  while (WiFi.status() != WL_CONNECTED) {
      delay(500);
      Serial.print(".");
  }

  Serial.println("");
  Serial.println("Connected to WiFi");
  printWifiStatus();

  Serial.println("\nStarting connection to server...");
  // if you get a connection, report back via serial:
  if (client.connect(server, 80)) {
    Serial.println("connected to server");
    // Make a HTTP request:
    client.print("GET "); client.print(path); client.println(" HTTP/1.1");
    client.print("Host: "); client.println(server);
    client.println("Connection: close");
    client.println();
  }
}

void loop() {
  // if there are incoming bytes available
  // from the server, read them and print them:
  while (client.available()) {
    char c = client.read();
    Serial.write(c);
  }

  // if the server's disconnected, stop the client:
  if (!client.connected()) {
    Serial.println();
    Serial.println("disconnecting from server.");
    client.stop();

    // do nothing forevermore:
    while (true) {
      delay(100);
    }
  }
}


void printWifiStatus() {
  // print the SSID of the network you're attached to:
  Serial.print("SSID: ");
  Serial.println(WiFi.SSID());

  // print your board's IP address:
  IPAddress ip = WiFi.localIP();
  Serial.print("IP Address: ");
  Serial.println(ip);

  // print the received signal strength:
  long rssi = WiFi.RSSI();
  Serial.print("signal strength (RSSI):");
  Serial.print(rssi);
  Serial.println(" dBm");
}
NOTE: You must change the SECRET_SSID and SECRET_PASS in the example code to your WiFi SSID and password before uploading this to your board.

After you've set it correctly, upload and check the serial monitor. You should see the following. If not, go back, check wiring, power and your SSID/password

setup() with:
WiFi.setTxPower(WIFI_POWER_15dBm);
and confirm it with:
WiFi.getTxPower();
Secure Connection Example
Many servers today do not allow non-SSL connectivity. Lucky for you the ESP32 has a great TLS/SSL stack so you can have that all taken care of for you. Here's an example of a using a secure WiFi connection to connect to the Twitter API.
Copy and paste it into the Arduino IDE:
// SPDX-FileCopyrightText: 2015 Arturo Guadalupi
// SPDX-FileCopyrightText: 2020 Brent Rubell for Adafruit Industries
//
// SPDX-License-Identifier: MIT

/*
This example creates a client object that connects and transfers
data using always SSL.

It is compatible with the methods normally related to plain
connections, like client.connect(host, port).

Written by Arturo Guadalupi
last revision November 2015

*/

#include <WiFiClientSecure.h>
#include <WiFi.h>

// Enter your WiFi SSID and password
char ssid[] = "YOUR_SSID";             // your network SSID (name)
char pass[] = "YOUR_SSID_PASSWORD";    // your network password (use for WPA, or use as key for WEP)
int keyIndex = 0;                      // your network key Index number (needed only for WEP)

int status = WL_IDLE_STATUS;
// if you don't want to use DNS (and reduce your sketch size)
// use the numeric IP instead of the name for the server:
//IPAddress server(74,125,232,128);  // numeric IP for Google (no DNS)

#define SERVER "cdn.syndication.twimg.com"
#define PATH   "/widgets/followbutton/info.json?screen_names=adafruit"

// Initialize the SSL client library
// with the IP address and port of the server
// that you want to connect to (port 443 is default for HTTPS):
WiFiClientSecure client;

void setup() {
  //Initialize serial and wait for port to open:
  Serial.begin(115200);
  while (!Serial) {
    ; // wait for serial port to connect. Needed for native USB port only
  }

  // attempt to connect to Wifi network:
  Serial.print("Attempting to connect to SSID: ");
  Serial.println(ssid);

  WiFi.begin(ssid, pass);
  while (WiFi.status() != WL_CONNECTED) {
      delay(500);
      Serial.print(".");
  }

  Serial.println("");
  Serial.println("Connected to WiFi");
  printWifiStatus();

  client.setInsecure(); // don't use a root cert

  Serial.println("\nStarting connection to server...");
  // if you get a connection, report back via serial:
  if (client.connect(SERVER, 443)) {
    Serial.println("connected to server");
    // Make a HTTP request:
    client.println("GET " PATH " HTTP/1.1");
    client.println("Host: " SERVER);
    client.println("Connection: close");
    client.println();
  }
}

uint32_t bytes = 0;

void loop() {
  // if there are incoming bytes available
  // from the server, read them and print them:
  while (client.available()) {
    char c = client.read();
    Serial.write(c);
    bytes++;
  }

  // if the server's disconnected, stop the client:
  if (!client.connected()) {
    Serial.println();
    Serial.println("disconnecting from server.");
    client.stop();
    Serial.print("Read "); Serial.print(bytes); Serial.println(" bytes");

    // do nothing forevermore:
    while (true);
  }
}


void printWifiStatus() {
  // print the SSID of the network you're attached to:
  Serial.print("SSID: ");
  Serial.println(WiFi.SSID());

  // print your board's IP address:
  IPAddress ip = WiFi.localIP();
  Serial.print("IP Address: ");
  Serial.println(ip);

  // print the received signal strength:
  long rssi = WiFi.RSSI();
  Serial.print("signal strength (RSSI):");
  Serial.print(rssi);
  Serial.println(" dBm");
}
As before, update the ssid and password first, then upload the example to your board.
Note we use WiFiClientSecure client instead of WiFiClient client; to require a SSL connection!

Page last edited August 04, 2025
Text editor powered by tinymce.
Arduino Sleep
Once you have hardware tested and working, and you've also got WiFi connected - its time to explore deep sleep modes. When in deep sleep, the ESP32-S2 is basically completely off, it uses a tiny amount of power just to keep track of time so you can wake up after some amount of time.
When the ESP32-S2 comes back from deep-sleep it essentially does a hard-reset and begins over from scratch, so you don't get to keep your WiFi connection active. However, its pretty fast to re-connect so as long as you are only waking up about once a minute, your battery will last a lot longer!
Good Quality Sleep
Before you go into deep sleep, make sure you shut down the E-Ink display, NeoPixels, light sensor, and speaker with the following instructions:
display.powerDown();
digitalWrite(EPD_RESET, LOW); // hardware power down mode
digitalWrite(SPEAKER_SHUTDOWN, LOW); // off
digitalWrite(NEOPIXEL_POWER, HIGH); // off
Then enter deep sleep mode with
esp_sleep_enable_timer_wakeup(1000000); esp_deep_sleep_start();
the esp_sleep_enable_timer_wakeup(10000000); line tells the ESP32-S2 to restart in 10000000 microseconds, a.k.a 10000 milliseconds or 10 seconds
Here's an example sketch that wakes up, turns on the speaker and NeoPixels, draws a bitmap onto the EPD and then goes to sleep for one second. We use this demo to do power monitoring tests.
// SPDX-FileCopyrightText: 2020 Limor Fried for Adafruit Industries
//
// SPDX-License-Identifier: MIT
#include <Adafruit_ThinkInk.h>
#include <Adafruit_NeoPixel.h>
#include "magtaglogo.h"
Adafruit_NeoPixel intneo = Adafruit_NeoPixel(4, PIN_NEOPIXEL, NEO_GRB + NEO_KHZ800);
// older pre-2025 magtag
//ThinkInk_290_Grayscale4_T5 display(EPD_DC, EPD_RESET, EPD_CS, -1, -1);
// magtag with SSD1680Z chipset
ThinkInk_290_Grayscale4_EAAMFGN display(EPD_DC, EPD_RESET, EPD_CS, -1, -1);
void setup() {
//Initialize serial and wait for port to open:
Serial.begin(115200);
pinMode(BUTTON_A, INPUT_PULLUP);
pinMode(BUTTON_B, INPUT_PULLUP);
pinMode(BUTTON_C, INPUT_PULLUP);
pinMode(BUTTON_D, INPUT_PULLUP);
pinMode(13, OUTPUT);
digitalWrite(13, LOW);
// Neopixel power
pinMode(NEOPIXEL_POWER, OUTPUT);
pinMode(SPEAKER_SHUTDOWN, OUTPUT);
digitalWrite(NEOPIXEL_POWER, LOW); // on
digitalWrite(SPEAKER_SHUTDOWN, HIGH); // on
intneo.begin();
intneo.setBrightness(50);
intneo.fill(100, 0, 100);
intneo.show();
display.begin(THINKINK_MONO);
display.clearBuffer();
display.drawBitmap(0, 38, magtaglogo_mono, MAGTAGLOGO_WIDTH, MAGTAGLOGO_HEIGHT, EPD_BLACK);
display.display();
delay(1500);
display.powerDown();
digitalWrite(EPD_RESET, LOW); // hardware power down mode
digitalWrite(SPEAKER_SHUTDOWN, LOW); // off
digitalWrite(NEOPIXEL_POWER, HIGH); // off
esp_sleep_enable_timer_wakeup(1000000);
esp_deep_sleep_start();
}
void loop() {
}
Be sure to download the sketch including the logo header file by clicking Download Project Zip and verify that in the Arduino IDE you have both tabs:

This example will go to deep sleep for only one second, you can change that by adjusting the number in this line:
esp_sleep_enable_timer_wakeup(1000000);
When using deep sleep, the power draw drops to about 250uA. These are the approximate current uses:
- 40uA are used by the onboard green OK LED (you can remove the LED with a soldering iron)
- 120uA are used by the EPD in deepsleep/reset mode (we couldnt figure out how to reduce this any more but tested suggestions are welcome!)
- 50uA are used by the 3.3V regulator
- 10uA are used by the VBat resistor divider
- 30uA are used by the ESP32-S2 in deep sleep

When you want to reprogram the board, you'll want to put the MagTag in bootloader mode by holding BOOT, pressing RESET and then releasing BOOT. Otherwise the MagTag will keep going into sleep mode and will not show up in the Arduino IDE as a COM port.
Page last edited August 04, 2025
Text editor powered by tinymce.
Shipping Demo
The board ships with a demo that tests out the buttons, LEDs, EPD, accelerometer, and speaker. It may be handy if you ever need to verify your hardware is fully working!
- The NeoPixels will light up in a rainbow design
- When button A, B, C are pressed, the LEDs will turn to a solid color red, green or blue
- When button D is pressed, a chime sounds
- Red LED blinks on and off
- Display shows bitmap MagTag logo. When the accelerometer detects that the board is 'upside down' the display is rotated
- In serial console, light sensor reading and accelerometer XYZ is output
- In serial console, I2C port on STEMMA QT is scanned and visible I2C device addresses are printed
You can download the full example code for compilation by clicking Download Project Zip on this sketch to get all the files (there are two header files, coin.h with 8-bit audio and magtaglogo.h with the bitmap logo)
Before uploading to your magtag make sure you downloaded the full project and got the two header files!
To get the full set of libraries that go with the Adafruit EPD library, click this link and download the latest zip file.

// SPDX-FileCopyrightText: 2020 Limor Fried for Adafruit Industries
//
// SPDX-License-Identifier: MIT

#include <Adafruit_NeoPixel.h>
#include <Wire.h>
#include <Adafruit_ThinkInk.h>
#include <Adafruit_LIS3DH.h>
#include "coin.h"
#include "magtaglogo.h"

Adafruit_NeoPixel intneo = Adafruit_NeoPixel(4, PIN_NEOPIXEL, NEO_GRB + NEO_KHZ800);

// older pre-2025 magtag
//ThinkInk_290_Grayscale4_T5 display(EPD_DC, EPD_RESET, EPD_CS, -1, -1);
// magtag with SSD1680Z chipset
ThinkInk_290_Grayscale4_EAAMFGN display(EPD_DC, EPD_RESET, EPD_CS, -1, -1);

Adafruit_LIS3DH lis = Adafruit_LIS3DH();

uint8_t j = 0;
void setup() {
  Serial.begin(115200);
  //while (!Serial) { delay(10); }
  delay(100);
  Serial.println("Adafruit MagTag 2.9\" demo");

  intneo.begin();
  intneo.setBrightness(50);
  intneo.show(); // Initialize all pixels to 'off'

  pinMode(BUTTON_A, INPUT_PULLUP);
  pinMode(BUTTON_B, INPUT_PULLUP);
  pinMode(BUTTON_C, INPUT_PULLUP);
  pinMode(BUTTON_D, INPUT_PULLUP);

  pinMode(SPEAKER_SHUTDOWN, OUTPUT);
  digitalWrite(SPEAKER_SHUTDOWN, LOW);

  // Red LED
  pinMode(13, OUTPUT);

  // Neopixel power
  pinMode(NEOPIXEL_POWER, OUTPUT);
  digitalWrite(NEOPIXEL_POWER, LOW); // on

  display.begin(THINKINK_MONO);

  if (! lis.begin(0x19)) {
    Serial.println("Couldnt start LIS3DH");
    display.clearBuffer();
    display.setTextSize(3);
    display.setTextColor(EPD_BLACK);
    display.setCursor(20, 40);
    display.print("No LIS3DH?");
    display.display();
    while (1) delay(100);
  }

  analogReadResolution(12); //12 bits
  analogSetAttenuation(ADC_11db);  //For all pins
  display.clearBuffer();
  display.drawBitmap(0, 38, magtaglogo_mono, MAGTAGLOGO_WIDTH, MAGTAGLOGO_HEIGHT, EPD_BLACK);
  display.display();
}


uint8_t rotation = 0;

void loop() {
  j++;
  if (j == 0) {
    Serial.print("Rotation: "); Serial.println(rotation);
    if (rotation == 0 || rotation == 2) {
      display.setRotation(rotation);
      display.clearBuffer();
      display.drawBitmap(0, 38, magtaglogo_mono, MAGTAGLOGO_WIDTH, MAGTAGLOGO_HEIGHT, EPD_BLACK);
      display.display();
    }
  }
  // Red LED On
  digitalWrite(13, HIGH);

  //Serial.print(".");
  if (j % 10 == 0) {
      sensors_event_t event;
      lis.getEvent(&event);

      /* Display the results (acceleration is measured in m/s^2) */
      Serial.print("X: "); Serial.print(event.acceleration.x);
      Serial.print(" \tY: "); Serial.print(event.acceleration.y);
      Serial.print(" \tZ: "); Serial.print(event.acceleration.z);
      Serial.println(" m/s^2 ");
      if ((event.acceleration.x < -5) && (abs(event.acceleration.y) < 5)) {
        rotation = 1;
      }
      if ((abs(event.acceleration.x) < 5) && (event.acceleration.y > 5)) {
        rotation = 0;
      }
      if ((event.acceleration.x > 5) && (abs(event.acceleration.y) < 5)) {
        rotation = 3;
      }
      if ((abs(event.acceleration.x) < 5) && (event.acceleration.y < -5)) {
        rotation = 2;
      }

      int light = analogRead(LIGHT_SENSOR);
      Serial.print("Light sensor: ");
      Serial.println(light);

      Serial.print("I2C scanner: ");
      for (int i = 0x07; i <= 0x77; i++) {
        Wire.beginTransmission(i);
        bool found (Wire.endTransmission() == 0);
        if (found) {
          Serial.printf("0x%02x, ", i);
        }
      }
      Serial.println();
  }

  if (! digitalRead(BUTTON_A)) {
    Serial.println("Button A pressed");
    intneo.fill(0xFF0000);
    intneo.show();
  }
  else if (! digitalRead(BUTTON_B)) {
    Serial.println("Button B pressed");
    intneo.fill(0x00FF00);
    intneo.show();
  }
  else if (! digitalRead(BUTTON_C)) {
    Serial.println("Button C pressed");
    intneo.fill(0x0000FF);
    intneo.show();
  }
  else if (! digitalRead(BUTTON_D)) {
    intneo.fill(0x0);
    intneo.show();
    Serial.println("Button D pressed");
    digitalWrite(SPEAKER_SHUTDOWN, HIGH);
    play_tune(audio, sizeof(audio));
    digitalWrite(SPEAKER_SHUTDOWN, LOW);
  } else {
    // neopixelate
    for (int i = 0; i < intneo.numPixels(); i++) {
      intneo.setPixelColor(i, Wheel(((i * 256 / intneo.numPixels()) + j) & 255));
    }
    intneo.show();
  }

  // Red LED off
  digitalWrite(13, LOW);


  delay(10);
}

void play_tune(const uint8_t *audio, uint32_t audio_length) {
  uint32_t t;
  uint32_t prior, usec = 1000000L / SAMPLE_RATE;

  prior = micros();
  for (uint32_t i=0; i<audio_length; i++) {
    while((t = micros()) - prior < usec);
    dacWrite(A0, audio[i]);
    prior = t;
  }
}

// Input a value 0 to 255 to get a color value.
// The colours are a transition r - g - b - back to r.
uint32_t Wheel(byte WheelPos) {
  WheelPos = 255 - WheelPos;
  if (WheelPos < 85) {
    return intneo.Color(255 - WheelPos * 3, 0, WheelPos * 3);
  }
  if (WheelPos < 170) {
    WheelPos -= 85;
    return intneo.Color(0, WheelPos * 3, 255 - WheelPos * 3);
  }
  WheelPos -= 170;
  return intneo.Color(WheelPos * 3, 255 - WheelPos * 3, 0);
}
Page last edited August 04, 2025
Text editor powered by tinymce.
Quotes Example
OK now that we have the onboard elements, WiFi and deep sleep all worked out, we can now create a full demo!
This example connects to the online Adafruit Quotes service, and displays an inspiring quote once a minute with deep sleep in between.
Don't forget to update the SSID and password!
To get the full set of libraries that go with the Adafruit EPD library, click this link and download the latest zip file.
// SPDX-FileCopyrightText: 2017 Evandro Copercini
//
// SPDX-License-Identifier: Apache-2.0

/*
  Wifi secure connection example for ESP32
  Running on TLS 1.2 using mbedTLS
  2017 - Evandro Copercini - Apache 2.0 License.
*/

#include <WiFiClientSecure.h>
#include <WiFi.h>
#include <ArduinoJson.h>
#include "Adafruit_ThinkInk.h"
#include "Adafruit_NeoPixel.h"
#include <Fonts/FreeSans9pt7b.h>

const char* ssid     = "adafruit";     // your network SSID (name of wifi network)
const char* password = "ffffffff"; // your network password

const char*  server = "www.adafruit.com";
const char*  path   = "/api/quotes.php";

WiFiClientSecure client;
// older pre-2025 magtag
//ThinkInk_290_Grayscale4_T5 display(EPD_DC, EPD_RESET, EPD_CS, -1, -1);
// magtag with SSD1680Z chipset
ThinkInk_290_Grayscale4_EAAMFGN display(EPD_DC, EPD_RESET, EPD_CS, -1, -1);
Adafruit_NeoPixel intneo = Adafruit_NeoPixel(4, PIN_NEOPIXEL, NEO_GRB + NEO_KHZ800);


void deepSleep() {
  pinMode(NEOPIXEL_POWER, OUTPUT);
  pinMode(SPEAKER_SHUTDOWN, OUTPUT);
  digitalWrite(SPEAKER_SHUTDOWN, LOW); // off
  digitalWrite(NEOPIXEL_POWER, HIGH); // off
  digitalWrite(EPD_RESET, LOW); // off (yes required to save a few mA)
  pinMode(13, OUTPUT);
  digitalWrite(13, LOW);

  esp_sleep_enable_timer_wakeup(60 * 1000000); // 60 seconds
  esp_deep_sleep_start();
}

void setup() {
  //Initialize serial and wait for port to open:
  Serial.begin(115200);
  //while (!Serial) delay(10);

  pinMode(BUTTON_A, INPUT_PULLUP);
  pinMode(BUTTON_B, INPUT_PULLUP);
  pinMode(BUTTON_C, INPUT_PULLUP);
  pinMode(BUTTON_D, INPUT_PULLUP);
  pinMode(EPD_BUSY, INPUT);
  pinMode(13, OUTPUT);
  digitalWrite(13, HIGH);


  display.begin(THINKINK_GRAYSCALE4);

  Serial.print("Attempting to connect to SSID: ");
  Serial.println(ssid);

  display.clearBuffer();
  display.setFont(&FreeSans9pt7b);
  display.setTextSize(1);
  display.setTextColor(EPD_BLACK);
  display.setCursor(10, 30);
  display.print("Connecting to SSID ");
  display.println(ssid);
  display.display();

  WiFi.begin(ssid, password);

  // attempt to connect to Wifi network:
  while (WiFi.status() != WL_CONNECTED) {
    Serial.print(".");
    delay(100);
  }

  Serial.print("Connected to ");
  Serial.println(ssid);

  //client.setCACert(test_root_ca);
  //client.setCertificate(test_client_key); // for client verification
  //client.setPrivateKey(test_client_cert);	// for client verification

// Neopixel power
  pinMode(NEOPIXEL_POWER, OUTPUT);
  digitalWrite(NEOPIXEL_POWER, LOW); // on
  intneo.fill(25, 0, 0);
  intneo.show();

  Serial.println("\nStarting connection to server...");
  client.setInsecure();
  if (!client.connect(server, 443)) {
    Serial.println("Connection failed!");
    deepSleep();
  }

  intneo.fill(25, 25, 0);
  intneo.show();

  Serial.println("Connected to server!");
  // Make a HTTP request:
  client.print("GET "); client.print(path); client.println(" HTTP/1.1");
  client.print("Host: "); client.println(server);
  client.println("Connection: close");
  client.println();

  // Check HTTP status
  char status[32] = {0};
  client.readBytesUntil('\r', status, sizeof(status));
  if (strcmp(status, "HTTP/1.1 200 OK") != 0) {
    Serial.print(F("Unexpected response: "));
    Serial.println(status);
    deepSleep();
  }

  intneo.fill(0, 25, 0);
  intneo.show();
  while (client.connected()) {
    String line = client.readStringUntil('\n');
    if (line == "\r") {
      Serial.println("headers received");
      break;
    }
  }

  intneo.fill(0, 25, 25);
  intneo.show();
  while (client.peek() != '[') {
    client.read();
  }

  intneo.fill(0, 0, 25);
  intneo.show();

  // Allocate the JSON document
  // Use arduinojson.org/v6/assistant to compute the capacity.
  const size_t capacity = JSON_ARRAY_SIZE(1) + JSON_OBJECT_SIZE(8) + 200;
  DynamicJsonDocument doc(capacity);

  // Parse JSON object
  DeserializationError error = deserializeJson(doc, client);
  if (error) {
    Serial.print(F("deserializeJson() failed: "));
    Serial.println(error.c_str());
    deepSleep();
  }

  intneo.fill(0, 25, 25);
  intneo.show();

  // Extract values
  JsonObject root_0 = doc[0];
  Serial.println(F("Response:"));
  const char* root_0_text = root_0["text"];
  const char* root_0_author = root_0["author"];

  Serial.print("Quote: "); Serial.println(root_0_text);
  Serial.print("Author: "); Serial.println(root_0_author);

  display.clearBuffer();
  display.setFont(&FreeSans9pt7b);
  display.setTextSize(1);
  display.setTextWrap(true);
  display.setTextColor(EPD_BLACK);
  display.setCursor(10, 30);
  display.println(root_0_text);
  display.setTextColor(EPD_DARK);
  display.setCursor(40, 120);
  display.println(root_0_author);
  display.display();
  while (!digitalRead(EPD_BUSY)) {
    delay(10);
  }

  while (client.available() > 0)
  {
    //read back one line from the server
    String line = client.readStringUntil('\r');
    Serial.println(line);
  }

  // disconnect
  client.stop();
  deepSleep();
}

void loop() {

}
Page last edited August 04, 2025
Text editor powered by tinymce.
Usage with Adafruit IO
The ESP32-S2/S3 is an affordable, all-in-one, option for connecting your projects to the internet using our IoT platform, Adafruit IO.
- For more information and guides about Adafruit IO, check out the Adafruit IO Basics Series.
In the Arduino IDE, navigate to Sketch -> Include Library->Manage Libraries...

Enter Adafruit IO Arduino into the search box, and click Install on the Adafruit IO Arduino library option to install version 4.0.0 or higher.

When asked to install dependencies, click Install all.

If you do not already have an Adafruit IO account, create one now. Next, navigate to the Adafruit IO Dashboards page.
We'll create a dashboard to visualize and interact with the data being sent between your ESP32-S2/S3 board and Adafruit IO.


- Click the New Dashboard button.
- Name your dashboard My ESP32-S2 or My ESP32-S3 depending on your board.
- Your new dashboard should appear in the list.
- Click the link to be brought to your new dashboard.
We'll want to turn the board's LED on or off from Adafruit IO. To do this, we'll need to add a toggle button to our dashboard.


- Click the cog at the top right hand corner of your dashboard.
- In the dashboard settings dropdown, click Create New Block.
- Select the toggle block.
- Under My Feeds, enter led as a feed name. Click Create.
- Choose the led feed to connect it to the toggle block. Click Next step.


Next up, we'll want to display button press data from your board on Adafruit IO. To do this, we'll add a gauge block to the Adafruit IO dashboard. A gauge is a read only block type that shows a fixed range of values.


- Click the cog at the top right hand corner of your dashboard.
- In the dashboard settings dropdown, click Create New Block.
- Select the gauge block.
- Under My Feeds, enter button as a feed name.
- Click Create.
-
Choose the button feed to connect it to the toggle block.
- Click Next step.

Under block settings,
- Change Block Title to Button Value
- Change Gauge Min Value to 0, the button's state when it's off
- Change Gauge Max Value to 1, the button's state when it's on
- Click Create block
Your dashboard should look like the following:

For this example, you will need to open the adafruitio_26_led_btn example included with the Adafruit IO Arduino library. In the Arduino IDE, navigate to File -> Examples -> Adafruit IO Arduino -> adafruitio_26_led_btn.
Before uploading this code to the ESP32-S2/S3, you'll need to add your network and Adafruit IO credentials. Click on the config.h tab in the sketch.
Obtain your Adafruit IO Credentials from navigating to io.adafruit.com and clicking My Key. Copy and paste these credentials next to IO_USERNAME and IO_KEY.

Enter your network credentials next to WIFI_SSID and WIFI_PASS.

setup() with:
WiFi.setTxPower(WIFI_POWER_15dBm);
and confirm it with:
WiFi.getTxPower();
Click the Upload button to upload your sketch to the ESP32-S2/S3. After uploading, press the RESET button on your board to launch the sketch.
Open the Arduino Serial monitor and navigate to the Adafruit IO dashboard you created. You should see the gauge response to button press and the board's LED light up in response to the Toggle Switch block.
You should also see the ESP32-S2/S3's LED turning on and off when the LED is toggled:
Page last edited August 04, 2025
Text editor powered by tinymce.
WipperSnapper Setup
What is WipperSnapper
WipperSnapper is a firmware designed to turn any WiFi-capable board into an Internet-of-Things device without programming a single line of code. WipperSnapper connects to Adafruit IO, a web platform designed (by Adafruit!) to display, respond, and interact with your project's data.
Simply load the WipperSnapper firmware onto your board, add credentials, and plug it into power. Your board will automatically register itself with your Adafruit IO account.
From there, you can add components to your board such as buttons, switches, potentiometers, sensors, and more! Components are dynamically added to hardware, so you can immediately start interacting, logging, and streaming the data your projects produce without writing code.
Sign up for Adafruit.io
You will need an Adafruit IO account to use WipperSnapper on your board. If you do not already have one, head over to io.adafruit.com to create a free account.
Add a New Device to Adafruit IO
Log into your Adafruit IO account. Click the New Device button at the top of the page.

After clicking New Device, you should be on the board selector page. This page displays every board that is compatible with the WipperSnapper firmware.

In the board selector page's search bar, search for the MagTag. Once you've located the board you'd like to install WipperSnapper on, click the Choose Board button to bring you to the self-guided installation wizard.

Follow the step-by-step instructions on the page to install Wippersnapper on your device and connect it to Adafruit IO.

If the installation was successful, a popover should appear displaying that your board has successfully been detected by Adafruit IO.
Give your board a name and click "Continue to Device Page".

You should be brought to your board's device page.

Feedback
Adafruit.io WipperSnapper is in beta and you can help improve it!
If you have suggestions or general feedback about the installation process - visit https://io.adafruit.com/support, click "Contact Adafruit IO Support" and select "I have feedback or suggestions for the WipperSnapper Beta".
Troubleshooting
If you encountered an issue during installation, please try the steps below first.
If you're still unable to resolve the issue, or if your issue is not listed below, get in touch with us directly at https://io.adafruit.com/support. Make sure to click "Contact Adafruit IO Support" and select "There is an issue with WipperSnapper. Something is broken!"
First, make sure that you selected the correct board on the board selector.
Next, please make sure that you entered your WiFi credentials properly, there are no spaces/special characters in either your network name (SSID) or password, and that you are connected to a 2.4GHz wireless network.
If you're still unable to connect your board to WiFi, please make a new post on the WipperSnapper technical support forum with the error you're experiencing, the LED colors which are blinking, and the board you're using.
Try hard-resetting your board by unplugging it from USB power and plugging it back in.
If the error is still occurring, please make a new post on the WipperSnapper technical support forum with information about what you're experiencing, the LED colors which are blinking (if applicable), and the board you're using.
"Uninstalling" WipperSnapper
WipperSnapper firmware is an application that is loaded onto your board. There is nothing to "uninstall". However, you may want to "move" your board from running WipperSnapper to running Arduino or CircuitPython. You also may need to restore your board to the state it was shipped to you from the Adafruit factory.
Moving from WipperSnapper to CircuitPython
Follow the steps on the Installing CircuitPython page to install CircuitPython on your board running WipperSnapper.
- If you are unable to double-tap the RST button to enter the UF2 bootloader, follow the "Factory Resetting a WipperSnapper Board" instructions below.
Uploading this sketch will overwrite WipperSnapper. If you want to re-install WipperSnapper, follow the instructions at the top of this page.
Moving from WipperSnapper to Arduino
If you want to use your board with Arduino, you will use the Arduino IDE to load any sketch onto your board.
First, follow the page below to set up your Arduino IDE environment for use with your board.
Then, follow the page below to upload the "Arduino Blink" sketch to your board.
Uploading this sketch will overwrite WipperSnapper. If you want to re-install WipperSnapper, follow the instructions at the top of this page.
Factory Resetting a WipperSnapper Board
Sometimes, hardware gets into a state that requires it to be "restored" to the original state it shipped in. If you'd like to get your board back to its original factory state, follow the guide below.
This board does not have a Factory Reset firmware. You can re-install the UF2 bootloader and then install CircuitPython/Arduino by following the instructions above.
Page last edited August 04, 2025
Text editor powered by tinymce.
WipperSnapper Essentials

You've installed WipperSnapper firmware on your board and connected it to Adafruit IO. Next, to learn how to use Adafruit IO!
The Adafruit IO supports a large number of components. Components are physical parts such as buttons, switches, sensors, servos, LEDs, RGB LEDs, and more.
The following pages will get you up and running with WipperSnapper as you interact with your board's built-in components, such as read the value of a push button, send the value of an I2C sensor to the internet, and wirelessly control colorful LEDs.
Page last edited August 04, 2025
Text editor powered by tinymce.
LED Blink
One of the first programs you typically write to get used to embedded programming is a sketch that repeatably blinks an LED. IoT projects are wireless, so after completing this section, you'll be able to turn on (or off) the LED built into your board from anywhere in the world.

On the device page, click the New Component (or "+") button to open the component picker.


Search for the component name by entering LED into the text box on the component picker, the list of components should update as soon as you stop typing.
Since WipperSnapper supports such a large number of components, there is keyword filtering. Try searching for various keywords, like:
- component names:
aht20,servo,buzzer,button,led, etc - sensor types:
light,temperature,pressure,humidity, etc - interface:
i2c,uart,ds18x20,pin, etc (also I2C addresses e.g.0x44) - vendor:
Adafruit,ASAIR,Infineon,Bosch,Honeywell,Sensirion, etc
There are also product and documentation links to every component. Follow the links beneath the component descriptions to be taken to the appropriate product page or Learn Guide

On the Create LED Component form, the board's LED pin is pre-selected.
Click Create Component.

Behind the scenes, Adafruit IO sends send a command to your board running WipperSnapper telling it to configure "LED Pin" as a digital output.
Your board's page on Adafruit IO shows a new LED component.

On the board page, toggle the LED component by clicking the toggle switch. This should turn your board's built-in LED on or off.
Page last edited August 04, 2025
Text editor powered by tinymce.
NeoPixel LEDs
Your board has a WS281x RGB LED (NeoPixel, in Adafruit jargon) built in. Boards running the WipperSnapper firmware can be wirelessly controlled by Adafruit IO to interact with NeoPixels.
On this page, you'll learn how to change the color and brightness of the NeoPixel built into your board from Adafruit IO.

On the front of the board, along the top, are four addressable RGB side-emitting NeoPixel LEDs labeled together as NeoPix.
On the device page, click the New Component (or "+") button to open the component picker.


Search for the component name by entering neopixel into the text box on the component picker, the list of components should update as soon as you stop typing
Since WipperSnapper supports such a large number of components, you can use keyword filtering. Try searching for various keywords, like:
- component names:
aht20,servo,buzzer,button,neopixel, etc - sensor types:
light,temperature,pressure,humidity, etc - interface:
i2c,uart,ds18x20,pin, etc (also I2C addresses e.g.0x44) - vendor:
Adafruit,ASAIR,Infineon,Bosch,Honeywell,Sensirion, etc
There is also added product and documentation links for every component, follow the links beneath the component descriptions to be taken to the appropriate product page or Learn Guide

Select the NeoPixel from the list of results to go to the component configuration page.
There will be a back button if you select the wrong component, and you can use the Edit component icon (⚙️) on the device page to update the component configuration in the future.
The board NeoPixel pin is automatically found and selected.
Set the Number of Pixels to 4, reflecting the 4 NeoPixels on the MagTag.
Click Create Component

Behind the scenes, Adafruit IO sends a command to your board running WipperSnapper firmware telling it to configure the pin as a NeoPixel component with the settings from the form.
The Device page shows the NeoPixel component.

Set the NeoPixel's RGB Color
Since no colors have been set yet, the color picker's default value is #000000 (black in hex color code) and appears "off". You can change that to make the NeoPixel shine brightly!
On the NeoPixel component, click the color dropper at the end of the color swatch list.

A color picker pops open! Next: learning how Adafruit IO uses hex color codes to represent the colors on your NeoPixel.

Hex Colors 101
The color picker on Adafruit IO uses hex color codes to represent Red, Green, and Blue values. For example, #FF0000 is the hex color code for the color red. The colors (#FF0000) red component is FF (255 translated to decimal), the green component is 00 and the blue component is 00. Translated to RGB format, the color is RGB (255, 0, 0).
Using the color picker, or by manually entering a hex color code, select a color.
When you're ready to set the color of your device's NeoPixel, click FILL WITH COLOR. The NeoPixel will immediately glow!
Set NeoPixel Brightness
If the NeoPixel is too bright (or too dim), you can change the overall brightness. Click the gear/cog icon on the NeoPixel component to open its settings.

On the NeoPixel component form, set Brightness to a value between 0 (fully off) and 255 (full brightness).
Click the Update Component button to send the updated configuration to your device.

Page last edited August 04, 2025
Text editor powered by tinymce.
You can configure a board running WipperSnapper to read data from standard input buttons, switches, or digital sensors, and send the value to Adafruit IO.
From Adafruit IO, you will configure one of the pushbuttons on your board as a push button component. Then, when the button is pressed (or released), a value will be published to Adafruit IO.
Button Location
This example uses the board's built-in push-button and internal pull-up resistor instead of wiring a push-button up.

On the front of the board, along the bottom, there are four user-controllable buttons. In this example, we are going to use the first button on the left-hand side of the MagTag display, labeled D15 on the silkscreen.
On the device page, click the New Component (or "+") button to open the component picker.


Search for the component name by entering push into the text box on the component picker, the list of components should update as soon as you stop typing.
Since WipperSnapper supports such a large number of components, you can use filtering. Try searching for various keywords, like:
- component names:
aht20,servo,buzzer,button,potentiometer, etc - sensor types:
light,temperature,pressure,humidity, etc - interface:
i2c,uart,ds18x20,pin, etc (also I2C addresses e.g.0x44) - vendor:
Adafruit,ASAIR,Infineon,Bosch,Honeywell,Sensirion, etc
There are also added product and documentation links for every component. Follow the links beneath the component descriptions to be taken to the appropriate product page or Learn Guide.

Select the Push Button from the list of results to go to the component configuration page.
There will be a back button if you select the wrong component, and you can use the Edit component icon (⚙️) on the device page to update the component configuration in the future.
The "Create Push Button Component" form presents you with options for configuring the push button.
Start by selecting the board's pin connected to the push button.

The Return Interval dictates how frequently the value of the push-button will be sent from the board to Adafruit IO.
For this example, you will configure the push button's value to be only sent when the value changes (i.e. when it's either pressed or depressed).

Finally, check the Specify Pin Pull Direction checkbox and select the pull direction.

Make sure the form's settings look like the following screenshot. Then, click Create Component.

Adafruit IO sends a command to your WipperSnapper board, telling it to configure the GPIO pin you selected to behave as a digital input pin and to enable it to pull up the internal resistor.
Your board's page should also show the new push-button component.

Push the button on your board to change the value of the push-button component on Adafruit IO.
Page last edited August 04, 2025
Text editor powered by tinymce.
Analog Input: Light Sensor
Your microcontroller board has both digital and analog signal capabilities. Some pins are analog, some are digital, and some are capable of both. Check the Pinouts page in this guide for details about your board.
Analog signals are different from digital signals in that they can be any voltage and can vary continuously and smoothly between voltages. An analog signal is like a dimmer switch on a light, whereas a digital signal is like a simple on/off switch.
Digital signals only can ever have two states, they are either are on (high logic level voltage like 3.3V) or off (low logic level voltage like 0V / ground).
By contrast, analog signals can be any voltage in-between on and off, such as 1.8V or 0.001V or 2.98V and so on.

Analog signals are continuous values which means they can be an infinite number of different voltages. Think of analog signals like a floating point or fractional number, they can smoothly transiting to any in-between value like 1.8V, 1.81V, 1.801V, 1.8001V, 1.80001V and so forth to infinity.
Many devices use analog signals, in particular sensors typically output an analog signal or voltage that varies based on something being sensed like light, heat, humidity, etc.
Analog to Digital Converter (ADC)
An analog-to-digital-converter, or ADC, is the key to reading analog signals and voltages with a microcontroller. An ADC is a device that reads the voltage of an analog signal and converts it into a digital, or numeric, value. The microcontroller can’t read analog signals directly, so the analog signal is first converted into a numeric value by the ADC.
The black line below shows a digital signal over time, and the red line shows the converted analog signal over the same amount of time.
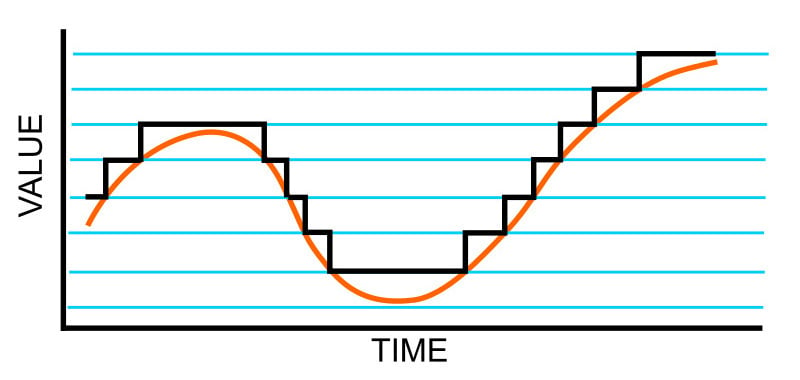
Once that analog signal has been converted by the ADC, the microcontroller can use those digital values any way you like!
Light Sensor
A light sensor (also known as a CdS cell, light-dependent resistor, or photoresistor) detects light. They change their resistive value (in ohms, Ω) depending on how much light shines into the photocell.
When a light sensor is exposed to more light, the resistance decreases. When it is exposed to less light, the resistance increases.
By using a light sensor wired in a specific way (as a voltage divider), we can turn resistance into voltage. That change is then read by your board's Analog-to-Digital converter and sent to Adafruit IO.

On the front of the board, in the center of the top is a front-facing light sensor labeled with A3 and an eye.
Create a Light Sensor Component
On the device page, click the New Component (or "+") button to open the component picker.


Search for the component name by entering light into the text box on the component picker, the list of components should update as soon as you stop typing.
WipperSnapper supports such a large number of components we added filtering!
Try searching for various keywords, like:
- component names:
aht20,servo,buzzer,button,relay, etc - sensor types:
light,temperature,pressure,humidity, etc - interface:
i2c,uart,ds18x20,pin, etc (also I2C addresses e.g.0x44) - vendor:
Adafruit,ASAIR,Infineon,Bosch,Honeywell,Sensirion, etc
We’ve also added product and documentation links to every component, follow the links beneath the component descriptions to be taken to the appropriate product page or Learn-Guide.

Select the Light Sensor from the list of results to go to the component configuration page.
There will be a back button if you select the wrong component, and you can use the Edit component icon (⚙️) on the device page to update the component configuration in the future.
The name and pin for the light sensor on your board are automatically selected. The Period determines how frequently the light sensor's value will be checked and sent to Adafruit IO. Set it to check the light sensor value every 30 seconds.
Click Create Component.

The device page shows a new light sensor component. The value of this component will change every 30 seconds.

To test the light sensor, try covering the light sensor with a piece of paper. Navigate to the feed page by clicking the graph icon on the top right corner of the light sensor component.

On the light sensor feed page, you'll be able to observe a graph of the light sensor values as they change over time.

Page last edited August 04, 2025
Text editor powered by tinymce.
I2C Sensors
Inter-Integrated Circuit, aka I2C, is a two-wire protocol for connecting sensors and "devices" to a microcontroller. A large number of sensors, including the ones sold by Adafruit, use I2C to communicate.
Typically, using I2C with a microcontroller involves programming. Adafruit IO and WipperSnapper let you configure a microcontroller to read data from an I2C sensor and publish that data to the internet without writing code.
The WipperSnapper firmware supports a number of I2C sensors, viewable in list format here.
- If you do not see the I2C sensor you're attempting to use with WipperSnapper, Adafruit has a guide on adding a component to Adafruit IO WipperSnapper here.
On this page, you'll learn how to wire up an I2C sensor to your board. Then, you'll create a new component on Adafruit IO for your I2C sensor and send the sensor values to Adafruit IO. Finally, you'll learn how to locate, interpret, and download the data produced by your sensors.


Add an MCP9808 Component
On the device page, click the New Component (or "+") button to open the component picker.


Search for the component name by entering MCP9808 into the text box on the component picker, the list of components should update as soon as you stop typing.
Since WipperSnapper supports such a large number of components, there is keyword filtering. Try searching for various keywords, like:
- component names:
aht20,servo,buzzer,button,potentiometer, etc - sensor types:
light,temperature,pressure,humidity, etc - interface:
i2c,uart,ds18x20,pin, etc (also I2C addresses e.g.0x44) - vendor:
Adafruit,ASAIR,Infineon,Bosch,Honeywell,Sensirion, etc
There are added product and documentation links for every component, follow the links beneath the component descriptions to be taken to the appropriate product page or Learn Guide.

Select the MCP9808 from the list of results to go to the component configuration page.
There will be a back button if you select the wrong component, and you can use the Edit component icon (⚙️) on the device page to update the component configuration in the future.
On the component configuration page, the MCP9808's I2C sensor address should be listed along with the sensor's settings.

The MCP9808 sensor can measure ambient temperature. This page has individual options for reading the ambient temperature, in either Celsius or Fahrenheit. You may select the readings which are appropriate to your application and region.
The Send Every option is specific to each sensor measurement. This option will tell the board how often it should read from the sensor and send the data to Adafruit IO. Measurements can range from every 30 seconds to every 24 hours.
For this example, set the Send Every interval for both seconds to Every 30 seconds. Click Create Component.

The board page should now show the MCP9808 component you created. After the interval you configured elapses, the WipperSnapper firmware running on your board automatically reads values from the sensor and sends them to Adafruit IO.

Read I2C Sensor Values
Now to look behind the scenes at a powerful element of using Adafruit IO and WipperSnapper. When a new component is created on Adafruit IO, an Adafruit IO Feed is also created. This Feed holds your sensor component values for long-term storage (30 days of storage for Adafruit IO Free and 60 days for Adafruit IO Plus plans).
Aside from holding the values read by a sensor, the component's feed also holds metadata about the data pushed to Adafruit IO. This includes settings for whether the data is public or private, what license the stored sensor data falls under, and a general description of the data.
Next, to look at the sensor temperature feed. To navigate to a component's feed, click on the chart icon in the upper-right-hand corner of the component.

On the component's feed page, you'll each data point read by your sensor and when they were reported to Adafruit IO.

Doing more with your sensor's Adafruit IO Feed
This only scratches the surface of what Adafruit IO Feeds can accomplish for your IoT projects. For a complete overview of Adafruit IO Feeds, including tasks like downloading feed data, sharing a feed, removing erroneous data points from a feed, and more, head over to the "Adafruit IO Basics: Feed" learning guide.
Page last edited August 04, 2025
Text editor powered by tinymce.
Display
Your board has a built in Display. Boards running the WipperSnapper firmware can be wirelessly controlled by Adafruit IO to write to Displays.
On this page, you'll learn how to change the font size, and update the message content of the display built into your board from Adafruit IO.
On the device page, click the New Component (or "+") button to open the component picker.

Adafruit IO supports a large amount of components, try searching for Display to see all the supported displays.
Since WipperSnapper supports such a large number of components, you can use keyword filtering. Try searching for various keywords, like:
- component names:
aht20,servo,buzzer,button,neopixel, etc - sensor types:
light,temperature,pressure,humidity, etc - interface:
i2c,uart,ds18x20,pin,display, etc (also I2C addresses e.g.0x44) - vendor:
Adafruit,ASAIR,Infineon,Bosch,Honeywell,Sensirion, etc - display type / driver / family:
st7789,ili0373,sh1107,seg,lcd
There are also product and documentation links for every component. Follow the links beneath the component descriptions to be taken to the appropriate product page, Learn Guide, or datasheet.
To quickly find your display, type MagTag into the search bar, then select the 2.9" MagTag Display component, which will automatically detect the correct screen variant (SSD1680 / ILI0343).

There will be a back button if you select the wrong component, and you can use the Edit component icon (⚙️) on the device page to update the component configuration in the future.
On the component configuration page, you setup the display's SPI bus number and pins, or I2C address, along with the components settings.
The Display pins / address will be automatically selected in the drop-down menus where possible, and it's fine to leave some optional pins not selected.
Finally, choose any preferences like font size and rotation, then click Create.

After adding the component, your device page should show the newly created display component row, and the display attached to your board should refresh / turn on when the component is added.
If appropriate, your display may also show a status bar with connection info (username, connection status, WiFi strength, and battery level).
Usage
To send a message to the display, click on the Pen button at the end of the display component row, then fill in the dialog and click Send:

\ ) followed by the letter n for new line: \n
e.g. Line1 \n Line2\nLine3
The displays do accept true line breaks too (hitting the Enter/Return key in the text input box above, or sending \n or \r\n via JSON).
Feeds drive the display and store the data
The display component is connected to a feed, which means that you can send data to the feed and have it immediately appear on screen.
This can be really useful when combined with automated Actions.
It also means there is a history of messages. To view the feed data that has been previously sent to the display, click on the graph icon at the end of the component row.

Here you can see the feed history and edit things about the feed such as the name, privacy, webhooks associated with the feed and more. If you want to learn more about how feeds work, check out this page.

Lastly, take note of the Settings Gear (⚙️) at the end of the component row, where you can alter the components configuration.
This will show you the same dialog as when you added the display, along with any advanced options. It's also where you can remove and rename components.
Continue on with this guide to learn about the other component types, or maybe look at setting up an automated Action to write to the display.
Page last edited August 04, 2025
Text editor powered by tinymce.
Factory Reset
The MagTag board ships running a demo program. It's lovely, but you probably had other plans for the board. As you start working with your board, you may want to return to the original code to begin again, or you may find your board gets into a bad state. Either way, this page has you covered.
You're probably used to seeing the MAGTAGBOOT drive when loading CircuitPython or Arduino. The MAGTAGBOOT drive is part of the UF2 bootloader, and allows you to drag and drop files, such as CircuitPython. However, on the ESP32-S2 the UF2 bootloader can become damaged.
If you have a UF2 bootloader still installed - which means you can double-click to get the MAGTAGBOOT drive to appear, then you can simply drag the Factory Reset UF2 file over to the BOOT drive.
To enter UF2 bootloader mode, plug in the board into a USB cable with data/sync capability. Press the reset button once, wait till the RGB LED turns purple, then quickly press the reset button again. (You are doing a "slow double-click"). Then drag this file over:
For the 2025 version of the MagTag, use this Factory Reset UF2 file:
If you have a pre-2025 version of the MagTag, use this Factory Reset UF2 file:
Your board is now back to its factory-shipped state, running again with the original factory program. You can now begin again with your plans for your board.
What if you tried double-tapping the reset button, and you still can't get into the UF2 bootloader? Whether your board shipped without the UF2 bootloader, or something damaged it, this section has you covered.
It turns out, however, the ESP32-S2/S3 comes with a second, built-in, bootloader, the ROM bootloader, which cannot be erased or damaged. You can always reload the UF2 bootloader using the ROM bootloader.
There are three ways to do a factory reset and bootloader repair. The first and easiest is to use the OPEN INSTALLER button on the page for your board on circuitpython.org. This method requires no manual downloads and guides you through the steps interactively. We highly recommend this method as your first choice.
The second method is to use the browser-based Adafruit WebSerial ESPTool, and the third is to use esptool.py via the command line.
For both OPEN INSTALLER and the Adafruit WebSerial tool, you must use Firefox 151 or later, or Chrome 89 or later.

The OPEN INSTALLER button on circuitpython.org is the easiest way to install or update the UF2 bootloader. See the Learn Guide Using the OPEN INSTALLER Button on circuitpython.org for all the details.
Adafruit WebSerial ESPTool and esptool.py Methods for UF2 Bootloader Installation
The other methods for bootloader installation require you to download the bootloader yourself. The next section walks you through the prerequisite steps needed for both of these methods.
Clik on the green button below to download the .bin file you need (there may be more than one listed), and save wherever is convenient for you. You will need to be able to access the file from the Adafruit WebSerial ESPTool or another upload method.
This TinyUF2 bootloader provides a single 2.8MB firmware partition, which is needed for CircuitPython 10.0.0-alpha.5 and later versions. For CircuitPython 9.1.x and 9.2.x, either 4MB version below will work. See Update TinyUF2 Bootloader for CircuitPython 10 (4MB boards only) for more details.
This TinyUF2 bootloader provides two 1.4MB firmware partitions, required for CircuitPython 9.0.x and earlier, to support dualbank functionality:
Step 2. Enter ROM bootloader mode
Entering the ROM bootloader is easy. Complete the following steps.
Before you start, make sure your ESP32-S2/S3 is plugged into USB port to your computer using a data/sync cable. Charge-only cables will not work!
Turn on the On/Off switch - check that you see the power light on so you know the board is powered, a prerequisite!
To enter the bootloader:
- Press and hold the BOOT/DFU button down. Don't let go of it yet!
- Press and release the Reset button. You should still have the BOOT/DFU button pressed while you do this.
- Now you can release the BOOT/DFU button.
No USB drive will appear when you've entered the ROM bootloader. This is normal!
Now that you've downloaded the .bin file and entered the ROM bootloader, you're ready to continue installing the UF2 bootloader. The next two sections walk you through using the Adafruit WebSerial ESPTool (Alternative A) or esptool.py (Alternative B).
(There is also an Alternative C below, using the Arduino IDE, but it is less desirable, because it does not allow you to choose the bootloader that will be used.)
This method uses the Adafruit WebSerial ESPTool through a browser. Adafruit WebSerial ESPTool is a web-based option for programming ESP32-S2/S3 boards. It allows you to erase the the microcontroller flash and program up to four files at different offsets.
You have to use a browser that supports WebSerial for this to work. FIrefox versions 151 or later and and Chrome versions 89 or later work. Safari and is not supported because they don't have support for Web Serial functionality.
Follow the steps below to flash the UF2 bootloader.
Connect
You should have plugged in only the ESP32-S2/S3 that you intend to flash. That way there's no confusion in picking the proper port when it's time!

In the Chrome browser visit https://adafruit.github.io/Adafruit_WebSerial_ESPTool/. You should see something like the image shown.
Leave the No reset for Passthrough updates toggle off.

Press the Connect button in the top right of the web browser. You will get a pop up asking you to select the COM or Serial port.
Remember, you should remove all other USB devices so only the ESP32-S2/S3 board is attached, that way there's no confusion over multiple ports!
On some systems, such as MacOS, there may be additional system ports that appear in the list.

The JavaScript code will now try to connect to the ROM bootloader. It may timeout for a bit until it succeeds. On success, you will see that it is Connected and will print out a unique MAC address identifying the board along with other information that was detected.


To erase the contents, click the Erase button. You will be prompted whether you want to continue. Click OK to continue or if you changed your mind, just click cancel.

You'll see "Erasing flash memory. Please wait..." This will eventually be followed by "Finished." and the amount of time it took to erase.
Do not disconnect! Immediately continue on to programming the ESP32-S2/S3.
Programming the ESP32-S2/S3 can be done with up to four files at different locations, but with the board-specific bootloader .bin file, which you should have downloaded under Step 1 on this page, you only need to use one file.

Click on the first Choose a file.... (The tool will only attempt to program buttons with a file and a unique location.) Then, select the bootloader .bin file you downloaded in Step 1 that matches your board.
Verify that the Offset box next to the file location you used is (0x) 0.

Once you choose a file, the button text will change to match your filename. You can then select the Program button to begin flashing.

Once completed, you can skip down to the section titled Reset the Board.
Once you have entered ROM bootloader mode, you can then use Espressif's esptool program to communicate with the chip! esptool is the 'official' programming tool and is the most common/complete way to program an ESP chip.
Install esptool.py
You will need to use the command line or Terminal to install and run esptool.
You will also need to have pip and Python installed (any version!).
Install the latest version using pip (you may be able to run pip without the 3 depending on your setup):
pip3 install --upgrade esptool
Then, you can run:
esptool.py
Test the Installation
Run esptool.py in a new terminal/command line and verify you get something like the below:

Find the Serial Port
First, you need to determine the name of the serial port you board has when it's plugged in and ROM bootloader mode.
- For Windows, it will be a COM port, such as
COM5. Look in Device Manager -> Ports. - For macOS, you can do
ls /dev/tty.*in a Terminal to find the names of the serial ports. - For Linux, you can do ls
/dev/tty*in a terminal window. The name is often /dev/ttyACM0 or similar.
If you are not sure you've found the right port, unplug the board, and see if the port disappears.
For more information on determining serial ports, follow these links for help on Windows, macOS, or Linux.
Connect
Run the following command, replacing the identifier after --port with the COMxx, /dev/cu.usbmodemxx or /dev/ttySxx you found above.
For example, if you're using Windows, and you think the board is on COM88, type this following:
esptool.py --port COM88 chip_id
You should get a notice that it connected over that port and found an ESP32-S2/S3.

Erase the Flash
Before programming the board, it is a good idea to erase the flash. Run the following command.
esptool.py --port COM88 erase_flash
You must be connected (by running the command in the previous section) for this command to work as shown.

Flash the UF2 Bootloader
Run this command and replace the serial port name with your matching port and the file you just downloaded
esptool.py --port COM88 write_flash 0x0 tinyuf2-some-board-0.32.0-combined.bin
Don't forget to change the --port name to match.
tinyuf2-some-board-0.32.0-combined.bin.
There might be a bit of a 'wait' when programming, where it doesn't seem like it's working. Give it a minute, it has to erase the old flash code which can cause it to seem like it's not running.
You'll finally get an output like this:

Once completed, you can continue to the next section.
The board should restart automatically, and start up the UF2 bootloader. If not, press the reset button to start the bootloader.
When the UF2 bootloader starts, the five RGB LEDs at the top of the board will turn red briefly, then green, meaning that the bootloader is running and showing MAGTAGBOOT.
You've successfully returned installed the UF2 bootloader on your board. If you now want to return the board to a factory reset state, follow the instructions at the top of the page to Install the Factory Reset Firmware UF2.
We suggest updating to Chrome 89 or newer, as Web Serial is enabled by default.
If you must continue using an older version of Chrome, follow these steps to enable Web Serial.

If you receive an error like the one shown when you visit the Adafruit WebSerial ESPTool site, you're likely running an older version of Chrome.
You must be using Chrome 78 or later to use Web Serial.

To enable Web Serial in Chrome versions 78 through 88:
- Visit chrome://flags from within Chrome.
- Find and enable the Experimental Web Platform features
- Restart Chrome
Step 3: Alternative C. The Flash an Arduino Sketch Method
This section outlines flashing an Arduino sketch onto your ESP32-S2/S3 board, which automatically installs the UF2 bootloader as well. However, it does not allow you to choose which UF2 bootloader to install, so Alternative A or B above are preferred.
Arduino IDE Setup
If you don't already have the Arduino IDE installed, the first thing you will need to do is to download the latest release of the Arduino IDE. ESP32-S2/S3 requires version 1.8 or higher. Click the link to download the latest.
After you have downloaded and installed the latest version of Arduino IDE, you will need to start the IDE and navigate to the Preferences menu. You can access it from the File > Preferences menu in Windows or Linux, or the Arduino > Preferences menu on OS X.
The Preferences window will open.
In the Additional Boards Manager URLs field, you'll want to add a new URL. The list of URLs is comma separated, and you will only have to add each URL once. The URLs point to index files that the Board Manager uses to build the list of available & installed boards.
Copy the following URL.
https://raw.githubusercontent.com/espressif/arduino-esp32/gh-pages/package_esp32_dev_index.json
Add the URL to the the Additional Boards Manager URLs field (highlighted in red below).

Click OK to save and close Preferences.
In the Tools > Boards menu you should see the ESP32 Arduino menu. In the expanded menu, it should contain the ESP32 boards along with all the latest ESP32-S2 boards.
Now that your IDE is setup, you can continue on to loading the sketch.
In the Tools > Boards menu you should see the ESP32 Arduino menu. In the expanded menu, look for the menu option for the "Adafruit MagTag 2.9", and click on it to choose it.
Open the Blink sketch by clicking through File > Examples > 01.Basics > Blink.

For the Arduino IDE to upload TinyUF2 you must select a TinyUF2 partition layout, under the Tools > Partition Scheme menu.
If you have a 4MB board, won't be doing Over-The-Air firmware updates (OTA), or are unsure, then choose the 'No OTA' TinyUF2 entry.

Finally, click Upload from the sketch window.

Once successfully uploaded, the little red LED will begin blinking once every second. At that point, you can now enter the bootloader.
Page last edited August 04, 2025
Text editor powered by tinymce.
Downloads
Files
All In One Shipping Demo
This file can be burned to your MagTag using the ROM bootloader (address 0x0) to install the TinyUF2 bootloader plus shipping demo
Download the file to your computer, enter ROM bootloader mode, then run after changing the COM/Serial port:
esptool.py -p COM88 write_flash 0x0 magtag_demoboot.bin
note that esptool will seem to 'hang' for a bit...that's normal, a lot of the file is empty and it doesn't tell you its skipping ahead.
If you have a pre-2025 MagTag, use this .BIN file:


Acrylic Front and Back Plates
Suitable for laser cutting. There are two front designs (cloud and arrow) and a back piece (for using MagTag as a wearable badge rather than the magnetic feet). These can be secured with 8mm M3 screws.
Adobe Illustrator or SVG file formats:
Page last edited August 04, 2025
Text editor powered by tinymce.


